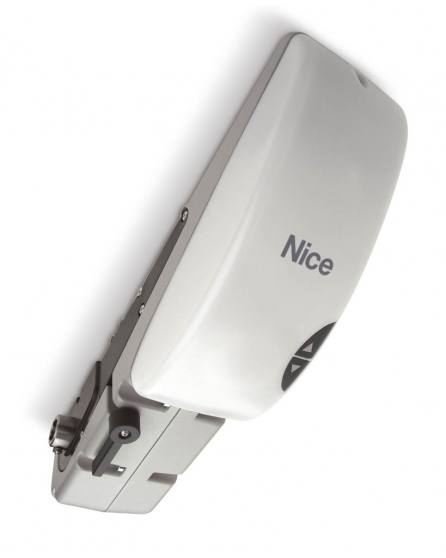
NICE Ten TN2020L – operator for up-and-over garage doors
| Product availability: | to the question | The product may not be available, contact us for more information. |
|---|
to the question
€426.02 including VAT
| Weight |
|---|
| 7,20 kg |
Description of NICE Ten TN2020L – operator for up-and-over garage doors
NICE TEN TN2020L – operator for an up-and-over garage door
The NICE TN2020L operator is designed for up-and-over garage doors. Before ordering, check the door’s dimensions, weight and construction.
The TN2020L does not have its own control unit. It is a second 24 V DC motor with auxiliary LED lighting for a dual-motor setup, controlled by NICE TN2010L. The TN2020L alone must not be connected directly to a 230 V mains supply. The operator is non-reversible; in the event of a power failure, it allows manual release using the handle.
When to choose this operator
The TEN is designed for properly balanced up-and-over garage doors with counterweights or springs, with or without an overhang. The motor is mounted on the door structure and transfers motion via shafts and telescopic arms. It is not a ceiling-mounted operator with a guide rail for a sectional door.
The TN2020L is an additional motor, not a standalone replacement for the TN2010L. The accessories, receiver, safety inputs and dual-motor setup settings are all handled by the main TN2010L unit. If you already have a different main unit, check the exact combination and its own manual.
| Setup in accordance with the supplied installation manual | Approximate door dimensions |
|---|---|
| 1 × TN2010L + 1 × TN2020L | Maximum height 2.6 m, maximum width 5.4 m; area up to 14 m². |
Dimensions alone are not enough: what matters is the balance, resistance throughout the door’s travel and the number of cycles. For the configuration described in the supplied manual, the installation limits stated above apply. A larger door must be assessed individually for the specific motor and control unit. A second motor does not replace the repair of damaged springs, cables or guides.
Number of cycles and force required to move the door
| Setup | Force required to move | Max. cycles/h | Max. consecutive cycles |
|---|---|---|---|
| TN2010L + TN2020L | Up to 150 N | 30 | 19 |
| TN2010L + TN2020L | Over 150–250 N | 28 | 16 |
| TN2010L + TN2020L | Over 250–350 N | 25 | 14 |
A cycle means one complete opening and closing; a manoeuvre is movement in one direction. These are upper operating limits, not a recommendation to increase door resistance. When preparing the door for private use, the force required to move it manually must not exceed 150 N; the manual movement test during commissioning has a separate limit of 225 N. The control unit limits operation based on load and duration to prevent overheating.
Motor and control unit setup
| Setup component | Function in the automated door system |
|---|---|
| NICE TN2010L | Main motor with built-in control unit, absolute encoder and BlueBUS. Controls the safety devices, receiver and connected second motor. The plug-in receiver is selected separately. |
| NICE TN2020L | Second 24 V DC motor without a control unit. In a dual-motor installation, it is connected to the main TN2010L; on its own, it cannot control the door. |
Standalone motor and required installation equipment
This product page is for the TN2020L. A complete automation system also requires a support bracket, suitable shafts, telescopic arms, controls and safety devices. The choice depends on the door construction and the number of motors. Before ordering, check the supplied equipment and required accessories.
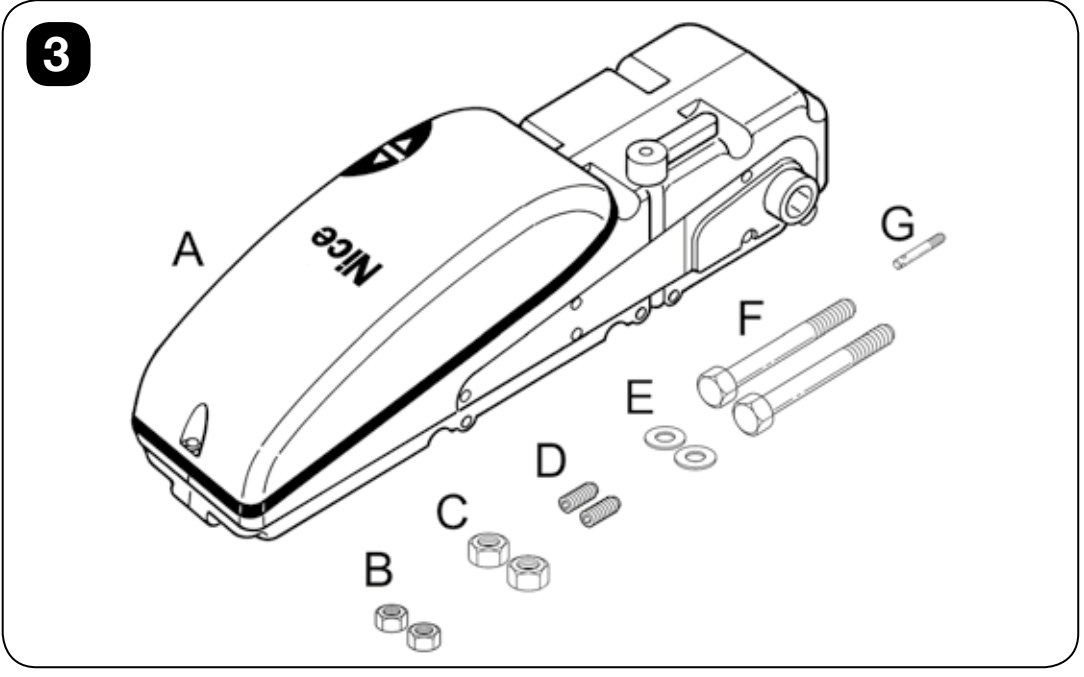
Installation part labels:
- A – TEN motor
- B – M6 nuts
- C – M8 nuts
- D – M6 × 14 threaded studs
- E – Ø8 washers
- F – M8 × 110 bolts
- G – release rod.
| What | Why | Type |
|---|---|---|
| Support bracket | Motor support bracket, length 1,250 / 2,000 mm. | |
| Shafts | Square-section shafts, 20 × 20 mm, length 1,500 / 200 mm. | |
| Telescopic arms | Pair of straight / curved telescopic arms. Curved arms help when space is limited near the door’s support arm. | |
| Shaft guides | Guide for a pair of drive shafts. | |
| External release | Release from outside using a cable or key lock. OTA12 is not used with side-mounted motors. |
Gate installation and inspection
Installation, wiring and commissioning must be carried out by a qualified technician. The motor must be installed inside the garage. The IP44 rating does not permit outdoor installation. Disconnect the mains supply and any backup battery before carrying out work.
- Check the condition and balance of the gate, springs, cables, guides and supporting parts. The gate must move smoothly by hand along its entire travel and must not drop on its own.
- Remove any unnecessary cables and disable the original locking mechanism if it would obstruct motorized operation.
- Select a sturdy bracket and shafts to suit the width of the gate. Before final tightening, check the full travel of the shafts and telescopic arms; they must not interfere with the guide, frame or counterweight.
- Assess potential trapping points at the arms, top edge and bottom edge. If the gate has a pass door, its opening must be safely monitored.
- The manual release must be accessible up to a height of 1.8 m. Install the fixed control within sight of the gate, away from moving parts and at least 1.5 m above the floor.
- If there is no other entrance to the garage, install an external release before handing over the system. The moving gate must not extend onto a public footpath or road.
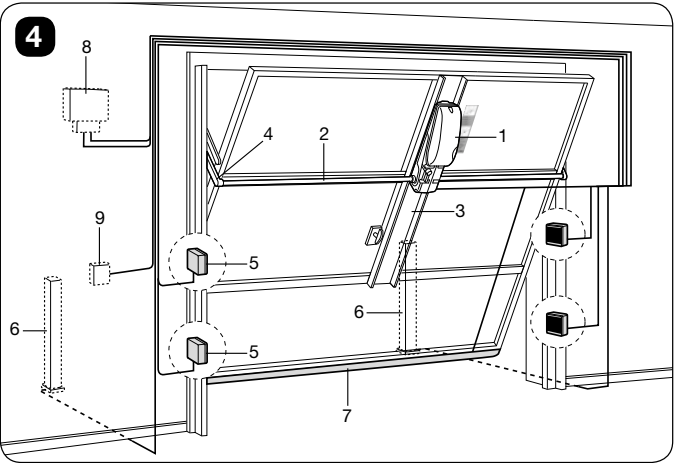
Diagram:
- 1 – TEN
- 2 – 20 × 20 mm square shaft
- 3 – support bracket
- 4 – telescopic arm
- 5 – photocells
- 6 – photocells on pedestals
- 7 – safety edge
- 8 – low-voltage flashing light with antenna
- 9 – control.
This is a layout illustration; safety devices must be designed for the actual gate.
Motor dimensions and cable routing
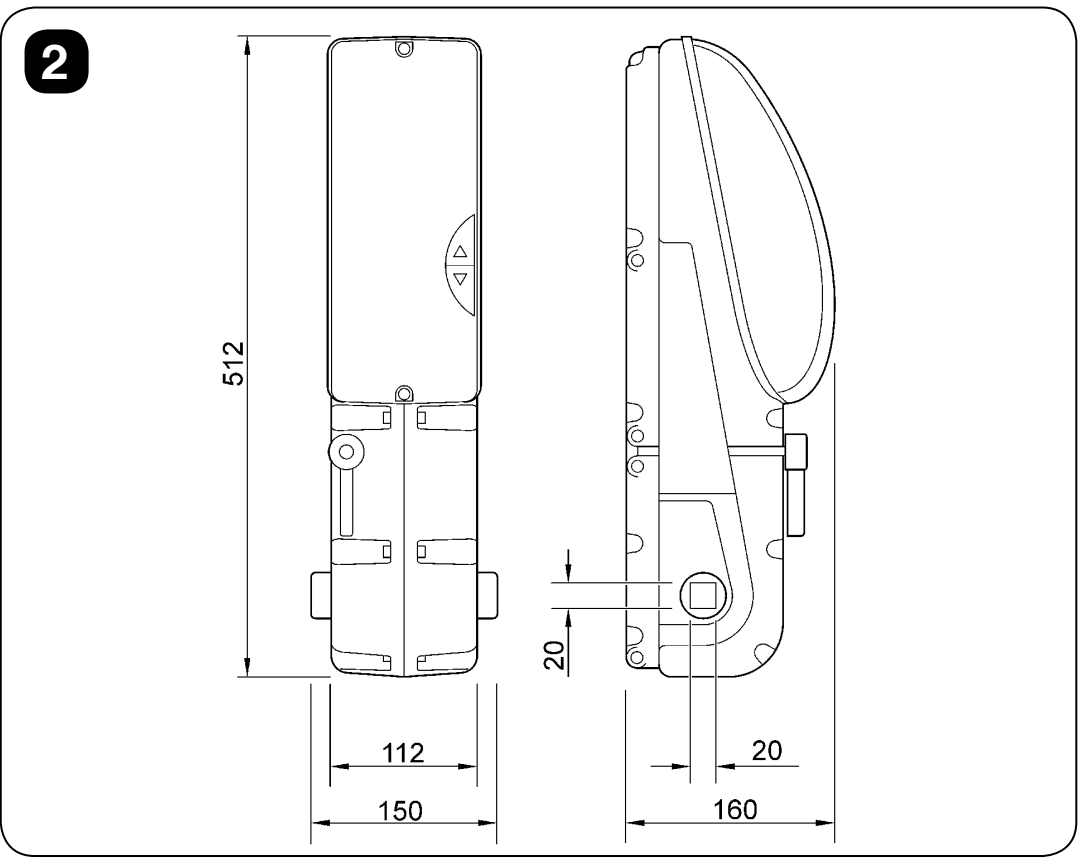
The drawing shows a height of 512 mm, a width of 150 mm, a maximum depth of 160 mm and an output shaft size of 20 × 20 mm. Allow space for the cover, release mechanism and gate movement before mounting. The technical table lists the body depth as 158 mm; allow for the 160 mm outline shown in the drawing when allocating space.
With the cover open, make only the necessary cable entries and fit suitable cable glands. Route the mains supply separately from low-voltage cables, secure them against tension and leave enough slack for gate movement. Do not allow water or condensation to remain in conduits or at cable entry points. After adjustment, install the cover and check its clearance throughout the full travel.
Manual release and re-engagement
Release the gate only when it is stationary, and secure it against falling first. An unbalanced gate or damaged spring may cause sudden movement when released. For a two-motor system, release both motors.
- Stop the gate and disconnect all power sources.
- Turn the motor handle counterclockwise as shown in the illustration. Then move the gate by hand without forcing it.
- To re-engage the drive, turn the handle clockwise to the vertical position.
- Move the gate a short distance by hand until the drive engages. Only then restore power and check the controls.
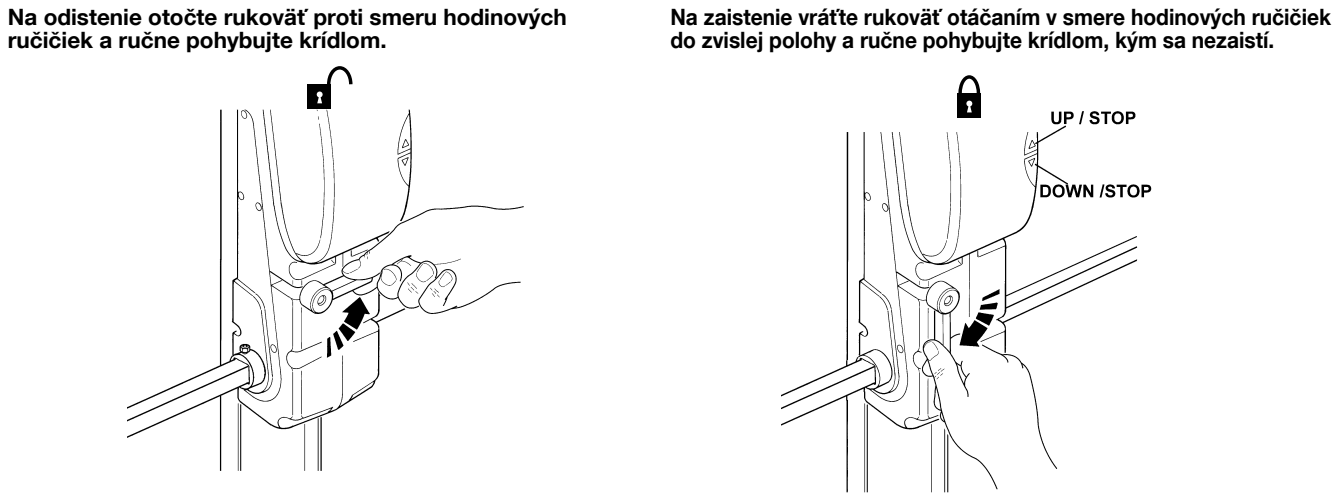
For external release, use a correctly installed NICE OTA11 or NICE OTA12. For a two-motor system, the solution must allow both drives to be released safely.
Wiring
| TN2010L main circuit | Cable type and length as specified in the manual |
|---|---|
| Mains power supply | 3 × 1.5 mm², maximum 30 m. For lengths over 30 m, use a larger cross-section, such as 3 × 2.5 mm², as determined by the power supply and protection design. |
| 12 V flashing light | 2 × 1 mm², maximum 20 m. |
| Antenna | RG58 coaxial cable, maximum 20 m; a length under 5 m is recommended. |
| BlueBUS photocells | 2 × 0.5 mm², maximum 20 m. |
| Key switch | Maximum 20 m; number of cores depends on the contacts used. The manual allows a shared 4 × 0,5 mm² cable. |
| Contact safety edge | 2 × 0.25 mm², maximum 20 m; an optical edge requires wiring according to its three signals. |
Cables must be suitable for the environment and moving installation. An electrician must design the route, protection and supply; simply using the stated cross-section is not sufficient. Between the motors there are two separate circuits – motor and auxiliary light; select the wiring according to the supplied system and the illustration below.
Control unit and wiring
The TN2010L has built-in controls; the TN2020L does not. The terminals and procedures below apply to the TN2010L control unit shown in the illustration, with three buttons and eight LEDs, L1–L8. When replacing the NICE TNA2 board or when using a different version, follow the manual for the version actually installed.
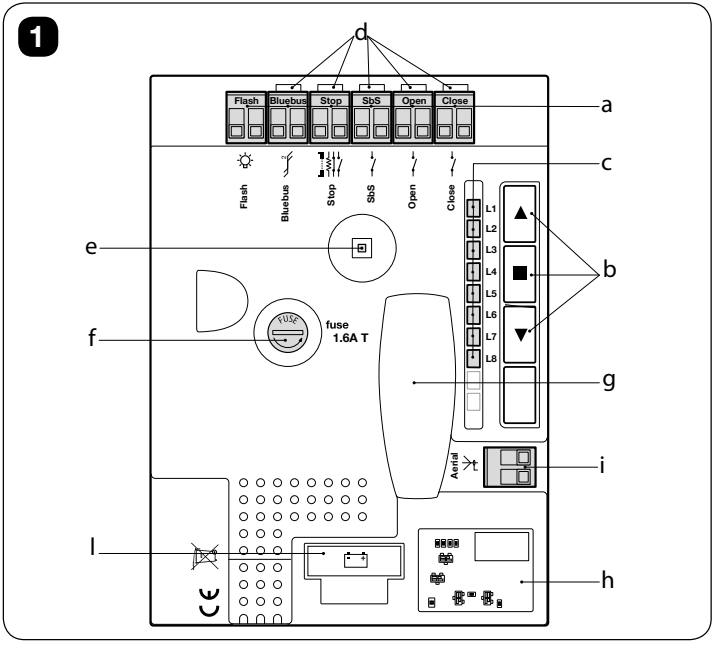
On the board:
- a – terminals
- b – buttons
- c – LEDs L1–L8
- d – input LEDs
- e – auxiliary light
- f – F2 fuse
- g – SM receiver socket
- h – BusT4
- i – Aerial terminal
- l – battery connector.
Mains and low-voltage accessories
| Circuit / terminals | Wiring and limits |
|---|---|
| TN2010L: 1 / 2 / 3 | Mains 230 V AC, 50/60 Hz: 1 = L (live), 2 = N (neutral), 3 = PE (protective earth). AC has no plus or minus. The power supply must have suitable isolation and protection. |
| Auxiliary power supply | Right STOP contact = GND (−), left SbS contact = 24 V DC (+), in the same orientation as shown in the image. Voltage 24 V DC −30/+50 %, maximum 100 mA total. Remains present in Stand-by. |
| BlueBUS | Parallel two-wire connection for compatible devices, e.g. NICE EPMB. No polarity; this is not a universal 24 V auxiliary output. Maximum 12 BlueBUS load units. |
| SbS / Open / Close | Command pairs for voltage-free NO contacts: step-by-step / open / close. Switch the relevant contact pair; do not connect an external power supply. An NO contact has no polarity. |
| Stop | Learned safety input for NO, NC, 8.2 kΩ or compatible optical safety edges; see detailed STOP wiring. |
| Flash | Factory-configured output for a 12 V DC flashing light, max. 21 W, e.g. NICE ELDC. Do not power a 230 V ELAC here. Follow the markings on the fitted board for the exact output terminals; their positions cannot be inferred from the auxiliary power supply. |
| Aerial / receiver | Coaxial cable: centre conductor = signal, braid = shield. These are not power +/− terminals. With NICE OXIBD connect the external aerial directly to its aerial terminals. |
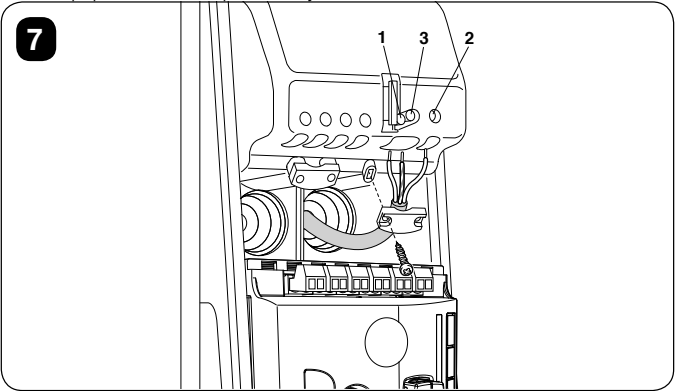
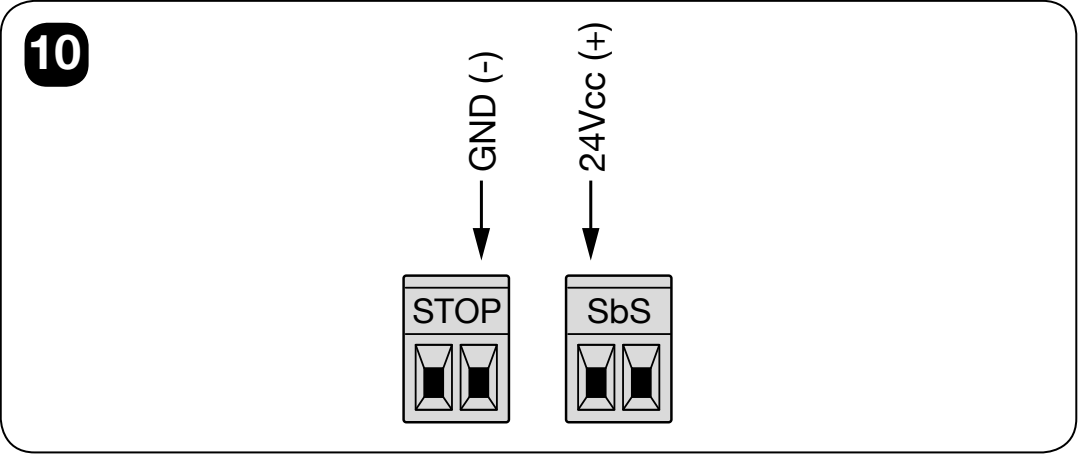
The plus and minus signs above refer to individual contacts, not entire two-pole terminal blocks. Connect powered accessories with their + to SbS (+) and − to STOP (−), only if they are compatible with the specified voltage and total current draw. The TN2020L motor and flashing light must not be powered from this 100 mA output.
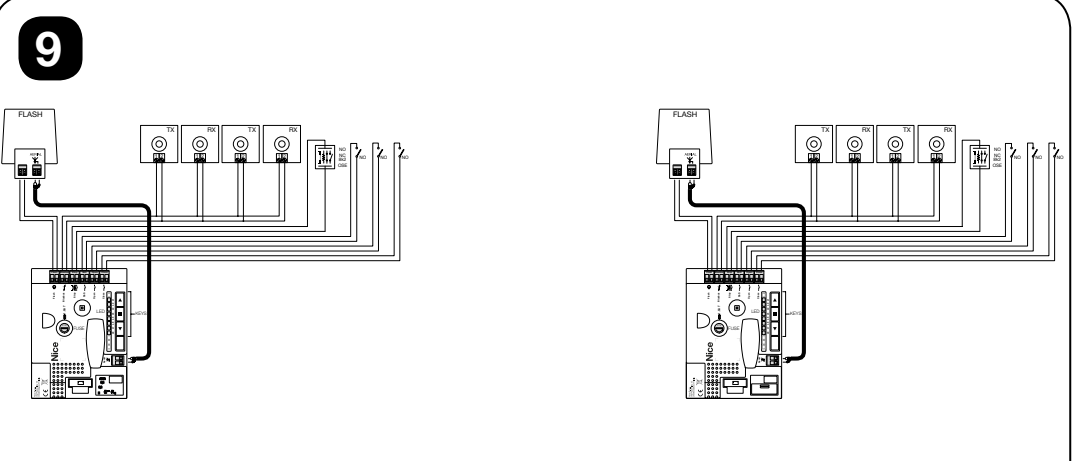
The diagram shows alternative wiring arrangements for safety devices; it does not mean that all STOP options should be connected at once. For the flashing light NICE ELDC connect the power supply to its designated low-voltage input and wire the aerial cable separately. Set the flashing mode as instructed in the light's manual for an output that already provides an intermittent voltage.
Connecting the TN2010L and TN2020L
The 230 V mains supply connects only to the main TN2010L. The TN2020L receives motor power from the main unit. It has its own motor and light terminals, not a second control unit or its own safety inputs.
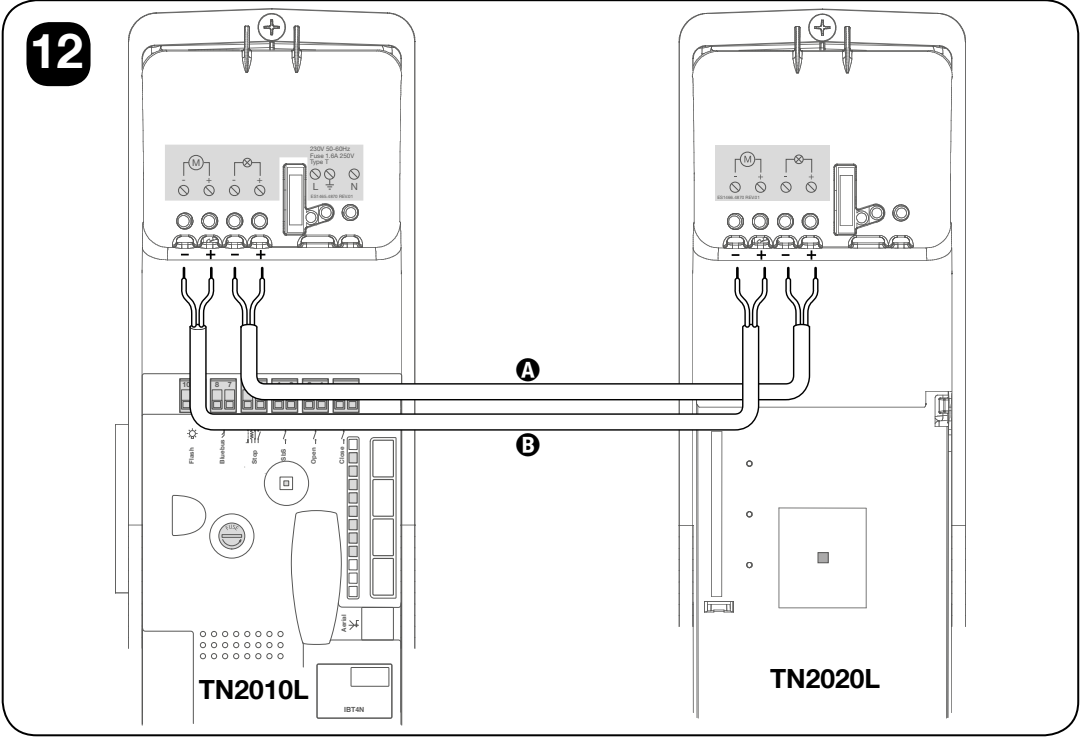
| Wiring as shown | Requirements |
|---|---|
| A – second motor | From the TN2010L second-motor output to the TN2020L motor terminals. For both pairs shown left −, right +; maintain − → − and + → +. |
| B – auxiliary light for the second motor | Run a separate cable from the second-motor light output to the TN2020L light terminals. Again, in the image left −, right +; do not connect it to the motor terminals or the 100 mA auxiliary output. |
| Settings on the main TN2010L | Level I, L8 ON = two motors; with one TN2010L, it must remain L8 OFF. |
Read the pole positions with the original diagram in the same orientation, and always check against the actual terminal markings. Do not enable two-motor mode when only one motor is installed – this may cause incorrect operation and damage. After changing the configuration, repeat the learning procedure, force measurement and safety tests.
BlueBUS photocells and addressing
NICE EPMB connect with two wires to the BlueBUS on the main TN2010L. Both TX and RX in one pair must have the same jumpers; the next pair must use a different address. BlueBUS devices are polarity-independent and connected in parallel. Standard relay-type EPM units must not be connected to BlueBUS.
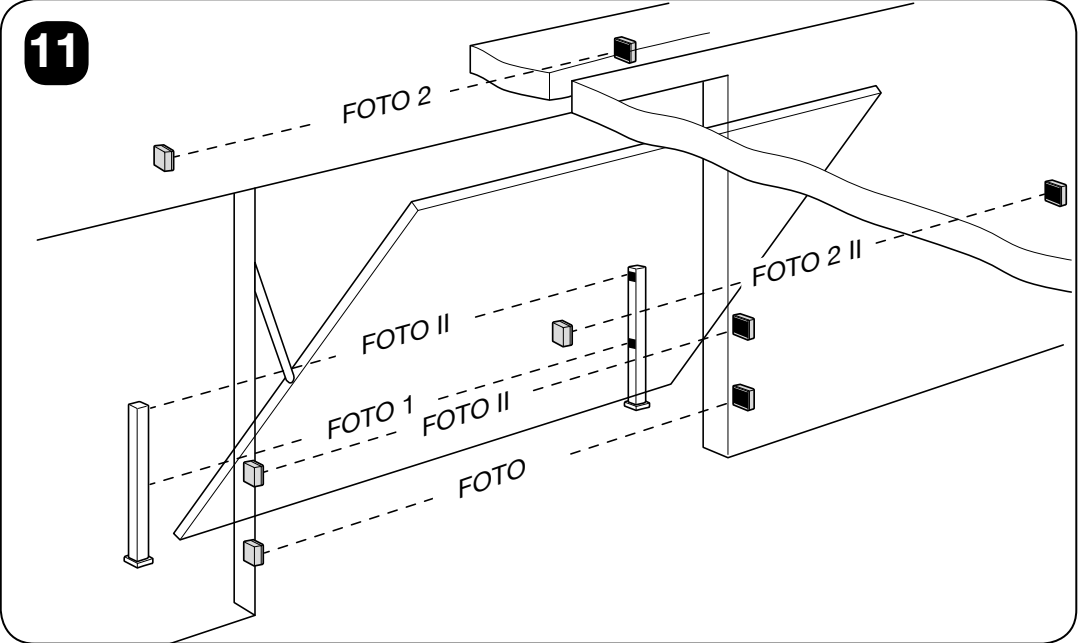
| Address | Function with TEN |
|---|---|
| PHOTO / PHOTO II | Monitors closing; height approximately 50 / 100 cm. |
| PHOTO 1 / PHOTO 1 II | Monitors opening and closing; height approximately 50 / 100 cm. |
| PHOTO 2 / PHOTO 2 II | Monitors opening. |
| PHOTO 3 | One photocell safety device covering the entire automation system, according to the proposed configuration. |
| FA1 / FA2 | Photocell for the open command; use only with a suitable photocell type and in accordance with its instructions. It is not a substitute for the required safety protection. |
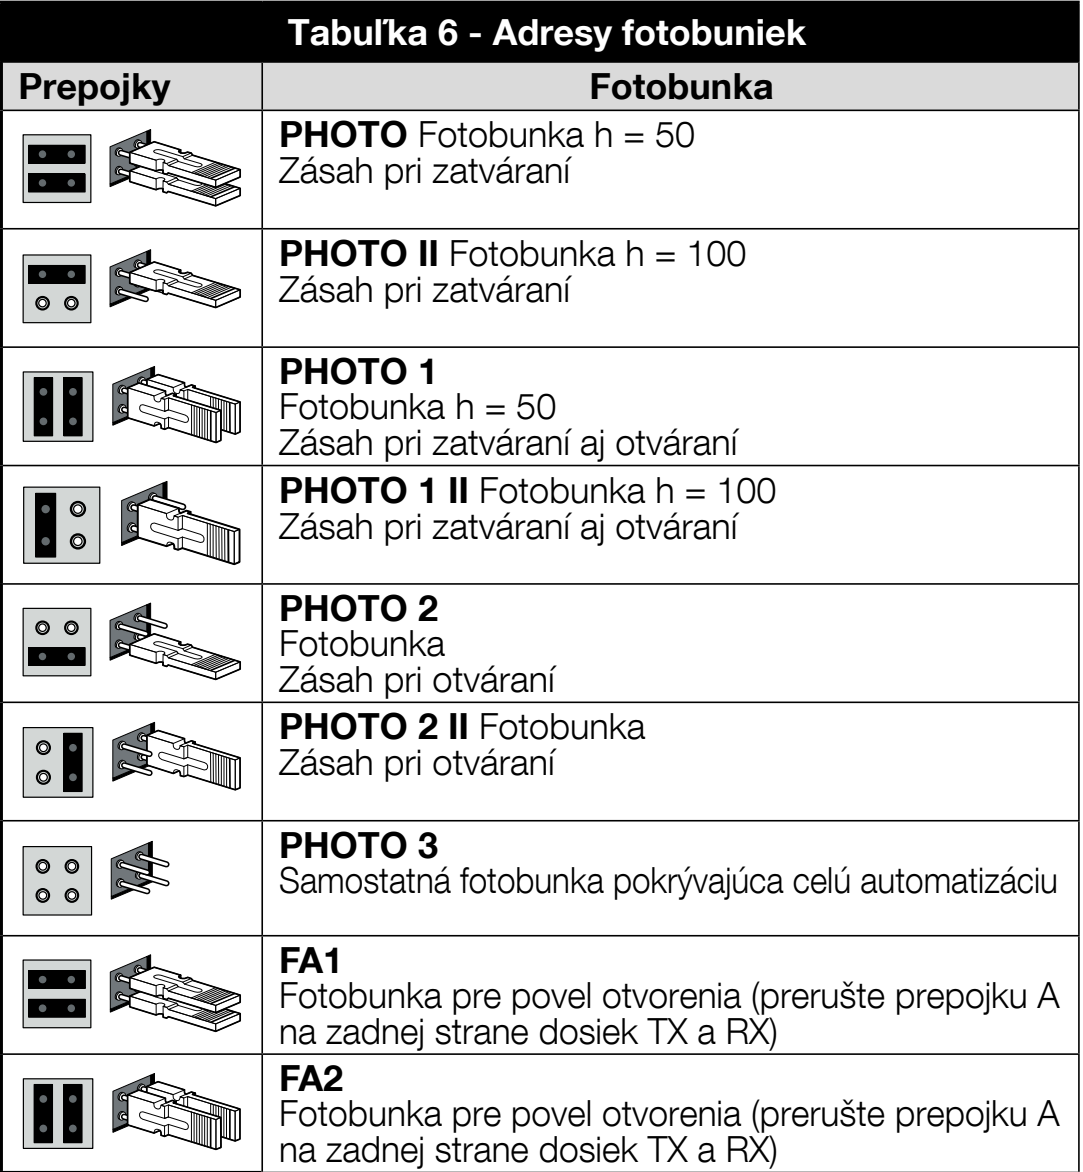
When replacing photocells, verify that the jumpers have the same function in their respective instructions. After adding or removing any device, run device recognition and test the response again in both directions. Do not test movement with the safety protection bypassed. EPMB jumper settings.
Sensitive safety edge and STOP input
STOP triggers a stop followed by a brief reverse movement. During learning, the control unit stores the type of connected device and triggers a safety response when its state changes. Multiple NO contacts can be connected in parallel, and NC contacts in series. Resistive safety edges must be connected according to their instructions; in a cascade, use a single end-of-line resistor 8.2 kΩ.
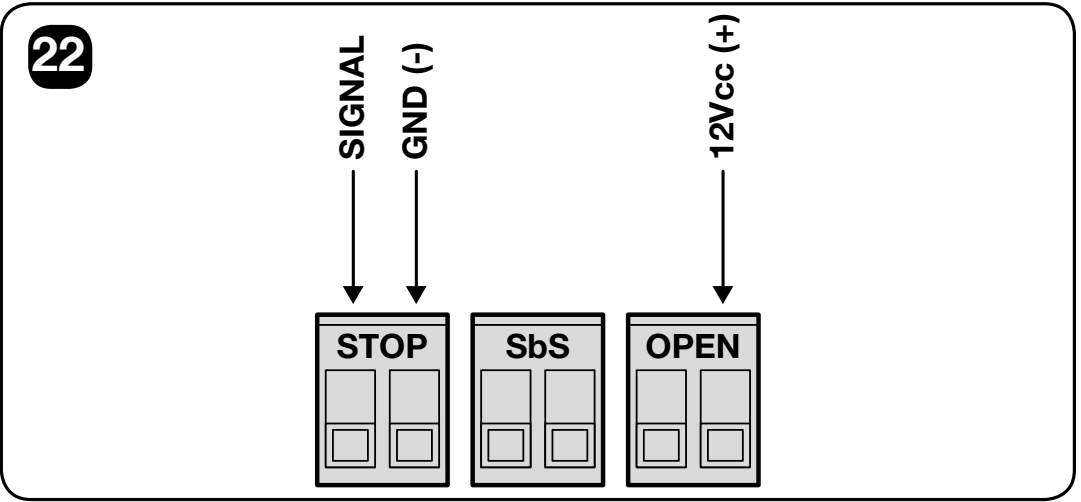
| OSE optical safety edge | Specific contact, viewed in the orientation shown in the image |
|---|---|
| Power supply + | Right-hand contact OPEN = +12 V DC, max. 40 mA. Connect the positive power-supply wire of a compatible optical safety edge here. |
| Power supply − | Right-hand contact STOP = GND (−). |
| Signal | Left-hand contact STOP = SIGNAL. This is not a positive power supply. |
When connecting an OSE device, the OPEN contact is used to power the safety edge—do not connect an arbitrary push-button command circuit to it. NO/NC contacts and resistive safety edges have no power-supply polarity; an optical safety edge does. For the required safety category, select a suitable optical or 8.2 kΩ device and test the entire gate.
Initial startup and device recognition
All buttons and LEDs described below are on the main TN2010L. This procedure is not carried out separately on the TN2020L. Before startup, complete the installation and safety devices, and set L8 according to the number of motors.
- After switching on, check the BlueBUS LED: after initially flashing rapidly, it should flash regularly about once per second. The LEDs on the connected TX/RX units should indicate operation; the warning light and auxiliary light should remain off at rest.
- If the indicators do not behave as expected or a fault is suspected, disconnect the power supply and check the wiring. Do not proceed with the learning procedure blindly.
- Press and hold ▲ + STOP/SET. Release them when L1 and L2 start flashing rapidly, after approximately 3 seconds.
- Wait for the process to finish. The STOP LED should remain lit and L1/L2 should go out; L3/L4 may flash to indicate that position learning is required.
Recognition is performed even when no devices are connected and must be repeated after any change to BlueBUS or STOP.
Position learning and automatic force measurement
First, check that the direction of movement is correct and that the area is clear. If the direction is reversed, use direction programming; do not swap the motor wires at random. While the gate is moving, any of the three buttons on the board will stop the motor.
Abbreviated procedure – open and closed positions
- Hold STOP/SET + ▼ for approximately 3 seconds, until L1 starts flashing, then release the buttons.
- Use ▲ / ▼ to set the required fully open position FCA.
- Hold STOP/SET for 5 seconds and wait until L8 starts flashing; then release the button.
- Use ▲ / ▼ to set the fully closed position FCC.
- Confirm by holding STOP/SET for 2 seconds then release. L1/L8 will go out. The control unit calculates the other positions.
- The auxiliary light will start flashing about once per second. Send an SbS or OPEN command: the system will perform two complete cycles to measure the force automatically.
Setting each position individually
Enter the procedure in the same way by holding STOP/SET + ▼ for approximately 3 seconds. Set the position using ▲ / ▼ and confirm each position to be saved by holding STOP/SET for 2 seconds. You can skip an optional position by pressing STOP/SET twice quickly.
| Sequence / LED | Position and function |
|---|---|
| 1 – L1 / FCA | Fully open position; mandatory. |
| 2 – L2 / RA | Start of deceleration when opening; optional. |
| 3 – L4 / RI | Intermediate deceleration when closing. The gate starts to slow down about 50 cm before this point and returns to the set speed after passing it; optional. |
| 4 – L5 / AP | Partial opening; optional. |
| 5 – L7 / RC | Start of deceleration when closing; optional. |
| 6 – L8 / FCC | Fully closed position; mandatory. |
After FCC, release STOP/SET and send a command to start the two complete force-measurement cycles. The process must finish on its own without interruption. If interrupted, it remains incomplete even after a power failure and must be started again. Changing the positions, opening/closing speed, or direction of rotation triggers a new force-measurement request.
The encoder operates within the permitted range of 5–95%. L1 or L8 flashing by itself while the gate is at rest may indicate that this range has been exceeded; this does not automatically mean there is a photocell fault. This must be corrected by a technician, without bypassing the safety protection.
Safety checks before use
- With the power disconnected and the motors released, check manual movement; the test limit is 225 N, while the stricter limit for preparing a private gate is 150 N.
- Test each photocell, sensitive edge, STOP input, and other safety device separately. Each device must respond according to its selected function.
- Test the photocells with an object 5 cm in diameter and 30 cm long, positioned at the TX, at the RX, and in the middle of the beam.
- When closing onto an object 50 mm high, placed on the floor, the drive must, after the bottom edge makes contact, reverse direction. During the safety test with a weight of 20 kg attached at the center of the bottom edge, the drive must prevent opening or stop the opening movement. Tests must be carried out by the installer with the test area secured; this is not a test of manual release with a weight attached.
- Measure impact forces and assess the operating hazards of the entire gate. Do not use increased force to mask friction or poor balance.
- Provide the instructions, maintenance plan, test documentation, and guidance on releasing the drive. The gate may be operated only after the tests have been passed.
Settings on the main TN2010L
▲ opens or moves up through the menu, ▼ closes or moves down, and STOP/SET stops and confirms. During movement, all three buttons stop the gate. These procedures apply to the control unit shown; allow no more than 10 s between programming operations.
Level I – eight ON/OFF functions
- With the gate stopped, press and hold STOP/SET for about 3 s, then release when L1 flashes.
- Use ▲ / ▼ to select the function LED.
- Press STOP/SET briefly to change the state: short flash = OFF, long flash = ON.
- Wait 10 s for the setting to be saved and the menu to exit.
These functions are disabled by default. For a two-motor setup, a technician must enable L8.
| LED | Function | Meaning |
|---|---|---|
| L1 | Automatic closing | Closes after opening, following the set pause. Without this function, operation is semi-automatic. |
| L2 | Closing after photocell activation | After the photocell is cleared, there is a 5 s pause. Without L1, the gate completes opening first; with L1, opening may stop once the photocell is cleared. This function does not apply after a STOP command. |
| L3 | Always close | When power is restored, the control unit detects an open gate and starts closing with a 3 s pre-warning flash. |
| L4 | Standby | After 1 minute of inactivity, the BlueBUS output and all LEDs switch off except the BlueBUS LED, which flashes more slowly. A new command restores operation; the auxiliary 24 V supply remains active. |
| L5 | Long reverse movement | After a STOP command or force limiter activation, the gate reverses all the way to the end position. OFF means a short reverse movement of approximately 15 cm. |
| L6 | Pre-flashing | The warning light starts flashing 3 s before movement. |
| L7 | Sensitivity | Increases obstacle detection sensitivity. Requires suitable speed and force settings, followed by measurement. |
| L8 | Two motors | ON: TN2010L + TN2020L. OFF: one TN2010L. |
Level II – eight adjustable parameters
- Press and hold STOP/SET for about 3 s, release when L1 lights up, then use ▲ / ▼ to select the parameter's input LED.
- Press and hold STOP/SET. After about 3 s, the current value lights up.
- While holding STOP/SET, change the value using ▲ / ▼.
- Release STOP/SET and wait 10 s for the menu to exit.
Bold values indicate the table's default settings for the control unit shown; always check the actual setting on the control board LED. The pause time applies only when automatic closing is enabled. For parameters with a value between two levels, two LEDs may light alternately.
| Parameter | Values L1–L8 |
|---|---|
| L1 – Pause time | L1 10 s L2 20 s L3 40 s L4 60 s L5 80 s L6 120 s L7 160 s L8 200 s |
| Parameter | Values L1–L8 |
|---|---|
| L2 – Step-by-step function | L1 open–stop–close–stop L2 open–stop–close–open L3 open–close–open–close L4 condominium mode L5 condominium mode 2; a command lasting more than 2 s stops the gate L6 step-by-step mode 2; a command lasting less than 2 s partially opens the gate L7 hold-to-run movement L8 semi-automatic opening, closing while the command is held |
| Parameter | Values L1–L8 |
|---|---|
| L3 – Speed | L1 30% L2 44% L3 58% L4 72% L5 86% L6 100% L7 opening V4 / closing V2 L8 opening V6 / closing V4 |
| Parameter | Values L1–L8 |
|---|---|
| L4 – FLASH output | L1 gate-open indicator light L2 active when the gate is closed L3 active when the gate is open L4 warning light L5 electric locking L6 electric lock L7 holding magnet L8 maintenance indicator light |
| Parameter | Values L1–L8 |
|---|---|
| L5 – Opening force | L1 force 1 L2 force 2 L3 force 3 L4 force 4 L5 force 5 L6 force 6 L7 force 7 L8 force 8 |
| Parameter | Values L1–L8 |
|---|---|
| L6 – Closing force | L1 force 1 L2 force 2 L3 force 3 L4 force 4 L5 force 5 L6 force 6 L7 force 7 L8 force 8 |
| Parameter | Values L1–L8 |
|---|---|
| L7 – Maintenance reminder | L1 automatic, based on operating conditions L2 1,000 cycles L3 2,000 cycles L4 4,000 cycles L5 6,000 cycles L6 8,000 cycles L7 10,000 manoeuvres L8 12,000 manoeuvres |
| Parameter | L1–L8 values |
|---|---|
| L8 – Fault history | L1 most recent manoeuvre L2 2nd most recent manoeuvre L3 3rd most recent manoeuvre L4 4th most recent manoeuvre L5 5th most recent manoeuvre L6 6th most recent manoeuvre L7 7th most recent manoeuvre L8 8th most recent manoeuvre |
Force is not intended to overcome a gate fault. After changing the force setting, repeat the safety force measurement; after changing the speed, also repeat the automatic force calibration. Output FLASH changes function and required load depending on the selected mode; it is not a universal 24 V power supply. The warning light and lock must not be connected to it at the same time. For L6, use an electric lock 24 V, maximum 10 W, and for L7, a holding magnet 24 V, maximum 10 W; both must be electromagnets with no built-in electronics. The L6 lock is released by a short pulse when opening, while the L7 magnet holds the gate closed and switches off while the gate is moving. In L5 electric locking mode, the latch is held released while the gate is opening; a technician must confirm the selection and permitted current draw of the specific latch, rated at no more than 24 V and consisting of an electromagnet with no built-in electronics, based on the installed control board. In L5 electric locking mode, the latch is held released while the gate is opening; a technician must confirm the selection and permitted current draw of the specific latch, rated at no more than 24 V and comprising an electromagnet with no built-in electronics, based on the installed control board. When closing, the latch must mechanically engage again.
Additional commands
A continuous SbS command lasting longer than 3 s can keep the gate open, for example when used with a suitable time switch contact. Emergency movement when a safety device has failed is possible only under supervision while holding the command: after an unsuccessful command, repeat it within 3 s and keep holding it; movement starts after about 2 s and stops when the command is released. This mode is no substitute for repair and must only be used under supervision, with no people or objects in the path.
Receiver, remotes and antenna
TN2010L has an SM socket for a separate receiver. TN2020L has no built-in receiver; it is controlled via the main motor. The current option is NICE OXIBD; the remote type must match the receiver's coding. Existing installations may use SMXI, SMXIS or OXI; follow the receiver's instructions for programming radio remotes.
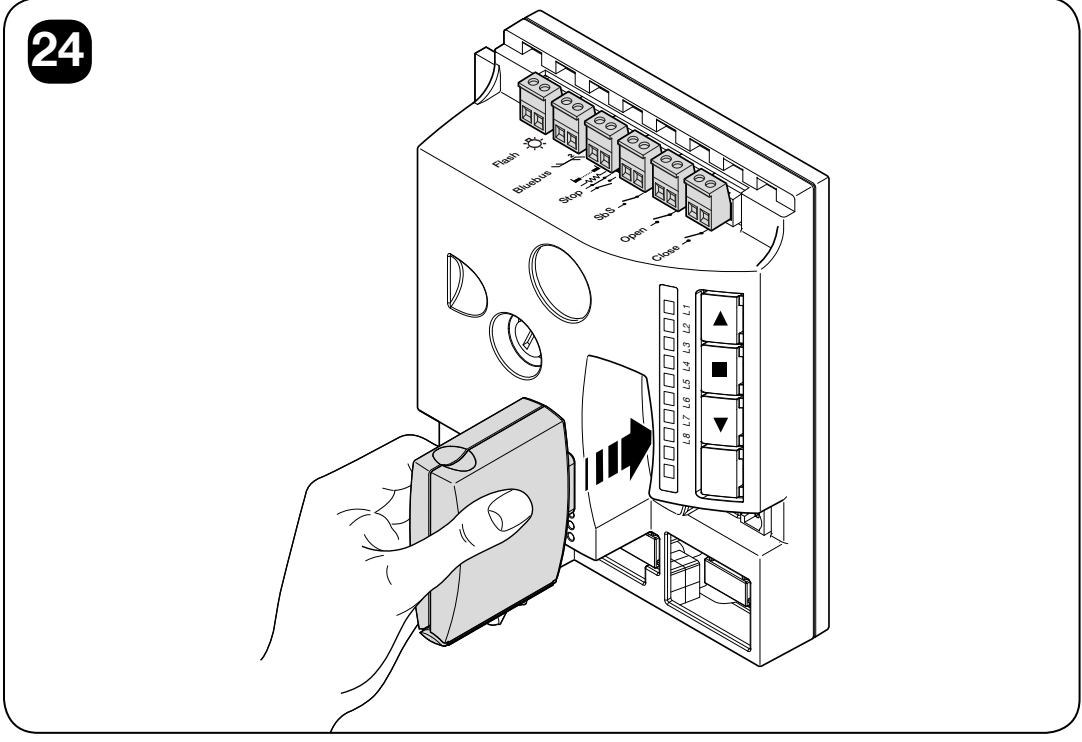
Disconnect the mains and backup power before inserting or removing the receiver. For OXIBD, connect the external antenna directly to the receiver's antenna terminals, connecting the signal and shield as shown in its instructions. Do not automatically connect it to the board's older Aerial terminal just because it is shown in the original diagram. Extended OXI/OXIBD receiver commands and pairing NICE remotes.
| Basic receiver output | Main TEN command |
|---|---|
| 1 | SbS step-by-step |
| 2 | Partial opening |
| 3 | Open |
| 4 | Close |
In extended mode, OXI also supports Stop, apartment-block and priority step-by-step commands, additional partial openings, open/close with hold-to-run, lock/unlock, and timed or continuous courtesy light. Select the options available for your receiver and refer to its own instructions. A suitable OView interface can be used for programming and diagnostics via BusT4; it is not a second control motor.
Backup power
The backup power unit connects to the main TN2010L, which controls the entire two-motor system from the backup supply. Do not connect the battery directly to the TN2020L motor or to the auxiliary STOP/SbS output.
The current TEN catalogue lists the NICE PSS324. It has its own connector and requires a compatible control-board generation and the correct connecting cable. The original NICE PS324 is an older, superseded version; for an existing installation, follow its original wiring instructions. The old and new connectors, and their charging controls, are not automatically interchangeable. Check the board and battery labels before replacing them.
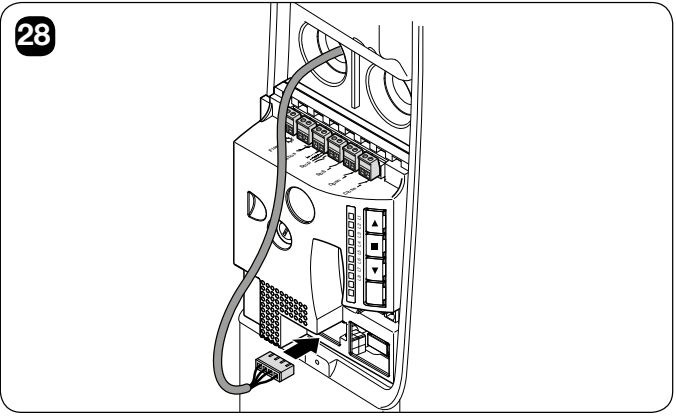
Install the battery with the system disconnected and use the designated keyed connector without forcing it into place. After installation, test a full cycle on mains and backup power, then restore the mains supply. The number of cycles depends on the gate, number of motors, temperature, and battery condition and age. The gate may move more slowly during a power outage. The manual release must remain accessible even when the battery is discharged.
Diagnostics and common faults
When a fault occurs, the warning light and courtesy light repeat a group of rapid flashes twice, with a 1 s pause. Count the flashes in one group. Normal warning-light flashing while the gate is moving is not this fault code.
| Flashes | Cause | What to check |
|---|---|---|
| 2 | Photocell is preventing movement | Check for obstructions, inspect the optics and wiring, and check the addressing. |
| 3 | Force limit triggered | Check for obstructions, friction and balance. Do not increase the force setting automatically. |
| 4 | STOP activated | Check the safety edge, contacts and learned STOP type. |
| 5 | Internal parameter error | Wait at least 30 s, then try a command. If the fault recurs, have the control board serviced. |
| 6 | Hourly manoeuvre limit exceeded | Wait a few minutes for the thermal/operating limit to reset. |
| 7 | Internal circuit error | Disconnect all power sources for a few seconds; if the fault recurs, arrange servicing and have the motor/cables checked. |
| 8 | Another command is already active | Remove any continuous or simultaneous command. |
| 9 | Automation locked | Unlock using the appropriate receiver command; do not confuse this with mechanical release. |
Control-board LEDs and courtesy light
First, distinguish Stand-by from a fault. With Stand-by enabled, after one minute of inactivity the other LEDs go out and the BlueBUS LED flashes more slowly. Before assessing the LEDs, wake the control unit with a command only if the path is clear and safe; be prepared for the gate to move. The following table applies when the control unit is awake.
| Indicator | Meaning |
|---|---|
| BlueBUS: green, once per second | Normal operation. Two quick green flashes = input change or command received. |
| BlueBUS: off / steadily lit | Check the power supply and fuses / fault requiring inspection of the control board. |
| BlueBUS: rapid and long red flashes | BlueBUS short circuit. Disconnect and check the wiring; after the issue is fixed, normal flashing may take about 10 s to resume. |
| STOP: lit / off | OK after learning / safety input activated or faulty. |
| SbS, OPEN, CLOSE | An illuminated LED indicates that the corresponding command is active. |
| L1 + L2 flashing | Connected devices must be detected. |
| L3 + L4 flashing | The gate positions must be learned. |
| L1 or L8 flashing on its own while idle | L1 = upper limit, position ≥95 %; L8 = lower limit, position ≤5 %. A technician must adjust the position and repeat the learning procedure; do not use the workshop encoder reset on an installed gate. |
| L1–L8 during movement | Current motor load; L1 low, L8 high. This is not the same as the relative force setting in the menu. |
| Auxiliary light flashes once per second | Automatic force learning is incomplete; if an error is flashing at the same time, count the fault code. |
If the remote control does not respond and its LED is off, check the battery. If the LED is lit, check the receiver and pairing. If the control board is completely inactive, a technician should check the mains supply and fuses; replace a fuse only after fixing the cause, using the type and rating shown on the label. If the gate reverses after moving briefly, first check for resistance in the gate, not just the force setting.
Maintenance warning during normal operation
A beacon that stays lit longer may indicate that servicing is due. This is not the same signal as the rapid groups of flashes used to indicate a fault. Applies when the FLASH output is configured accordingly; the maintenance indicator is an alternative mode of the same output.
| Service limit reached | Beacon in FLASH mode | Output in maintenance-indicator mode |
|---|---|---|
| Less than 80 % | Normal flashing: on for 0.5 s / off for 0.5 s. | Lights up for 2 s at the start of opening. |
| 81–100 % | Lights up for 2 s at the start of the manoeuvre, then flashes normally. | Flashes throughout the manoeuvre. |
| More than 100 % | Lights up for 2 s at the start and end of the manoeuvre; otherwise, flashes normally. | Flashes continuously. |
Have the warning addressed by a qualified technician; do not reset the counter just to stop the signal.
History of the last eight manoeuvres
- Press STOP/SET for about 3 s, release when L1 lights up, and select input LED L8.
- Press and hold STOP/SET; wait about 3 s. Lit LEDs indicate manoeuvres with a fault: L1 is the most recent, L8 the eighth most recent. An LED that is off indicates a manoeuvre with no fault; the history is read-only.
- While holding STOP/SET, select a manoeuvre using ▲ / ▼. The LED flashes the corresponding code from the table.
- Release STOP/SET.
Reset, motor direction and service counter
Clearing the main control unit memory
A reset clears learned devices, positions and user settings. Afterwards, you must select the number of motors again, perform the learning procedure and carry out the tests; this is not a standard way to fix a mechanical fault.
- With the motor stopped, press and hold ▲ + ▼, until all LEDs L1–L8 light up, about 3 s.
- Release the buttons. The LEDs flash rapidly for about 3 s and the control unit restarts.
- At the end, L1/L2 flash. Repeat the device detection, L8 setting and position and force learning.
This reset does not change the set direction of rotation or the encoder position. The plug-in radio receiver memory is managed separately, according to its own instructions.
Changing the direction of rotation
- With the gate stopped, press and hold STOP/SET for about 3 s and release when L1 flashes.
- Briefly press ▲ + ▼ simultaneously and release.
- The auxiliary light being on indicates reverse direction; off indicates the standard direction.
- Wait 10 s for the procedure to finish. Then repeat position learning and automatic force learning.
Restoring the encoder position
Resetting the encoder position is strictly a workshop procedure performed on a workbench. Never perform it with the motor installed on the gate. It sets the encoder to installation position L6 and restores the control unit’s default settings at the same time. If required, it must be carried out by a service technician in accordance with the full installation manual; it does not replace position learning on an installed gate.
Reading and resetting the service counter
Level II, input LED L7: press and hold STOP/SET and wait about 3 s for the level to be displayed. Briefly press ▲ + ▼ to read the counter: each flash represents 10 % of the set limit. For example, four flashes at a limit of 10 000 indicate 4 000–4 999 manoeuvres. Pressing and holding ▲ + ▼ for at least 5 s resets the counter; do this only after maintenance has been carried out. Then release STOP/SET.
Maintenance and safe use
Professional maintenance is required no later than every 6 months or 4 000 operating cycles, whichever comes first. For frequent use, shorten the interval accordingly. A counter warning does not replace the time-based maintenance interval.
- Before carrying out any work, disconnect the mains supply and battery and secure the gate against movement.
- Check the fixings, shafts, telescopic arms, cables, springs and guides for corrosion and wear. Replace damaged parts; spring adjustment must be carried out by a qualified technician.
- After maintenance, restore the power supply and repeat the safety tests. Document the result.
- Users may clean the photocell lenses with a slightly damp cloth and remove debris from the gate’s path. Do not use the gate if it is faulty; contact the installer.
Only pass through when the gate is fully open and stationary. Keep children and remote controls away from moving parts. Following the installer’s instructions, check monthly that when closing onto an object measuring 50 mm high on the ground, the drive reverses direction after the bottom edge makes contact. . If it does not work correctly, stop automatic operation and arrange a service visit. The drive and batteries must not be disposed of with household waste; a qualified professional should remove them and arrange recycling.
Approximate service life
Add the relevant weight and force indices and account for other relevant factors; include the latter factors if the probability of their occurrence exceeds 10 %. The weight in this table is used to estimate wear, not as a load rating or permission to automate a gate of any weight. Installation and operating limits take precedence.
| Characteristics of the complete automation system | Index | Service life graph |
|---|---|---|
| Factor | TN2010L + TN2020L |
The horizontal axis shows the sum of the indices in %, and the vertical axis shows the number of complete cycles. |
| Gate weight up to 100 kg | 10 % | |
| Over 100–180 kg | 20 % | |
| Over 180–230 kg | 30 % | |
| Over 230 kg | 50 % | |
| Force of movement up to 160 N | 5 % | |
| Over 160–240 N | 15 % | |
| Over 240–290 N | 30 % | |
| Over 290–350 N | 50 % | |
| Temperature above 40 °C / below 0 °C or humidity above 80 % | 10 % | |
| Dust or sand | 15 % | |
| Saline environment | 20 % | |
| Photocell interruption | 10 % | |
| STOP interruption | 20 % | |
| Speed above level L4 | 15 % |
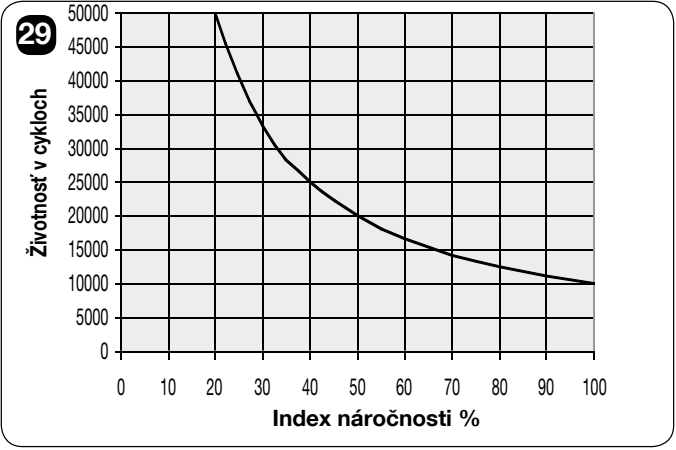
The chart of approximately 10,000–50,000 cycles is an indicative estimate assuming proper maintenance, not a guarantee of service life or a number of years. It does not simply count the number of openings and does not indicate a service interval.
NICE TN2020L technical specifications
| Purpose | Second motor without a control unit; controlled by the main TN2010L unit. |
|---|---|
| Power supply | 24 V DC −30/+50 % from the main unit's output; not 230 V. |
| Max. starting torque | 320 Nm |
| Rated torque | 220 Nm |
| No-load speed | 1.4 rpm at 24 V DC. |
| Speed at rated torque | 0.9 rpm at 24 V DC. |
| Max. power consumption at startup | 130 W / 5.5 A at 24 V DC. |
| Motor weight | 7.2 kg |
| Protection rating and environment | IP44; install inside the garage. |
| Operating temperature | −20 to +50 °C |
| Overall dimensions | Height 512 mm, width 150 mm, depth according to the drawing 160 mm; tabulated housing depth 158 mm. |
| Auxiliary light | Built-in LED lighting. |
| Insulation class | III |
For the complete TN2010L + TN2020L system, the manual specifies starting torque of 500 Nm, rated torque of 330 Nm, power consumption of 350 W / 1.4 A from the mains and a weight of 17.2 kg for both motors. The system's torque is not determined by simply adding the torques of the individual motors.
For the TN2010L + TN2020L system, at rated load, the duty cycle is 25 cycles/h and 14 minutes of continuous operation. At +50 °C, these values decrease to 4 cycles/h and 7 minutes for the complete two-motor system. The actual operating conditions are further limited by the load tables and the control system. The basic technical values apply at 20 °C ±5 °C.
To check suitability contact us with the gate type, height and width, balancing method, and expected number of cycles. For a replacement, include a photo of the label and control board.
How can I order this item?
Choose the option that suits you:
- order online: use the buy button to add the goods to your shopping cart (you will find the buy button here in the product variants table).
- order by email: place your order at [email protected]