Garage door opener kit for doors up to 11.4/12.6 m² NICE SPIDER800W with built-in Wi-Fi
| Product availability: | within 3 days | We usually ship the goods within 3 days. |
|---|
within 3 days
€390.83 including VAT
| Weight |
|---|
| 10 kg |
Description of Garage door opener kit for doors up to 11.4/12.6 m² NICE SPIDER800W with built-in Wi-Fi
- sectional garage doors up to a height of 2,6 m and an area of 11.4 m²,
- protruding up-and-over garage doors up to a height of 3 m and an area of 12.6 m²
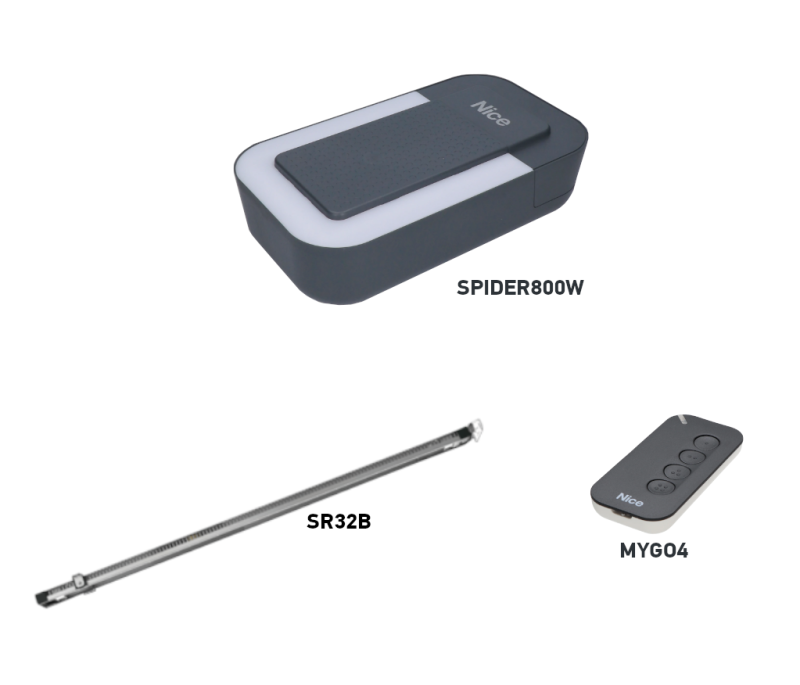
| The kit includes: | NICE-SPIDER800W | |||
|---|---|---|---|---|
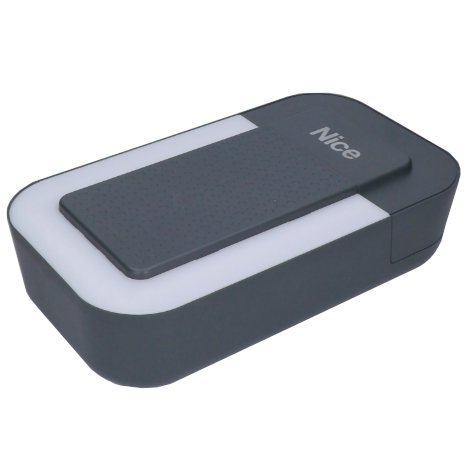 |
1 × | NICE SPIDER800W drive | ||
|
NICE SPIDER800W electromechanical drive for sectional garage doors with an area of up to 11,4 m², or protruding up-and-over garage doors with an area of up to 12,6 m². Motor with a built-in control unit and receiver, plus a built-in Wi-Fi module for control via an app. |
||||
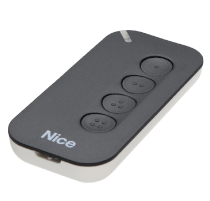 |
1 × | NICE MYGO4 remote control | NICE-MYGO4 | |
|
Four-button remote control for operating an automated gate remotely. You can use it to control four devices or send one device four different commands. |
Detail  |
|||
 |
1 × | SR32B belt rail, 3.2 m | NICE-SR32B | |
Pre-assembled belt rail SR32B with a length of 3.2 m. For sectional doors up to approx. 2.6 m; the limit for up-and-over doors varies depending on the construction. See the compatibility table. | Detail |
|||
 |
1 × | NICE SPIDER800 installation manual | ||
|
Installation manual for a successful setup, with wiring diagrams and instructions for programming and pairing remote controls. |
Download |
|||
| 1 × | Mounting accessories | |||
|
Screws for attaching the drive to the rail, mounting brackets, emergency release cord, etc. |
||||
NICE SPIDER800W is a garage door kit with a belt rail SR32B 3.2 m and one MYGO4. It has a built-in MCU2 control unit, radio receiver and Wi-Fi. The system is powered from the mains 230 V AC.
The steel-reinforced belt ensures quiet operation. The control unit learns the end positions, force and deceleration, and detects obstacles. In the event of a power failure, the door can be released with a cord and operated manually.
Accessories and control
Choose safety devices according to the actual risks posed by the garage door. Obstacle detection by the operator does not replace photocells, a safety edge or force measurement during commissioning.
| What | Why | Type |
|---|---|---|
| Control unit | Operator setup, operation and servicing; the control board is built in. | |
| Rail | The operator moves a trolley with an arm and requires a suitable belt rail. |
|
| Taller door | Choose the rail extension according to the door type, height, area and resistance. | |
| Up-and-over door | Up-and-over doors with counterweights require a suitable arm geometry. |
|
| Photocells | Obstacle detection in the protected area. Choose the correct electrical interface. | |
| Flashing light | Visible indication of door movement, with an optional external antenna. | |
| Remote control | The receiver is built in. The remote control must be stored in its memory. | |
| Backup power supply | Allows operation during a power failure when a battery is added. | |
| Service settings | Diagnostics and more detailed settings via BusT4. | |
| Wi-Fi | Phone control and service configuration. |
|
SPIDER800W kit contents
Compare the drive type, speed, control options and limits of the specific door. Greater force or higher speed alone does not guarantee suitability. Safety accessories and backup power are selected separately.
| Belt-drive kit with Wi-Fi |
|---|
NICE SPIDER800W 800 N; SR32B 3.2 m and MYGO4. Built-in Wi-Fi in the MCU2. |
Which garage door is the opener suitable for?
With the standard rail SR32B the approximate dimensions depend on the type of garage door. The dimensions in the table are width × height. Suitability also depends on the balance, friction, and installation space.
| Door type | Approximate size | Condition |
|---|---|---|
| Sectional | 4.4 × 2.6 m | Approximately 11.4 m². |
| Non-protruding up-and-over | 4.2 × 2.4 m | SPA5; area 10.08 m². |
| Protruding up-and-over | 4.2 × 3.0 m | SPA5; area 12.6 m². |
| Spring-balanced up-and-over | 4.2 × 3.0 m | Depending on the installation, SPA5 is not required; check the travel path and balance. |
Maximum force 800 N and rated force 400 N indicate the motor's pulling force, not the door's weight in kilograms. When testing the door with the opener disengaged, open and close it manually through its full travel; the required force must not exceed 225 N. The opener must not be used as a substitute for repairing damaged springs or an incorrectly balanced door.
The SR32B rail is 3.2 m long, with a usable carriage travel of 2.8 m. The door height also depends on its construction and the arm. For a taller door, you can add an 0.8 m SR08B extension with a longer belt; with a 4 m travel path, usable travel is 3.5 m. An extension alone does not confirm that a larger or heavier door is suitable. Send us the width, height, door type, and required travel via contact.
Cycle count and load
One cycle is a complete opening and closing. The table gives the maximum values for each height; door resistance reduces them further. The overall limit of 50 cycles/day and a maximum of 4 minutes of continuous operation.
| Door height | Cycles/hour | Consecutive |
|---|---|---|
| Up to 2 m | 20 | 10 |
| Over 2 m up to 2.5 m | 15 | 7 |
| Over 2.5 m up to 3 m | 12 | 5 |
| Over 3 m up to 3.5 m | 10 | 4 |
At a motor load of up to 250 N, the number of cycles is reduced by 25%; at 250–400 N, it is reduced by 42%. These operating factors do not replace the manual test with the 225 N limit. Higher resistance requires the mechanism and opener suitability to be checked. The thermal limit may temporarily prevent further operation; allow the opener to cool down.
Installing the rail and opener
Install with the door closed and both the mains power and backup battery disconnected. The door must move smoothly by hand and remain balanced in each position when disconnected from the carriage. Resolve any locks that would prevent automatic movement before installation. Springs and counterweights must be adjusted by a qualified technician.
- Check the clearance above the door, rail length, and the strength of the wall and ceiling. Keep the opener and release cord accessible.
- For a two-piece rail, slide both sections into the connector as far as they will go. With the ready-made SR32B this connection step is not necessary. Check that the carriage moves freely and continuously.
- Place the motor head on the rail and secure it with the supplied screws. The head may also be rotated 90° relative to the travel axis, as shown in the installation drawing.
- Adjust the belt tension. An overtightened belt can damage the opener; a loose belt causes noise and unreliable movement. When extending the rail, use the correct longer belt.
- Secure the front bracket to a sufficiently strong substrate and suspend the rear section from the ceiling brackets. Align the rail and tighten all fasteners.
- With the door closed, disengage the carriage, position the door bracket in line with the rail, and connect the drive arm. A thin panel must be suitably reinforced; the installation must withstand the force of the opener without deforming.
- Fit the release cord. Manually move the door through its full travel, check the clearances, and re-engage the carriage before programming.
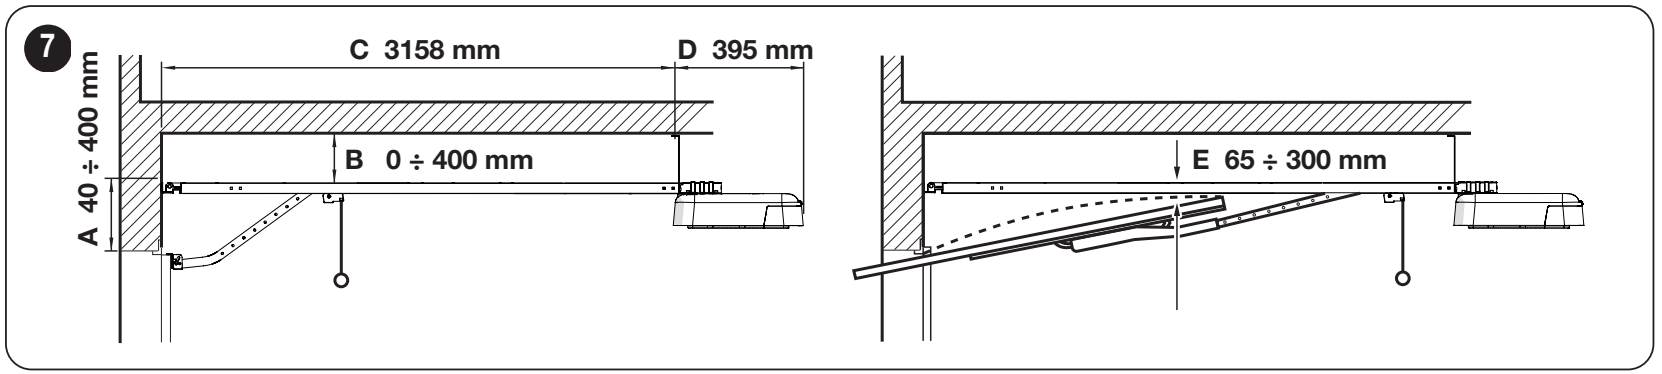
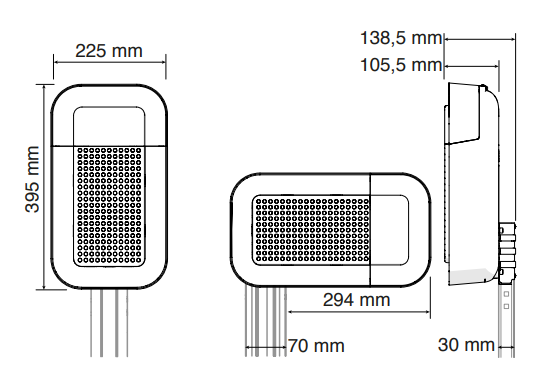
In the orientation shown:
- A = 40–400 mm
- B = 0–400 mm
- C = 3,158 mm
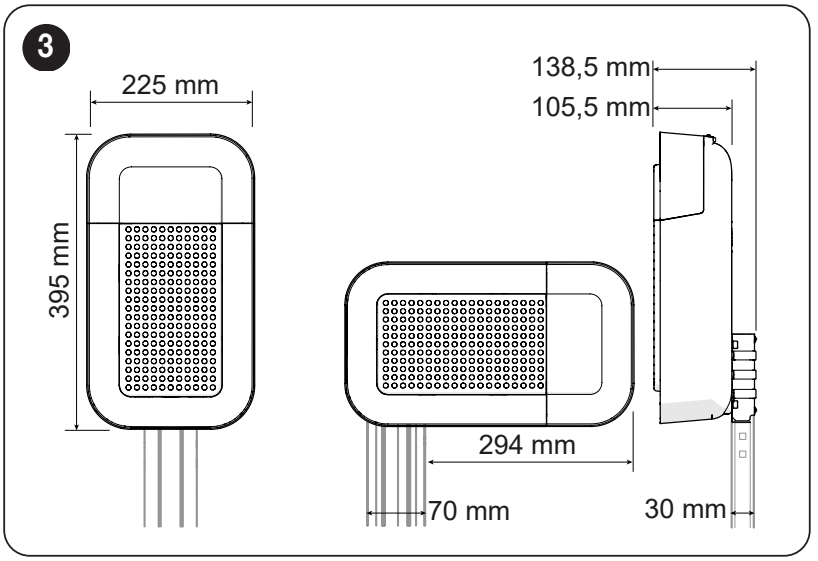
- D = 395 mm.
For an up-and-over door, maintain E = 65–300 mm, i.e. the clearance between the rail and the highest point of the door's top edge during movement. The dimensions apply to the installation configuration shown.
Wiring and mains power supply
Use a grounded socket 230 V AC, 50/60 Hz, with a protective conductor and a means of safe disconnection. Do not cut off or remove the supplied power cord or plug. A qualified electrician should install the appropriate socket and supply cable. Route low-voltage wires separately from the mains wiring and secure them against pulling and contact with moving parts.
| Connection | Cable / maximum length |
|---|---|
| Supply to socket | 3 × 1.5 mm²; 30 m. For lengths over 30 m, use at least 3 × 2.5 mm² and provide grounding at the automation system as specified by the electrician. |
| FLASH beacon | 2 × 0.5 mm²; 20 m. |
| Antenna | Separate RG58 coaxial cable; 10 m, recommended length less than 5 m. |
| Push button / key switch | 2 cables, 2 × 0.5 mm², or one 4 × 0.5 mm² cable; 50 m. The NO command contact is voltage-free. |
| BlueBUS photocells | 2 × 0.7 mm²; 30 m; TX and RX wired in parallel, no polarity. |
| Relay photocells | 4 × 0.5 mm²; 30 m; separate power supply and safety contact, as shown in the wiring diagram. |
| STOP safety edge | 2 × 0.5 mm²; 20 m. |
Mains power must not be connected to the accessory inputs. The cable cross-section does not change the permitted current draw or the voltage of the relevant output.
Control board, terminals and polarity
SPIDER800W has a built-in MCU2 control unit with BlueBUS and L1–L8 programming LEDs. This version also has built-in Wi-Fi.
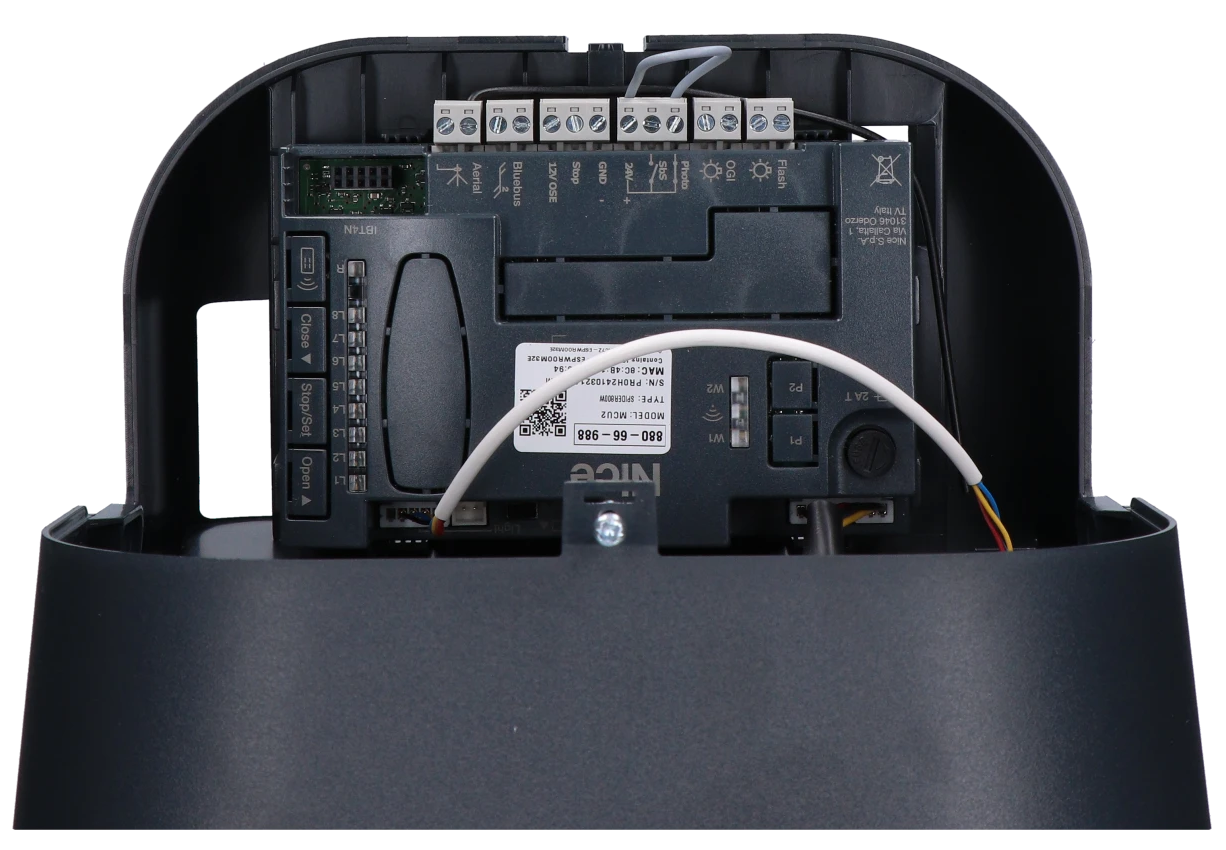
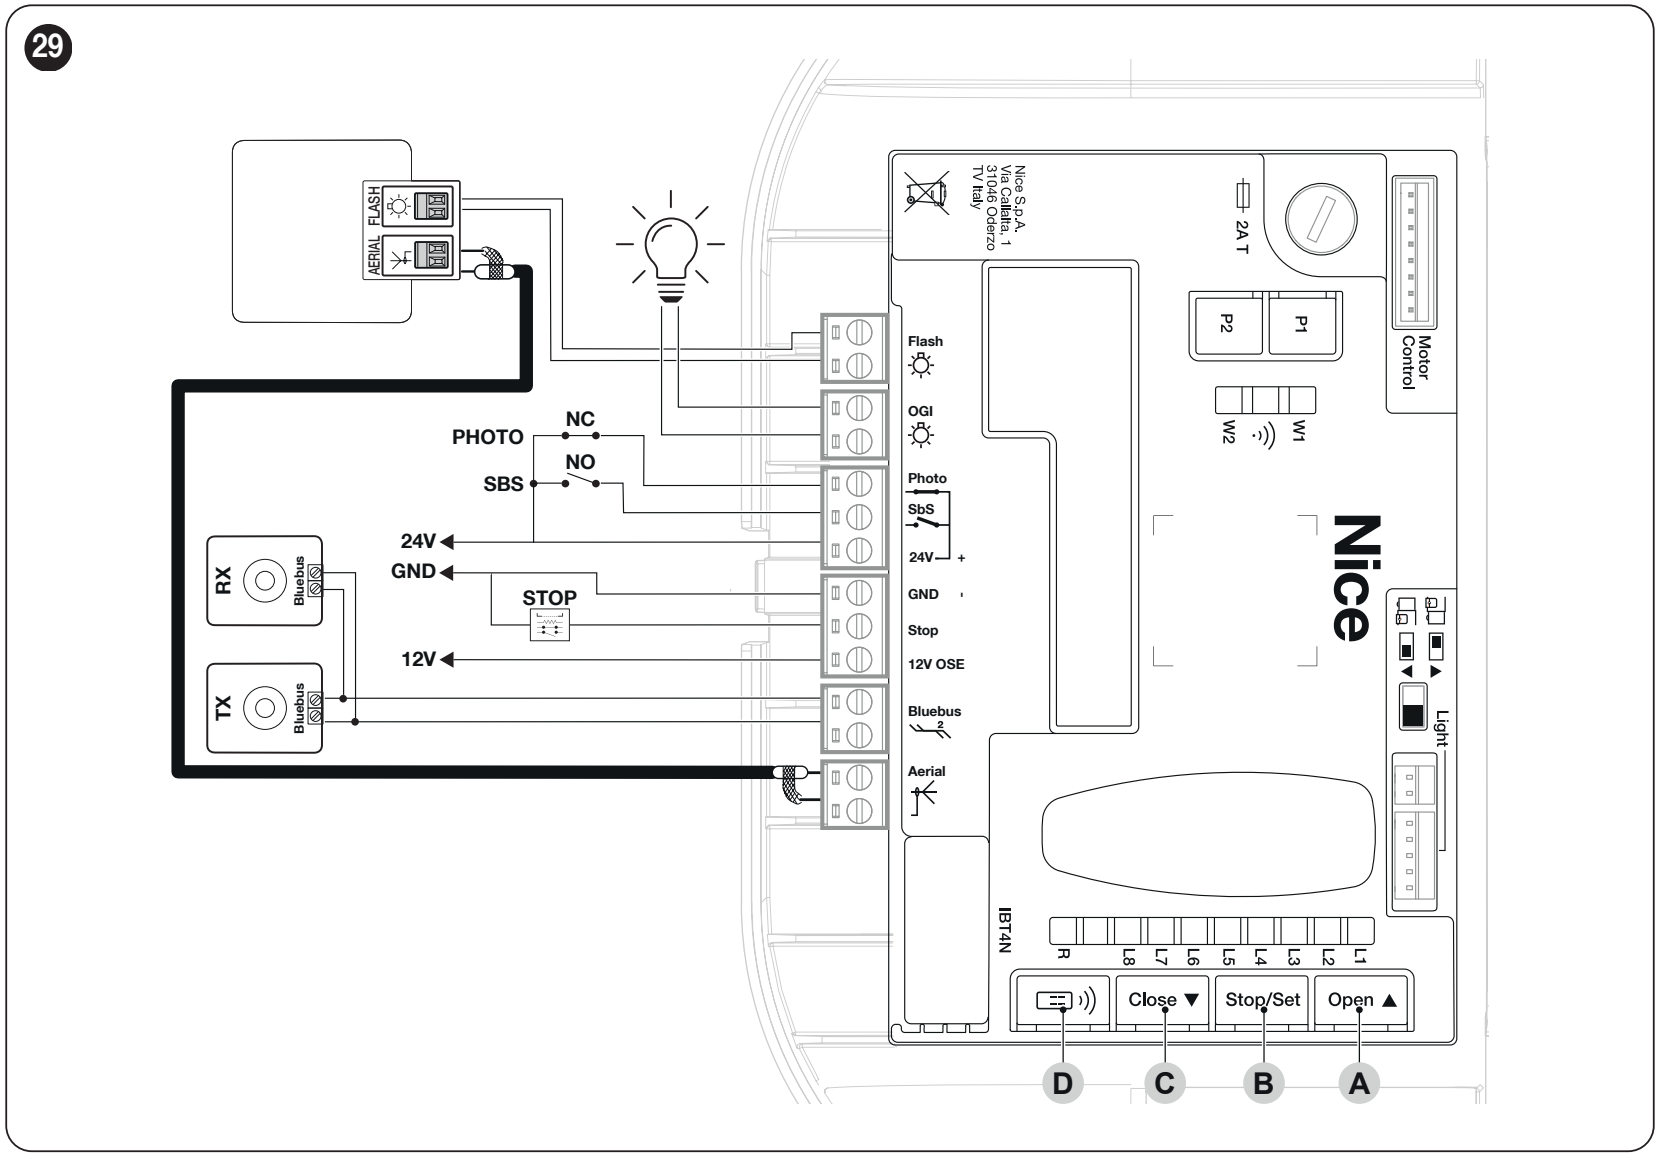
| Terminal | Function and connection |
|---|---|
| 24 V / GND | 24 V is positive (+), GND is negative (−). Auxiliary 24 V DC power supply, tolerance −30% / +50%, maximum 100 mA total. |
| BlueBUS | Two-wire power supply and communication for compatible devices; EPMB are connected in parallel. No +/− polarity. |
| PHOTO | Voltage-free NC contact between PHOTO and 24 V (+). Relay photocells have a separate 24 V (+) / GND (−) power supply. |
| SbS | Voltage-free NO push button between SbS and 24 V (+); a brief contact closure sends a step-by-step command. |
| STOP / GND | STOP safety input referenced to GND. NO, NC or 8.2 kΩ type is learned during startup. The contact itself has no polarity. |
| 12 V OSE / STOP / GND | Optical safety edge: 12 V OSE = positive (+), STOP = signal, GND = negative (−). 12 V DC power supply, maximum 15 mA. Connect only a compatible OSE edge, following its instructions. |
| FLASH / OGI | Separate two-pole outputs, standard 24 V DC, maximum 10 W per output. FLASH for the warning light, OGI for the open-gate indicator. The function depends on the settings. |
| AERIAL | Coaxial antenna input: centre conductor and shield as shown in the diagram; this is not an accessory power supply. |
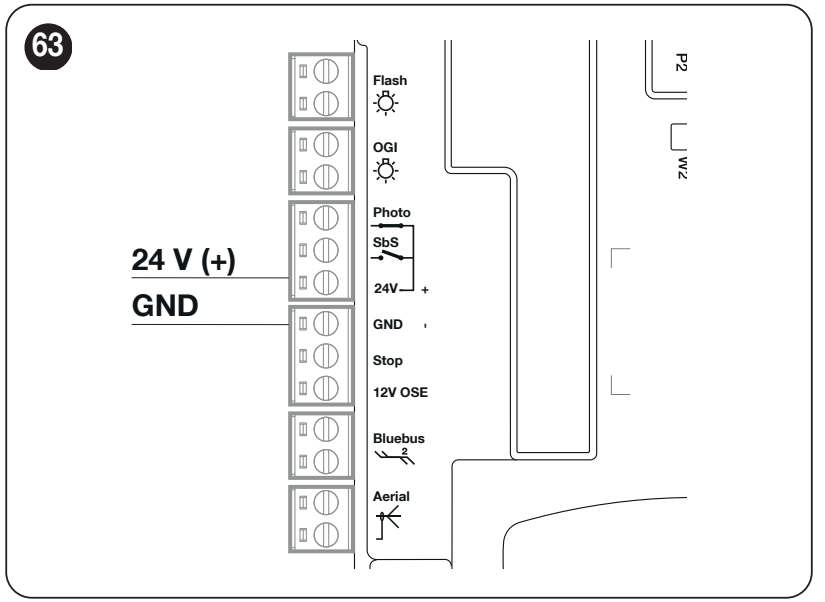
Push button, key switch or relay
Connect only a voltage-free NO contact, such as a push button or a control module relay, to SbS. The contact connects SbS and 24 V (+). Do not apply the module's output voltage to the command input. If the module needs power, connect it separately to 24 V (+) and GND (−) and observe the 100 mA total limit.
Safety edge and STOP input
STOP halts movement and briefly reverses it. When changing a safety device, you must relearn the devices. Connect multiple NO contacts in parallel and NC contacts in series. Connect 8.2 kΩ edges and their combinations according to the specific wiring diagram; a standard switch does not provide the same fault monitoring as a monitored edge.
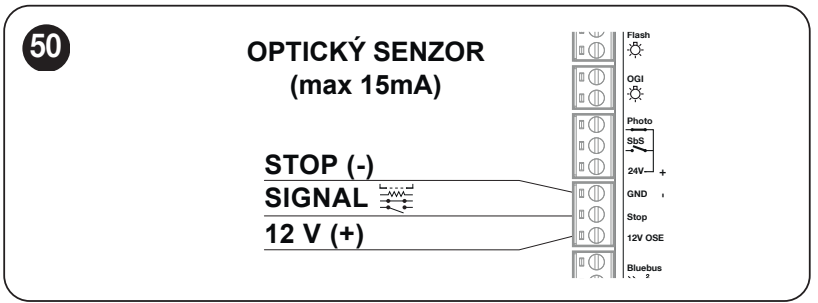
Photocell wiring
For a simple two-wire connection, choose NICE EPMB with BlueBUS. Connect both wires from TX and RX in parallel to the BlueBUS pair. This bus has no polarity; the 24 V (+) / GND (−) markings belong to other terminals.
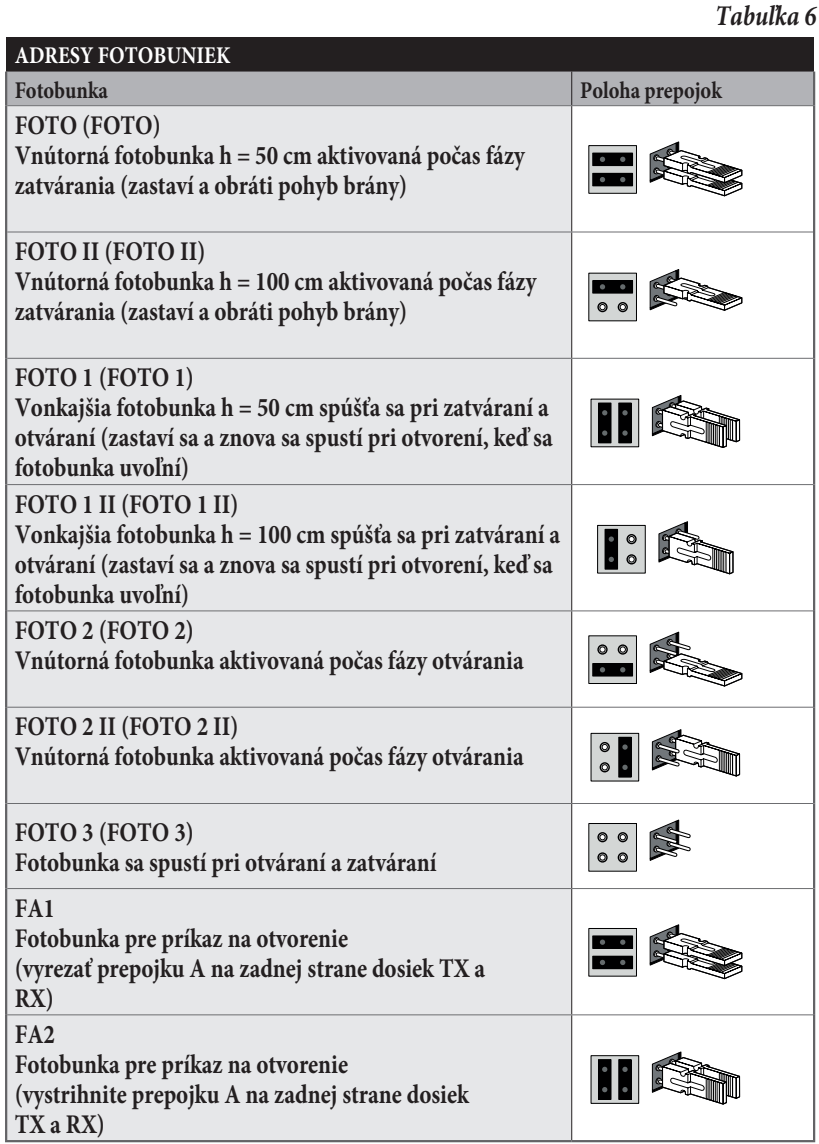
- With the power disconnected, set the same jumper address on TX and RX of each pair. Each additional pair must have a different address.
- Secure and align TX with RX, then connect BlueBUS. Choose the function and installation height according to the area being protected.
- After wiring or changing addresses, perform device learning and a separate safety test.
| Address | Position and response |
|---|---|
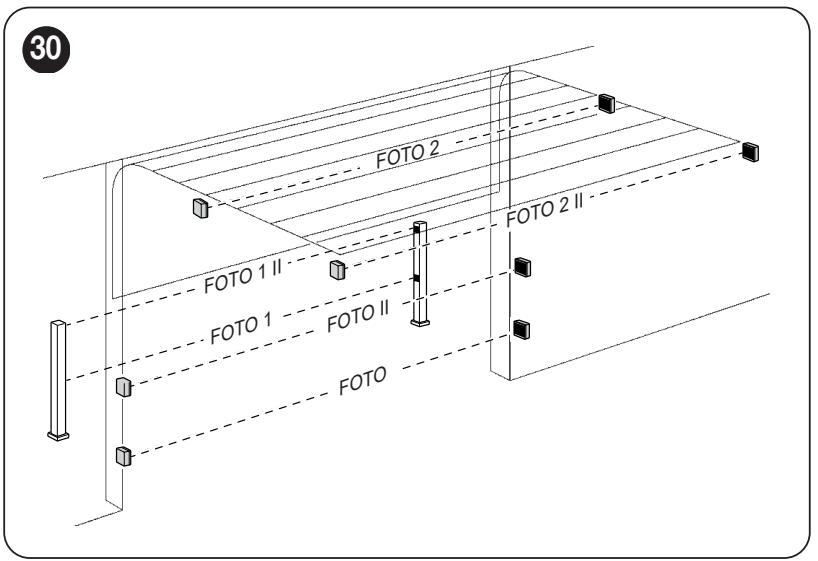
| PHOTO / PHOTO II | Interior photocell at a height of 50 / 100 cm; stops and reverses movement while closing. |
| PHOTO 1 / PHOTO 1 II | Exterior photocell at a height of 50 / 100 cm; stops during both opening and closing, then resumes opening when the beam is clear. |
| PHOTO 2 / PHOTO 2 II | Interior protection active during opening; position according to the drawing. |
| PHOTO 3 | Opening and closing protection; select according to the actual risk and location. |
Do not place pairs with the following addresses next to each other: PHOTO / PHOTO 2, PHOTO II / PHOTO 3, PHOTO 1 / PHOTO 2 II, to prevent interference. Photocells used as an opening command do not replace a safety pair.
Relay photocells on PHOTO
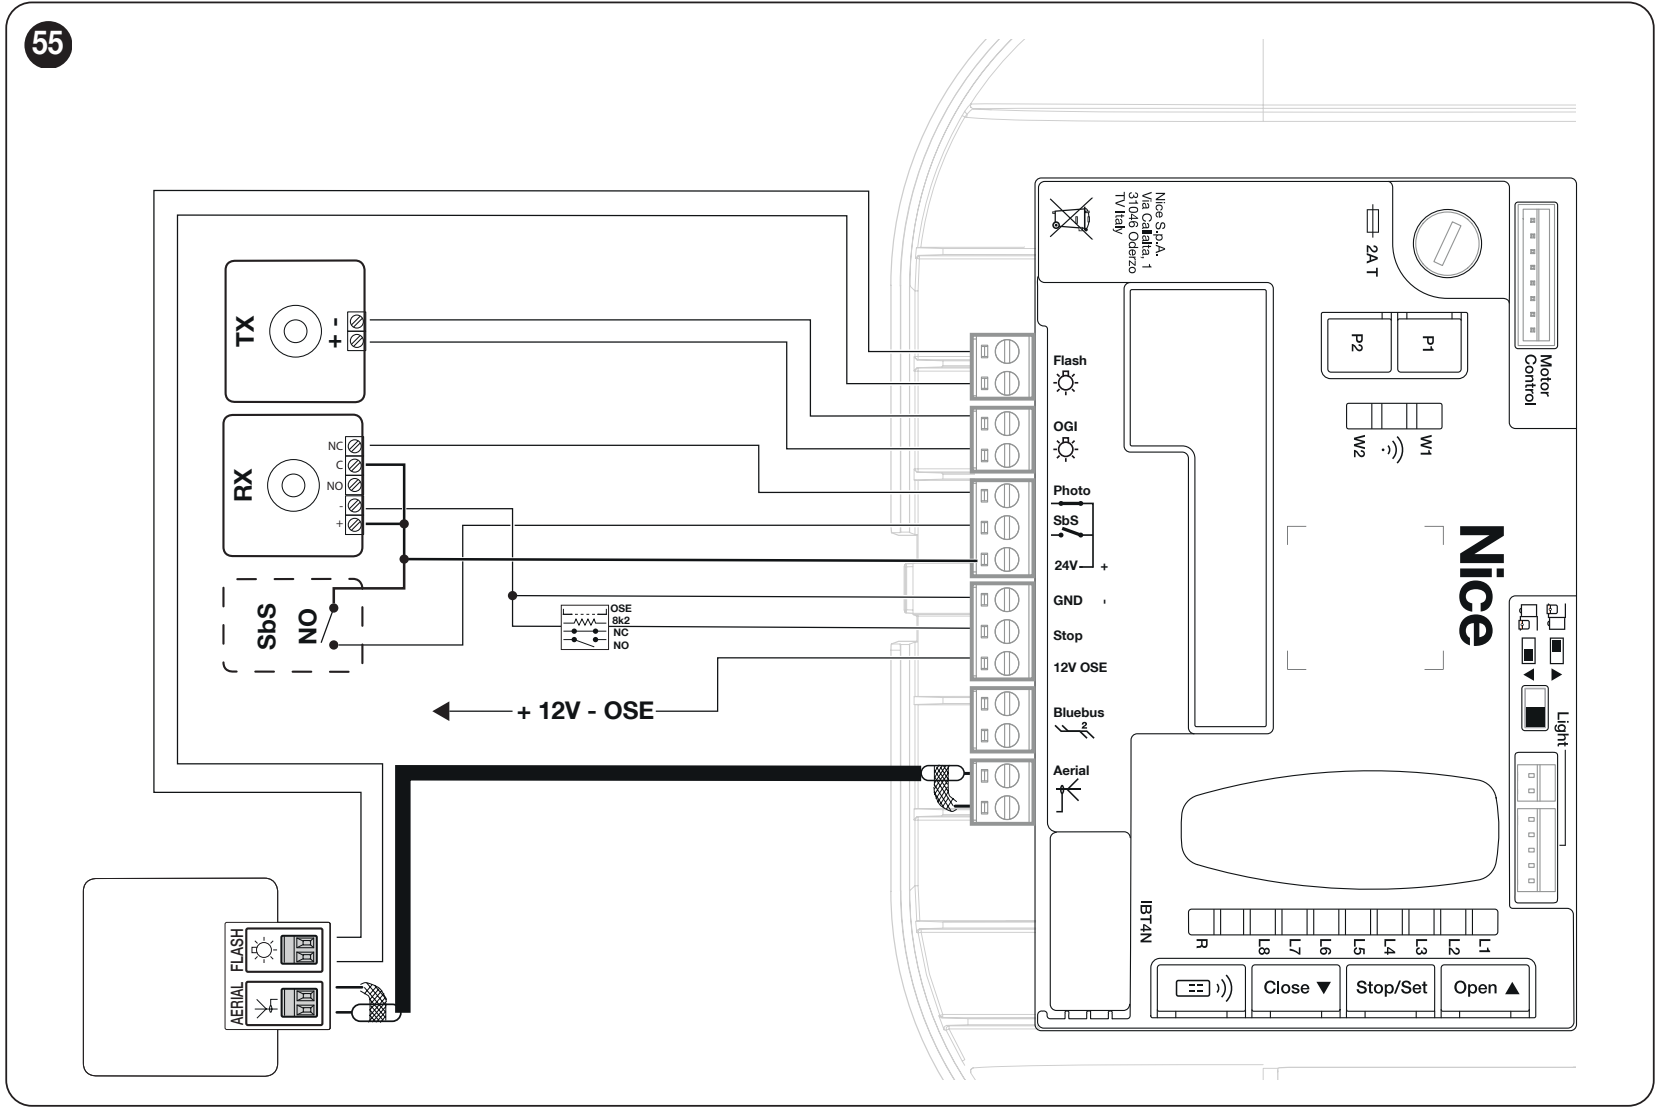
For EPM without testing: on both TX and RX, 1 = positive, 2 = negative. Power them from terminals 24 V (+) and GND (−). On RX, use 4 – COM and 5 – NC between 24 V (+) and PHOTO. Terminal 3 is NO and is not used for the PHOTO safety input. The total current draw from the auxiliary power supply must not exceed 100 mA.
Relay photocells with PHOTOTEST
For the tested wiring, power TX from the OGI, while RX remains on 24 V (+) / GND (−). With the board oriented exactly as shown in the diagram below, the upper OGI terminal is negative (−), and the lower one is positive (+). On the EPM, terminals 1 (+) and 2 (−) are for power; RX terminals 4 – COM and 5 – NC go between 24 V (+) and PHOTO. OGI supplies 24 V DC, max. 10 W. Do not confuse these wires with the FLASH output.
Set level II/L5 to value LED L2 – PHOTOTEST and relearn the devices. Before movement, the control unit tests the response of the photocells; if the test fails, the maneuver is blocked. This relay procedure is not used with BlueBUS EPMB.
FLASH beacon, lighting, and antenna
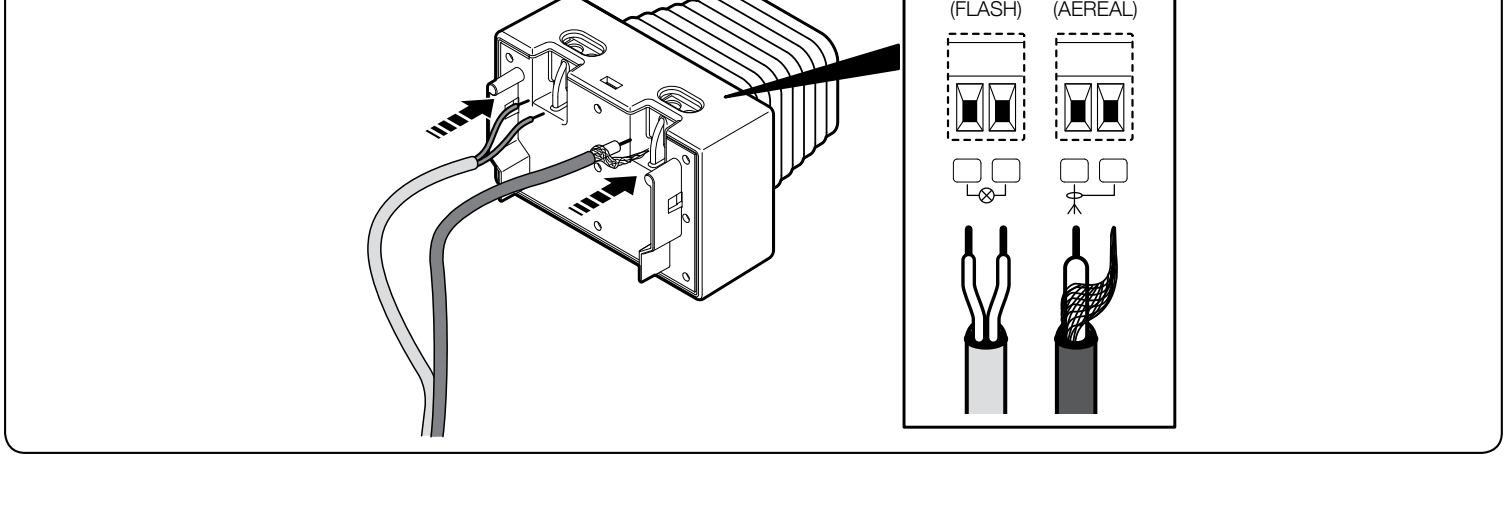
NICE ELDC connect it using its terminal block marked FLASH to the FLASH pair on the MCU2; the standard output is 24 V DC, max. 10 W. The output function must be set accordingly in programming. Do not connect a 230 V mains-powered beacon to these terminals.
For the FLASH pair on the beacon, follow the markings on the connected device. The polarity is not marked in this ELDC detail; do not apply the orientation of the auxiliary 24 V / GND terminal block to it. The AERIAL input on the ELDC is for a separate antenna: connect the coaxial cable to the control unit’s antenna connector as shown. Do not confuse the antenna connection with the beacon power supply.
The drive also has built-in LED garage lighting. The OGI output is also intended for external open-position indication; if you change its function, check the OGI setting and load.
Initial startup and setup
First complete the mechanical installation and wiring, secure the carriage, and clear the entire travel area. Check STOP, the photocells, and the direction of travel. Position learning, force learning, and transmitter pairing are separate procedures.
Before switching on for the first time, position the secured gate approximately halfway along its travel. With a new, unconfigured control unit, 4 red BlueBUS flashes are a normal warning that configuration is missing. The beacon and interior light should be off at rest; in a standard installation, the direction selector is set to the left.
1. BlueBUS and STOP learning
- Switch on the power. On first startup, L1 and L2 flash; run the recognition procedure even if no accessories are connected.
- Press and hold OPEN + STOP/SET for approximately 3 s. Release when L1 and L2 start flashing rapidly.
- Wait for the procedure to finish. STOP should be lit, and L1 and L2 should be off. On first installation, L3 and L4 start flashing: the positions need to be stored.
If you change the direction using the rotary switch on the board, do so with the power disconnected, according to the drive layout, and relearn the devices. The direction change takes effect only after this learning procedure; do not change direction by swapping the safety accessory wires.
2. Storing the open and closed positions
- Press and hold STOP/SET + CLOSE for approximately 3 s. L1 starts flashing.
- Use OPEN / CLOSE to set the desired fully open position. Press and hold STOP/SET for 3 s; L1 lights up and the open position A1 is stored. Release.
- While L8 is flashing, use OPEN / CLOSE to move the gate to the fully closed position at floor level. Press and hold STOP/SET for 3 s; L8 lights up. Release; the programming LEDs go out.
- Send an SbS or OPEN command. The drive performs a complete automatic force-learning cycle.
The time limit for each step involving a movement command is 60 s; if this limit is exceeded, start the position-learning procedure again. The control unit calculates intermediate positions, slowdown, and partial opening; these can be adjusted in more detail via the service interface.
Force learning and the first movement test
Force learning runs an automatic opening and closing maneuver at increased force. Keep people and objects away from the gate during this procedure. The interior light flashes intermittently while learning is in progress. Force learning must be repeated after changing the positions, speed, direction, or mechanical balance.
If the procedure is interrupted by STOP, a photocell, or a power failure, resolve the cause and resume learning with another SbS / OPEN / CLOSE command.
Pre-commissioning test
- With the power disconnected and the carriage disengaged, open and close the gate manually; the force required throughout the travel must not exceed 225 N. Then re-engage the carriage.
- Open and close the gate again; it must reach the stored positions without binding or deforming the brackets.
- Check deceleration at the end positions, belt slackening after the gate stops, manual release, and re-engagement.
- Interrupt each photocell at TX, at RX, and midway across the beam; check that the safety response is correct. Test all STOP devices.
- A technician must measure impact forces and verify the safety of the entire gate. Do not use a higher force setting to compensate for poor mechanical operation. Repeat the measurement after changing the force setting.
- Give the user instructions for operation, manual release, and maintenance. Only pass through when the gate is fully open and stationary.
MCU2 programming
Use OPEN, STOP/SET, CLOSE, and LEDs L1–L8 on the board. Program with the gate stationary. A short flash of the selected function LED indicates OFF; a longer flash indicates ON. After changing the force or sensitivity, check the gate’s safety again.
Level I – ON / OFF functions
- Press and hold STOP/SET until L1 starts flashing, then release.
- Use OPEN / CLOSE to move the flashing LED to the desired function.
- Press STOP/SET briefly to toggle ON / OFF. Set another function if required.
- To save and exit, wait 20 s without pressing a button.
| LED – function | Meaning / factory default |
|---|---|
| L1 – Automatic closing | ON: closes after opening once the pause set at level II/L1 has elapsed. OFF: waits for a command. Factory default: OFF. |
| L2 – Close after photocell activation | ON: after the photocell beam is cleared, it uses a 5 s pause. With automatic closing enabled, it can stop opening when the beam is cleared; otherwise, it completes the opening cycle and closes after 5 s. STOP cancels this subsequent response. Factory setting: OFF. |
| L3 – Always close | ON: if power is restored and the gate is detected open, it flashes a warning for 5 s, then closes. Factory setting: OFF. |
| L4 – Standby | ON: after 1 minute of inactivity, it switches off some of the electronics; BlueBUS signals slowly. Take the power supply for connected devices into account. Factory setting: OFF. |
| L5 – Protection against unauthorized opening | ON: if forced opening is detected, the gate closes. App notifications require a compatible interface and configuration. Factory setting: OFF. |
| L6 – Pre-flashing | ON: the warning light flashes for 3 s before movement begins. Factory setting: OFF. |
| L7 – Disable internal radio | ON: the internal receiver is disabled, for example when using an external OXI/OXIBD. OFF: the built-in radio receiver is active. Factory setting: OFF. |
| L8 – Light / heavy gate | ON: preset for a light gate. OFF: preset for a heavy gate. Changes the group of force, sensitivity and speed values; force learning must then be performed. Factory setting: OFF. |
Level II – adjustable values
- Hold STOP/SET until L1 starts flashing; then release.
- Use OPEN / CLOSE to select the parameter input LED.
- Hold STOP/SET. After approximately 3 s the LED for its current value lights up. Keep holding STOP/SET and use OPEN / CLOSE to select a different value LED.
- Release STOP/SET. Set the next parameter or wait 20 s without pressing any buttons to save and exit.
The factory-set value LED is shown in bold. The light/heavy gate preset or settings made via the service interface may change some values; the current indication on the control board takes precedence.
| Input LED – name and description | Setting LED – value |
|---|---|
| L1 – Pause Automatic closing time; applies when I/L1 is ON. | L1 – 5 s L2 – 15 s L3 – 30 s L4 – 45 s L5 – 60 s L6 – 80 s L7 – 120 s L8 – 180 s |
| L2 – Step-by-step command Sequence for the step-by-step input and the first radio command. Modes L4, L5, L7 and L8 also change the OPEN / CLOSE commands. | L1 – open – stop – close – stop L2 – open – stop – close – open L3 – open – close – open – close L4 – shared input L5 – shared input 2; holding for more than 2 s = STOP L6 – step-by-step 2; holding for more than 2 s = partial opening L7 – movement only while the command is held L8 – semi-automatic opening, closing while the command is held |
| L3 – Speed Percentage of maximum speed. Force learning is repeated after changing this setting. | L1 – 30% L2 – 44% L3 – 58% L4 – 72% L5 – 86% L6 – 100% L7 – opening V4 (72%), closing V2 (44%) L8 – opening V6 (100%), closing V4 (72%) |
| L4 – FLASH (OUT1) The output function must match the load. Output: 24 V DC, max. 10 W. | L1 – gate-open indicator L2 – active when the gate is closed L3 – active when the gate is open L4 – warning light L5 – electric latch L6 – electric lock L7 – magnetic lock L8 – maintenance indicator |
| L5 – OGI (OUT2) Second output: 24 V DC, max. 10 W; phototest requires correct TX wiring and a new learning cycle. | L1 – OGI gate-open indicator L2 – PHOTOTEST L3 – gate status L4 – garage lighting L5 – radio channel 1 L6 – radio channel 2 L7 – radio channel 3 L8 – radio channel 4 |
| L6 – Motor force Adjustment values in %: opening / closing. This is not the force measured on impact. | L1 – 60 / 30% L2 – 60 / 40% L3 – 70 / 40% L4 – 70 / 50% L5 – 80 / 50% L6 – 80 / 60% L7 – 90 / 70% L8 – 90 / 80% |
| L7 – Obstacle sensitivity Opening / closing sensitivity levels; these are not newtons. | L1 – disabled L2 – 10 / 20 L3 – 20 / 30 L4 – 30 / 40 L5 – 40 / 50 L6 – 50 / 60 L7 – 60 / 70 L8 – 70 / 80 |
| L8 – Mechanical relief A brief reversal releases tension once the gate reaches the closed position. Force learning is required after changing this setting. | L1 – no relief L2 – minimum L3 – intermediate level 3 L4 – intermediate level 4 L5 – intermediate level 5 L6 – intermediate level 6 L7 – intermediate level 7 L8 – maximum |
If L1 and L8 flash simultaneously during adjustment, the current value is outside the range available on the board, for example after being set via the service interface. Check this setting, or use the OPEN / CLOSE buttons to select a suitable value from the available options.
Remote controls and pairing
The receiver is built in. MYGO4 from the set must be stored in memory. The MCU2 supports O-Code and BD and has a 100-remote memory capacity in Mode 1; when adding another remote, check the encoding, not just the 433.92 MHz frequency.
Mode 1 – all buttons
- Hold RADIO until the green R LED lights up, then release it.
- Within 10 s hold down any button on a one-way remote. Release it at the first of the three green flashes of R.
- On a two-way remote, press and immediately release the button; storage is confirmed by three green flashes of R and a short vibration of a compatible remote.
| Button in Mode 1 | Command |
|---|---|
| 1 | Step-by-step (SbS) command |
| 2 | Partial opening |
| 3 | Open |
| 4 | Close |
Mode 2 – one button
Press and release RADIO n times, according to the command number. LED R will flash the same number of times. Within 10 s, store the selected remote button as described above; repeat the procedure for each additional button.
| Number of RADIO button presses | Command |
|---|---|
| 1 | SbS |
| 2 | Partial opening 1 |
| 3 | Open |
| 4 | Close |
| 5 | STOP |
| 6 | SbS for shared entrance |
| 7 | High-priority SbS |
| 8 | Partial opening 2 |
| 9 | Partial opening 3 |
| 10 | Open and disable automatic operation |
| 11 | Close and disable automatic operation |
| 12 | Disable automatic operation |
| 13 | Enable automatic operation |
| 14 | Lighting – timer |
| 15 | Lighting – switch on/off |
On the MCU2, the high-priority button can also operate the system when automatic operation is disabled. For normal operation, use SbS; select the disable commands only when you need this function.
Adding a remote using an existing remote
Carry out the procedure within range of the operator and only when learning is enabled. Applies to one-way remotes.
- On the new remote, hold down the required button for 7 s and release it.
- On the original remote, slowly press and release the stored button three times.
- On the new remote, press and release once the same button as in the first step.
Clearing the radio memory
This deletes all stored remotes. Keep holding RADIO even after LED R lights up and then goes out. At the next flash, release it exactly on the fifth flash. Five quick flashes confirm success. Clearing the radio memory is a separate procedure from resetting the control unit.
For two-way remotes, follow their instructions to also remove the stored pairing on the transmitter.
Deleting one remote or button
- Hold RADIO until the green R LED lights up and then goes out; release RADIO at that point.
- One-way remote: hold down its stored button. Release it at the first of the five quick green flashes of R.
- Two-way remote: briefly press and release its stored button. Deletion is confirmed by five quick green flashes of R.
In Mode 1 the entire remote is deleted. In Mode 2 only the transmitted button is deleted; delete any additional buttons separately.
Disabling remote learning
- Disconnect the mains and backup power, then wait 10 s. Hold RADIO and restore the power supply.
- After the stored remotes are signalled, release RADIO exactly after the second short orange flash of R.
- Within 5 s, use short presses of RADIO to select the setting: R off = no restrictions; red = prevent adding a new remote using an already stored remote within range of the operator; green = prevent adding via an authorisation code; orange = both restrictions.
- Within 5 s, press a stored button on an already paired transmitter to save the selected setting.
This setting blocks the selected methods of remote addition. Pairing using the RADIO button on the board is a separate procedure; switching off the built-in radio disables the entire built-in receiver.
Wi-Fi on the SPIDER800W and the MyNice app
Wi-Fi is built into the MCU2; BiDi-WiFi is not required for the basic connection of this kit. The module uses a 2.4 GHz (802.11 b/g/n). The user app MyNice is used for operation, MyNice Pro is for configuration and servicing by technicians. Download the app from your phone's app store.
- After completing the installation and safely testing the gate, switch on the operator and check the W1 power LED.
- In the app, open the option to add a Wi-Fi interface or accessory and follow the setup guide. The phone and operator must have a suitable connection during configuration.
- Select your 2.4 GHz home network and enter its details. Remote control requires a working internet connection and access to the Nice service.
- Test the gate status and operation. A command from the phone can set the gate in motion; safety devices must remain operational.
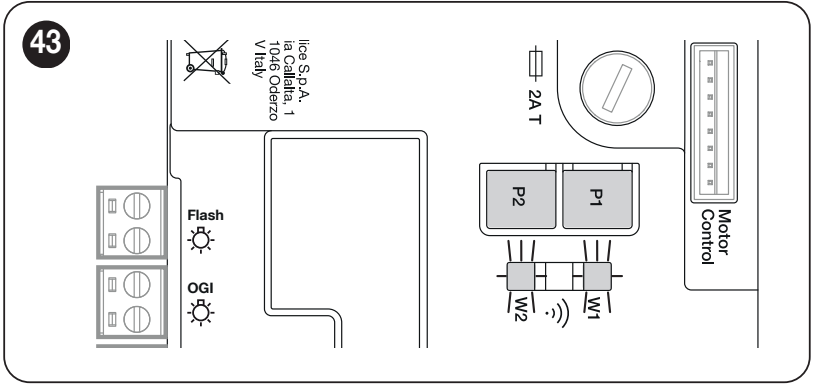
| W2 / W1 | Meaning and procedure |
|---|---|
| Green / green | Normal operation; the phone is connected. |
| Green / 8 rapid green flashes | Temporary device identification requested by the app. |
| Green flashing / green | The module is waiting for network configuration; continue in the app. |
| Orange / green | Normal operation; the phone is not currently connected. |
| Orange flashing / green | Briefly: network setup. If this status persists, check the network and configuration. |
| Off / green | The 30-minute window has expired for the unconfigured module. Disconnect and restore the power supply, then repeat the configuration. |
| Off / orange flashing | Update takes approximately 1 minute; please wait. If it fails, the module will restart after approximately 5 minutes. |
| Red flashing / off | The module reset button was pressed during startup. |
| Red / green | The module did not connect to the home network or the Nice service; check the network, password, and internet access. |
Wi-Fi module reset only
Press and hold P1 for 10 s restores the Wi-Fi module to factory settings; then add it again in the app. P2 is not used in this version. This action is different from the control unit reset and deleting transmitters.
Control unit reset
Resetting clears custom control settings. Press and hold OPEN + CLOSE for approximately 3 s, until L1–L8 light up; release. Successful reset is confirmed by rapid flashing for 3 s. After resetting, repeat device learning, position and test the gate. This procedure does not delete radio codes in either the built-in or external receiver.
Troubleshooting
FLASH indicates errors by the number of short flashes. The sequence repeats after a 1 s pause; count one sequence.
| Indicator | Cause and next step |
|---|---|
| 1 flash | Closing / position The floor was not detected while closing. Set the closed position. |
| 2 flashes | Photocells Remove the obstruction, check alignment and photocell wiring. Activation when an obstruction is present is expected. |
| 3 flashes | Force limit Check manual movement, springs, obstructions, and friction. Do not automatically increase the force; check the mechanics and safety. |
| 4 flashes | STOP Check the STOP safety device and any control unit lockout. |
| 5 flashes | Parameter memory Wait at least 30 s, then try a command. If the error persists, arrange for servicing. |
| 6 flashes | Operation limit Wait a few minutes for the unit to cool down. Check the operating load and gate resistance. |
| 7 flashes | Internal electrical circuit Disconnect all power supplies for a few seconds. If the error persists, have a service technician check the board and motor wiring. |
| 8 flashes | Continuous command Remove the continuously active command, such as a held button or relay; check SbS. |
| 9 flashes | Automation stopped A command to stop the automation was issued; resume operation using the appropriate control command. |
| LED / indication | Meaning and check |
|---|---|
| BlueBUS – 2 green flashes/s | Normal operation. Two rapid green flashes indicate an input change. |
| BlueBUS – rapid and longer red sequences | Bus short circuit: with the power disconnected, check the cables. After the issue is resolved, normal indication resumes after approximately 10 s. |
| STOP off | STOP active; check the safety wiring. |
| PHOTO off | PHOTO relay input triggered. |
| SbS lit | Command present; if the button is not pressed, check the cables and relay. |
| L1 + L2 flashing | Required: device learning. |
| L3 + L4 flashing | Required: position learning. |
| Red light during movement | The set maintenance interval has been exceeded; carry out an inspection. |
| L1 to L8 light up in sequence | Firmware update: please wait; do not disconnect the power supply. |
If a safety device fails, do not operate the automation system in normal mode. Safely disengage the gate. Replace the fuse only with one of the same type and rating; do not repair it by bridging it.
PS124 backup battery
PS124 fits into the designated compartment in the operator and connects to the specified connector, as shown in the installation PDF. Connect it only after completing the mechanical installation, wiring and programming. The battery remains a source of voltage even after the mains supply is disconnected: before working, disconnect the mains supply and the PS124. The number of operations during a power failure depends on the battery condition, temperature and gate resistance.
Disengaging and manual operation
Disengage the operator only when the gate is stationary. If the spring is faulty or the gate is unbalanced, a released gate may drop uncontrollably; secure it and call a technician. If the garage can only be accessed through this gate, arrange in advance for a way to disengage it from outside that is suitable for the specific gate.
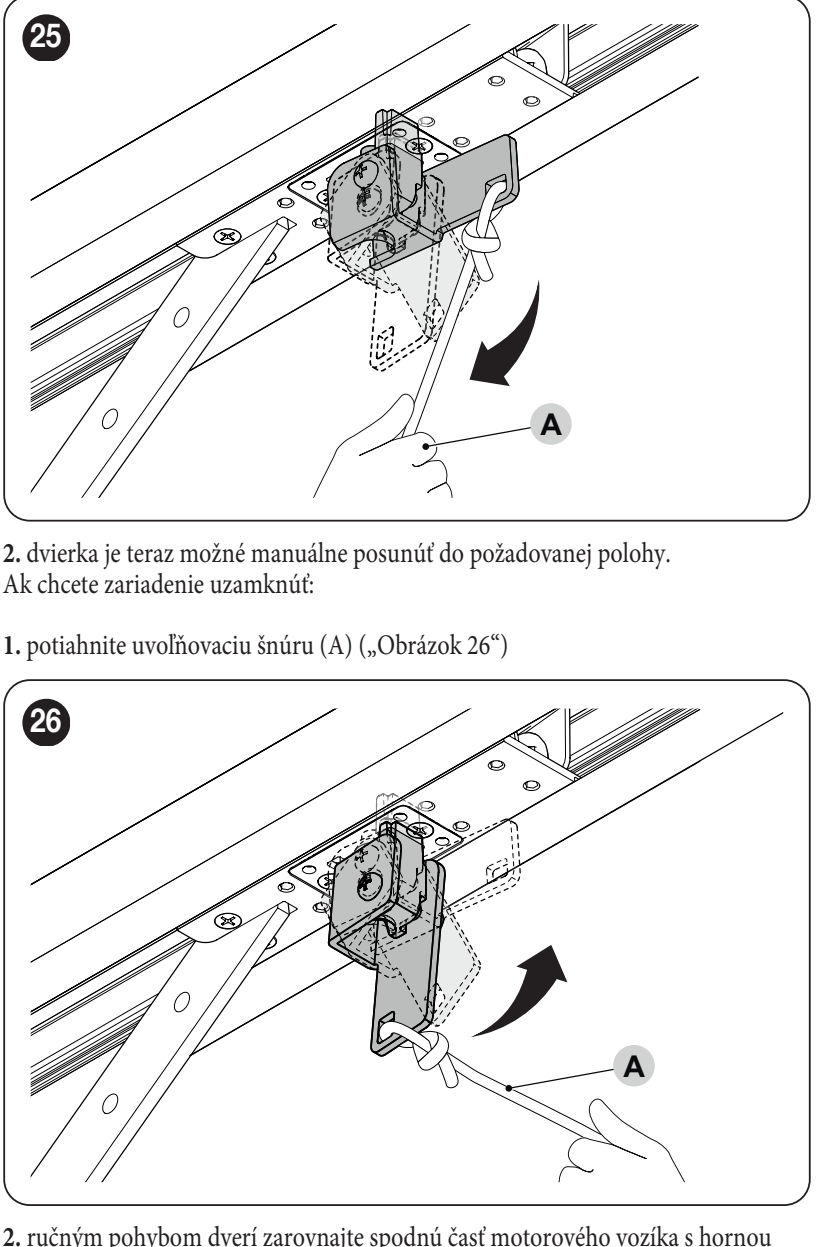
- Pull release cord A. The trolley disengages, allowing you to move the gate safely by hand.
- To re-engage it, pull cord A again as shown in the second illustration.
- Move the gate by hand until the lower and upper parts of the trolley align and engage. Check that the trolley is engaged before issuing an electrical command.
Maintenance and safe operation
Schedule an inspection at least every 6 months or after 3,000 operating cycles, whichever comes first. Disconnect all power sources before maintenance. Check the rail, belt, trolley, brackets, corrosion, springs and gate balance; replace worn parts. After the inspection, repeat the test of the safety devices and forces.
Keep remote controls out of the reach of children. Do not enter the gate area while it is moving. If there is unusual noise, jerking or worsening balance, stop operation and contact service. Dispose of electronics and batteries at an appropriate collection point, not in general waste.
SPIDER800W technical specifications
| Parameter | Value |
|---|---|
| Application | Electromechanical garage door operator for residential use. |
| Control unit | Built-in MCU2, BlueBUS and LEDs L1–L8. |
| Mains power supply | 230 V AC ±10%, 50/60 Hz; protective earth conductor. |
| Maximum / rated force | 800 / 400 N. |
| Rated / maximum power input | 180 / 280 W. |
| Maximum speed | 0.20 m/s; actual operating speed depends on the settings and load. |
| Cycles/day | 50; also observe the other operating limits. |
| Continuous operation | Maximum 4 minutes. |
| Ingress protection / temperature | IP40; −20 to +55 °C. |
| Operator head dimensions | 225 × 395 × 105 mm; see drawing for installation details. |
| Motor weight | 4.9 kg; not the weight of the complete kit. |
| Auxiliary accessories | 24 V DC, tolerance −30% / +50%, total max. 100 mA; polarity and terminals. |
| Backup | PS124 – optional. |
| Lighting | Built-in LEDs. |
How can I order this item?
Choose the option that suits you:
- order online: use the buy button to add the goods to your shopping cart (you will find the buy button here in the product variants table).
- order by email: place your order at [email protected]