Drive kit for sliding gates up to 800 kg CAME BXV08AGS, 801MS-0210 (D)
| Product availability: | within 3 days | We usually ship the goods within 3 days. |
|---|
within 3 days
€793.94 including VAT
| Weight |
|---|
| 12 kg |
Description of Drive kit for sliding gates up to 800 kg CAME BXV08AGS, 801MS-0210 (D)
CAME BXV08AGS drive is designed for sliding gates weighing up to 800 kg and gate leaf lengths up to 20 m. It has an electromechanical stop switch. The drive is non-reversible. Detailed technical specifications ». Download the manual ».
CAME BXV08AGS with ZN7 control board is a sliding gate operator with a 24 V DC motor and mechanical limit switches. The mains supply is 230 V AC. It is designed for a gate leaf weighing up to 800 kg and 20 m long. Consider the gate’s weight, length and resistance together; greater power does not compensate for a gate that is difficult to move by hand.
Installation, mains wiring and commissioning must be carried out by a qualified technician. Disconnect the mains supply and any batteries before carrying out work. Photocells and the encoder do not replace fixed stops, protection of hazardous areas or force testing on the completed gate.
Before installation, check the operator’s rating plate, the ZN7 board, the H1 version and its menu. The technical data and wiring diagrams below apply to the version described. The following settings apply to the version with F28 = 60–100%, F8 = 1/2 and U3 = 0/1. If the board offers different values or connectors, use the manual for that specific version; these three items alone do not identify the complete firmware.
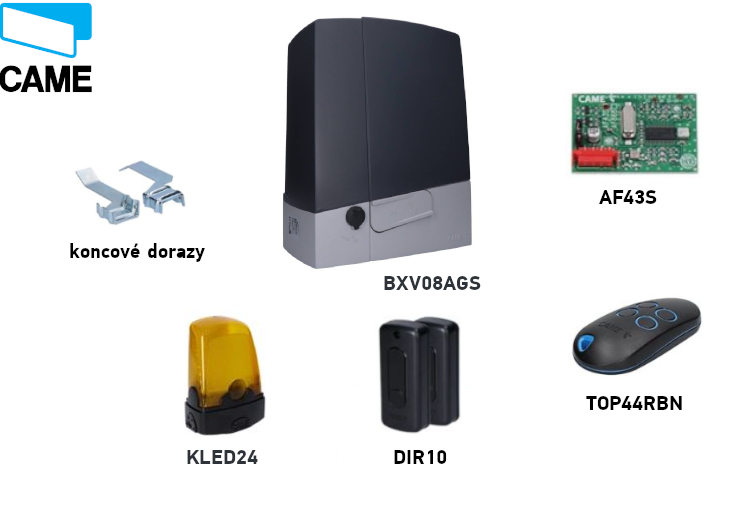
CAME BXV08AGS kit
Both kits include an operator, remote control, photocells, radio receiver and flashing beacon. Before wiring, check the labels on the accessories actually supplied. Select additional components, especially the rack and local controls, to suit the specific gate.
| Feature | CAME BXV08AGS |
|---|---|
| Kit |  CAME BXV08AGS, 801MS-0210 (D) |
| Maximum gate leaf weight | 800 kg |
| Maximum gate leaf length | 20 m |
| Mains / motor | 230 V AC / 24 V DC |
| Power / force | 400 W / 800 N |
| Maximum speed | 11 m/min |
| Motor selection A1 | 3–800 kg |
| Control board covered in this guide | ZN7, display and menu |
The 18 or 20 m figure indicates the maximum gate leaf length, not necessarily the clear opening width. A1 selection does not change the physical operator’s load capacity.
Accessories and wiring examples
The following examples are for specifically identified devices. For a different type, use its own terminals and parameters; the same function or frequency alone does not confirm compatibility.
| Component | Verified example / use |
|---|---|
| Photocells | CAME DIR10, 12/24 V AC/DC, 10 m range; wiring and TS test. |
| Flashing beacon | CAME KLED24, 24 V AC/DC, 2 W; output 10–E. |
| Radio receiver | CAME AF43S, AF plug-in card, 433.92 MHz; verify coding together with U4. |
| Remote control | CAME TOP-432EE, fixed code, 433.92 MHz; example for a compatible receiver. |
| Rack | Racks, module 4; clearance and fixing. |
| Local controls | Switches, push buttons and readers; NO commands and NC safety contacts according to the terminal layout. |
Operator installation
With the operator released, the gate must move smoothly along its entire travel, without sloping, damaged wheels or any risk of coming off the guide. Check that fixed mechanical stops are fitted in both the open and closed positions, that the base is stable, and that areas where the gate leaf could trap someone are protected. Water must not collect in the operator area or be directed at it as a jet. If the sliding gate leaf has a built-in pedestrian gate, powered movement must only be possible when it is securely closed.
Foundation and anchor plate
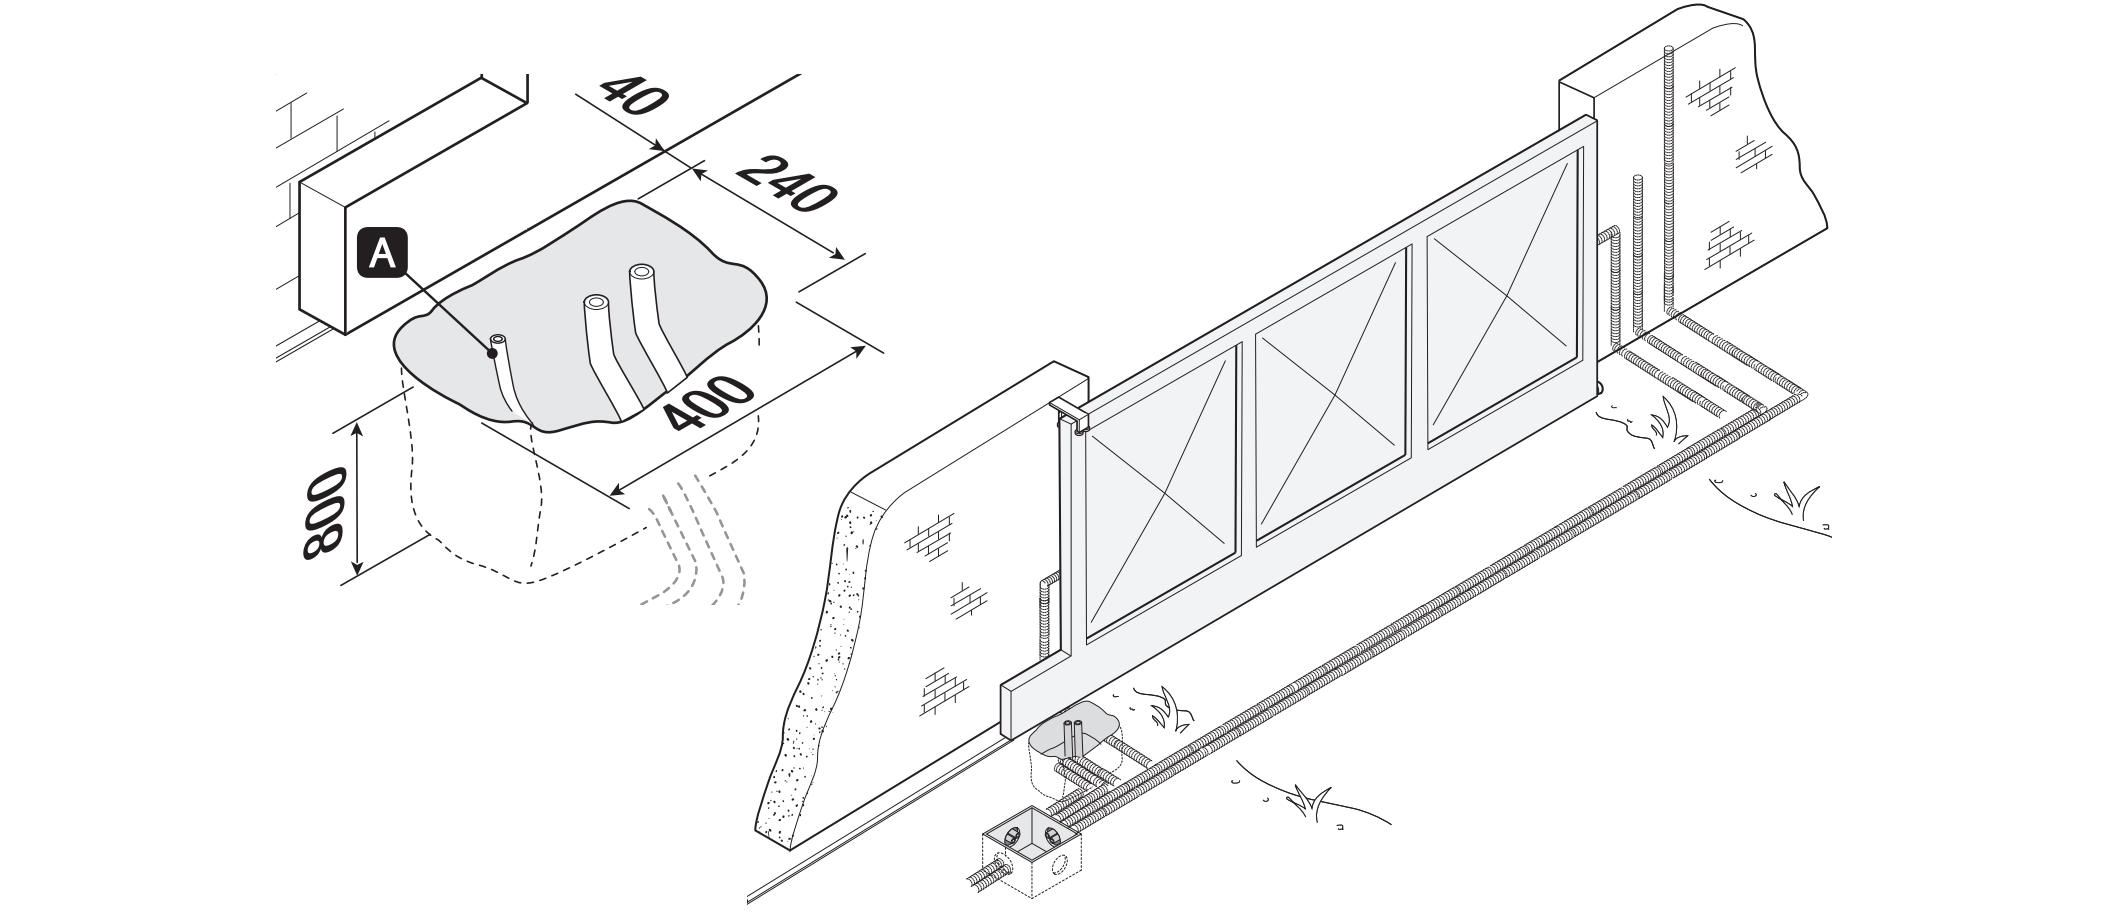
The installation example uses an excavation 400 × 240 mm and 800 mm deep. Adapt the foundation dimensions to the ground conditions and the specific gate. The formwork extends 50 mm above ground level; use reinforcement and M12 anchors. A Ø 40 mm conduit is recommended for the operator supply cable, Ø 25 mm for accessories and Ø 20 mm for any manual release cable.
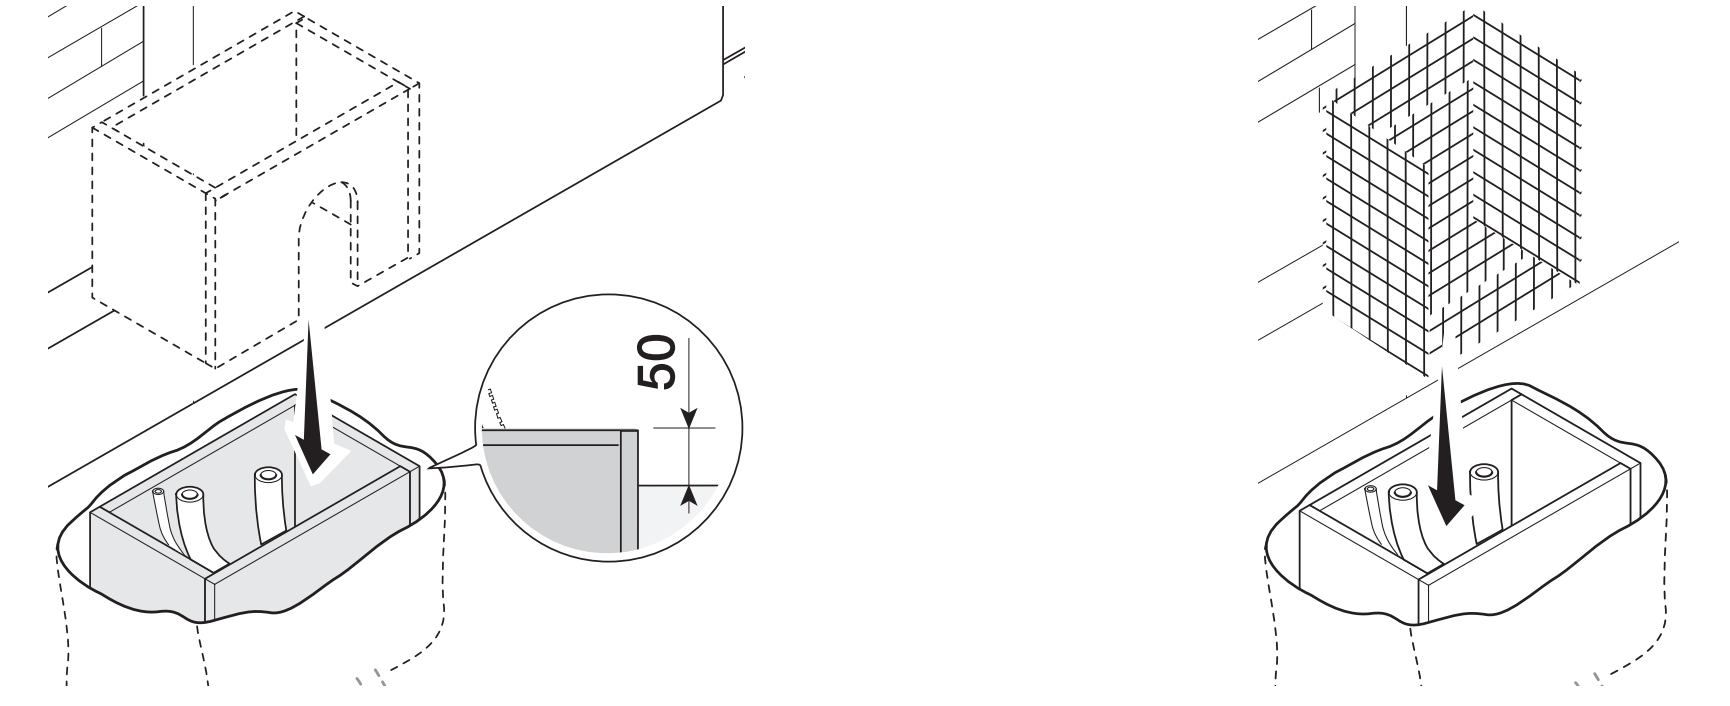
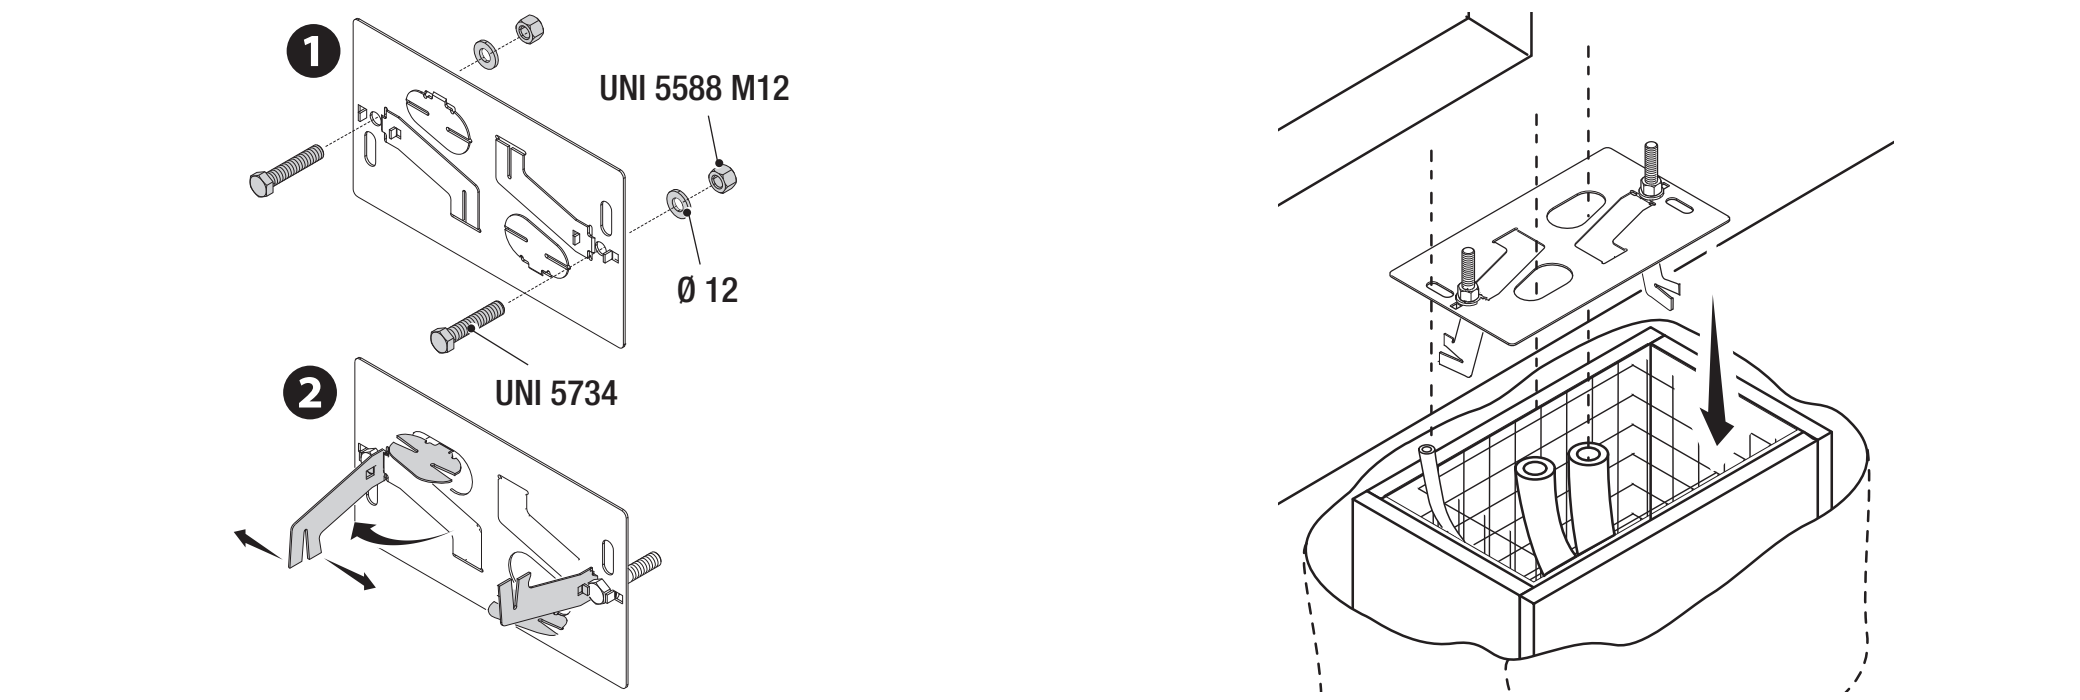
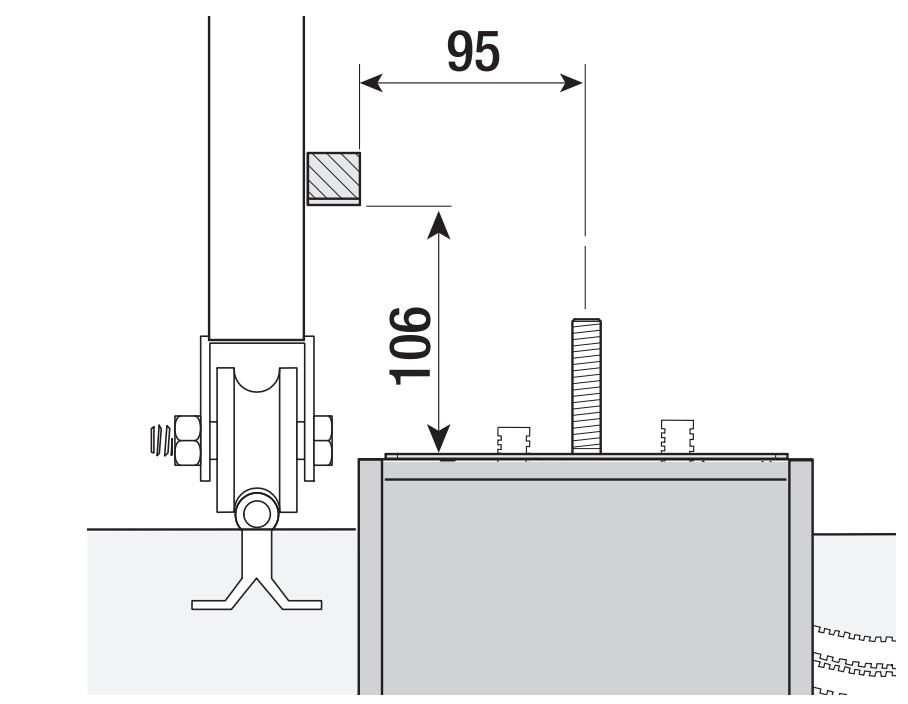
Set the anchor plate level, route the cables through its openings and leave the threaded parts of the anchors protruding above the surface. Allow the concrete to cure for at least 24 hours. Position the plate relative to the rack as shown in the diagram: the 95 mm horizontal offset and 106 mm height apply to the marked surfaces in the cross-section. Do not confuse these with the foundation dimensions.
Installing and adjusting the height
Remove the cover and place the operator on the plate. The cables must pass through the bottom of the housing and through correctly fitted cable glands. While adjusting, raise the operator using the threaded feet by 5–10 mm, leaving room to adjust the mesh.
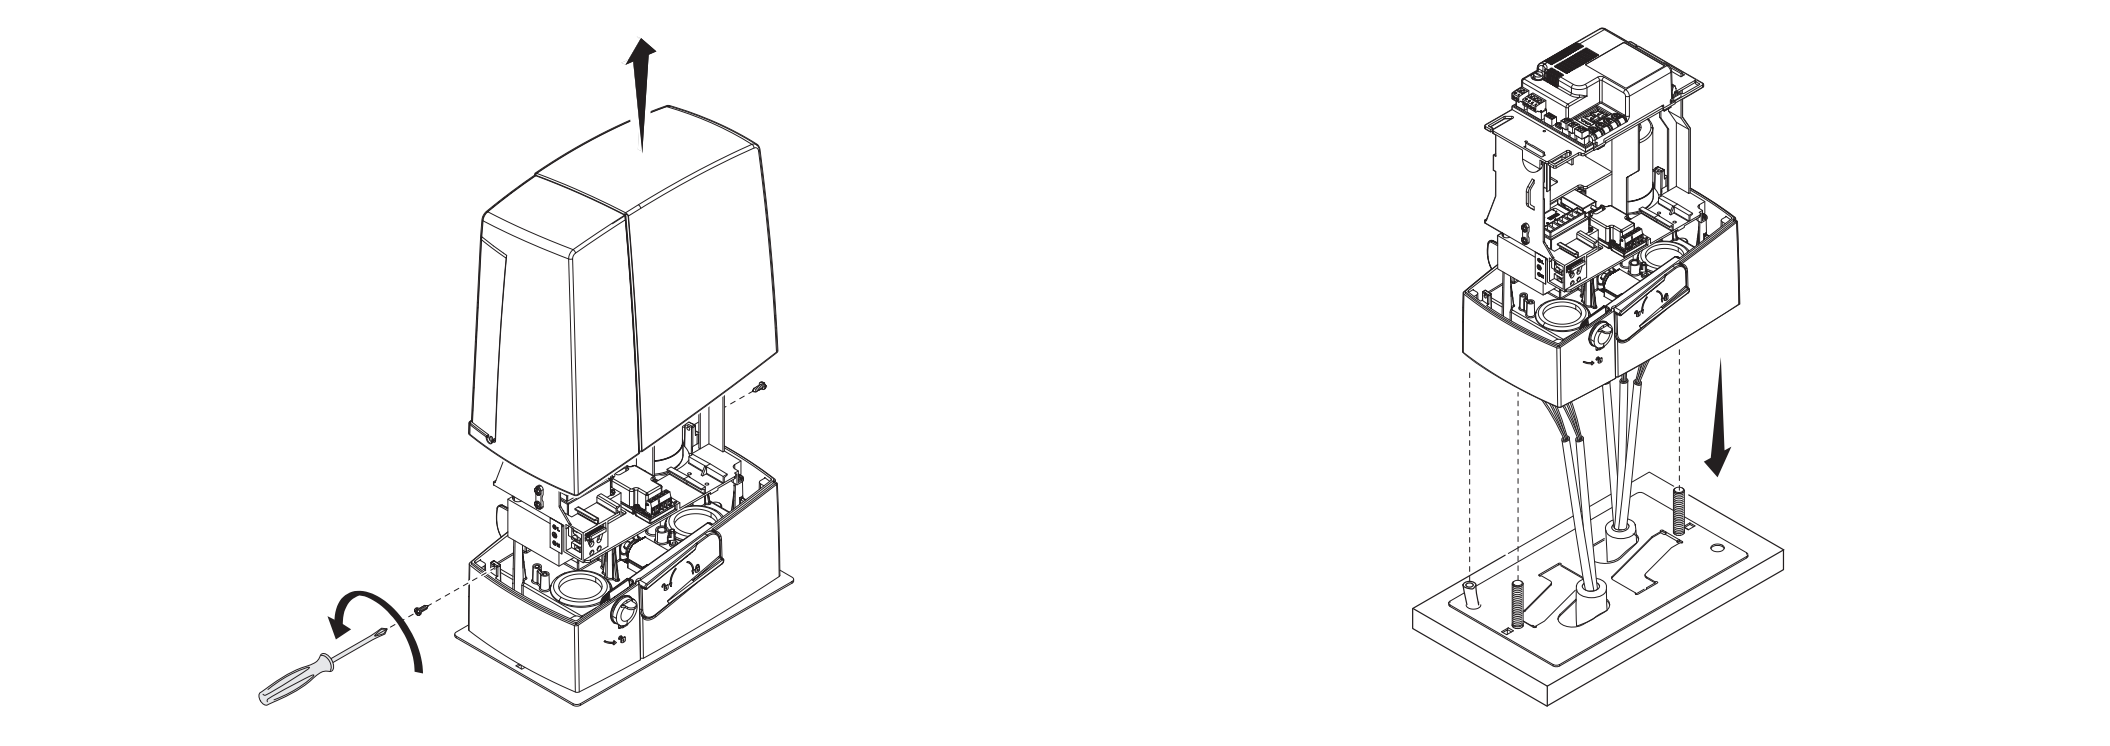
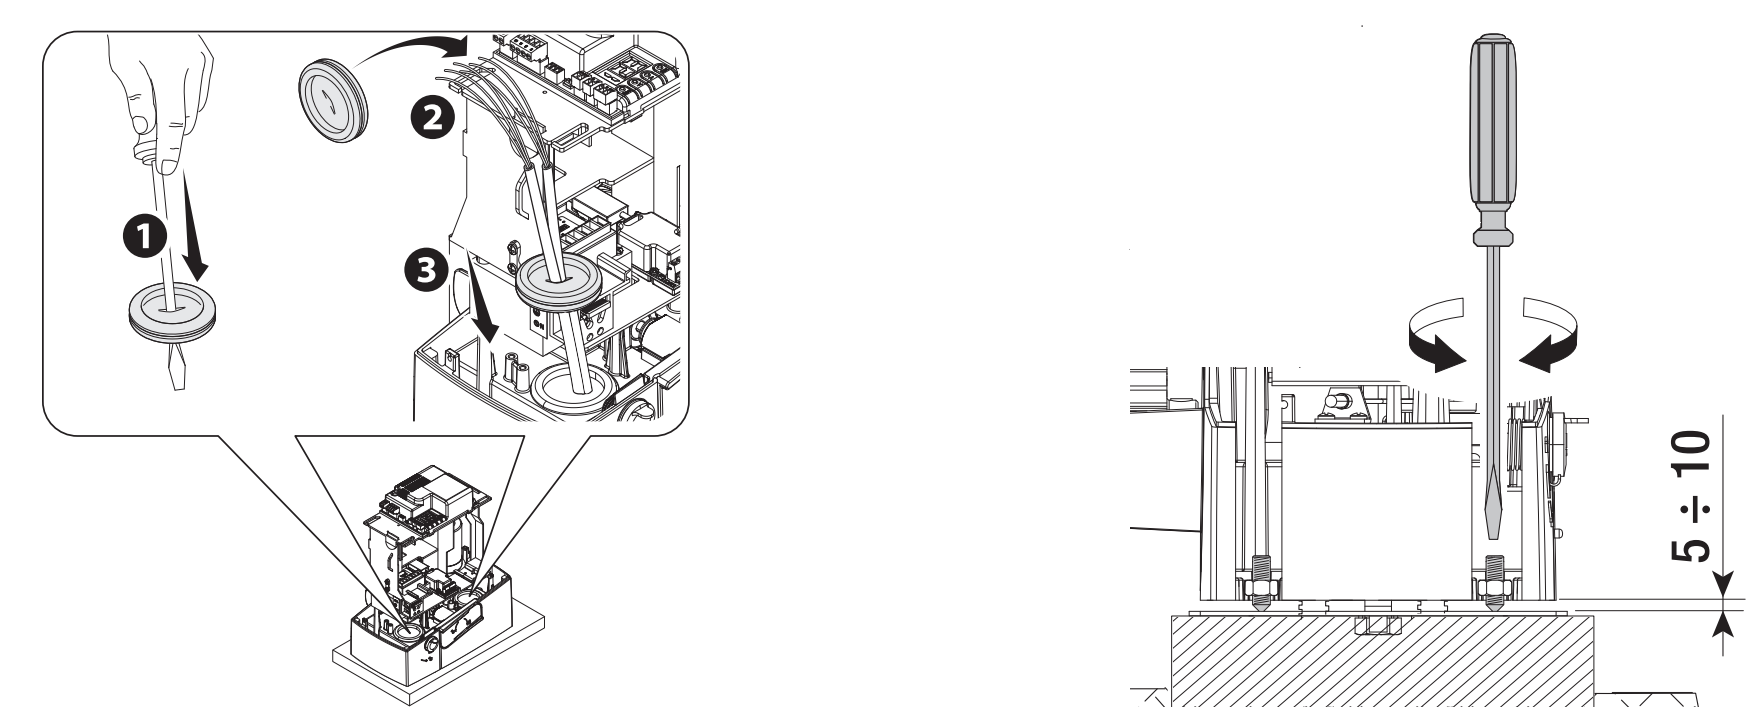
Rack and mesh clearance
Release the operator and fit the rack while moving the gate leaf by hand. When joining rack sections, use an offcut of rack beneath the joint so that the teeth align smoothly. After installation, adjust the operator’s vertical and horizontal position.
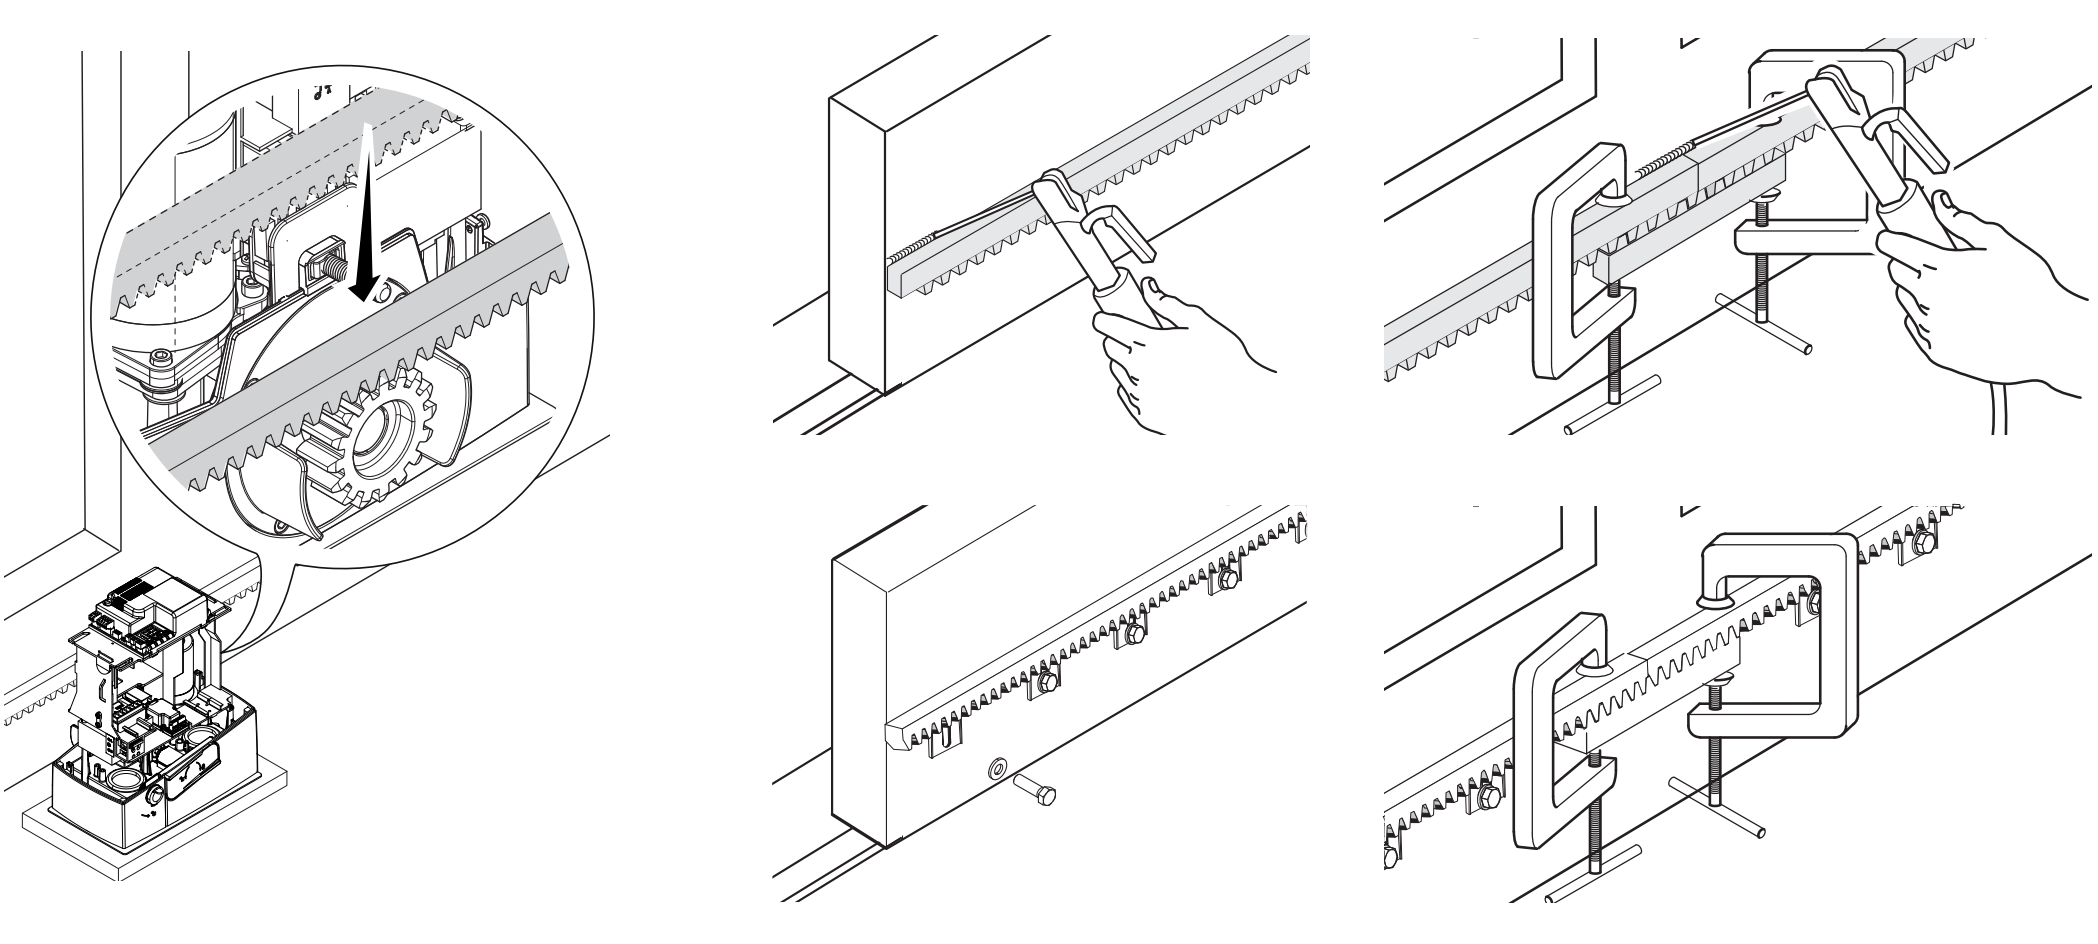
Leave a 1–2 mm clearance between the rack and pinion. The gate must not rest on the operator. Move the gate through its full travel by hand, check the meshing and rack joints, and only then tighten the nuts and washers on the anchors.
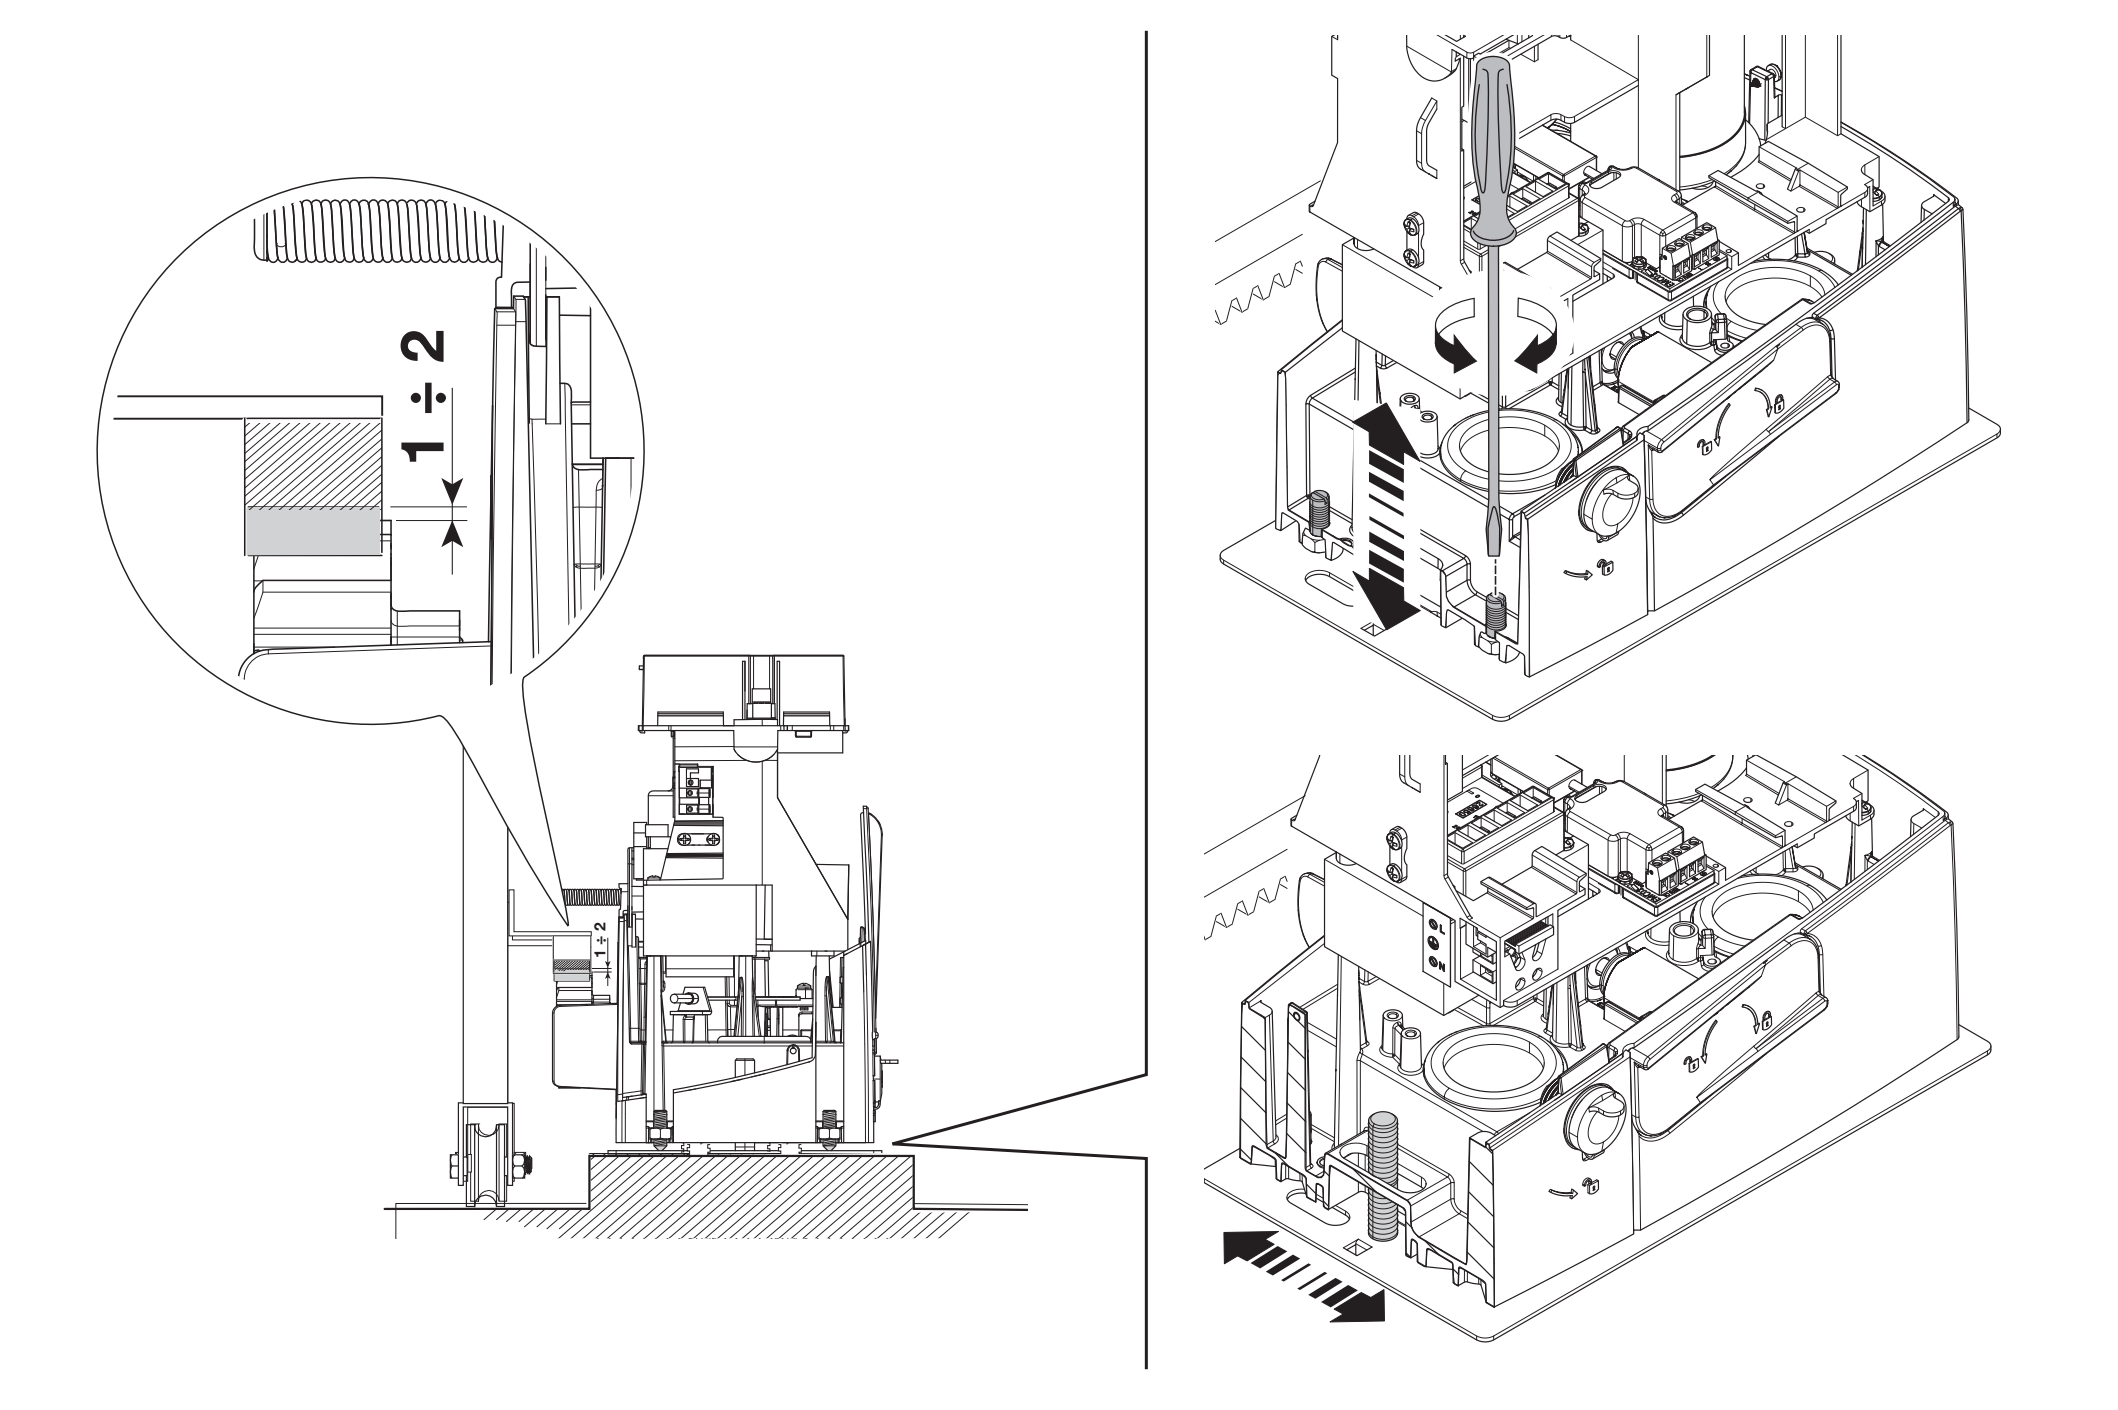
Mechanical limit switches
Move the gate leaf to the open position by hand. Secure the opening limit switch stop to the rack so that its ramp reliably actuates the spring-loaded microswitch. Set the closing stop in the same way. Secure the stops firmly; the gate’s mechanical end stop and the operator’s limit switch stop serve different purposes.
In the configuration shown, leave approximately 20 mm before the mechanical end stop. Check the run-on at the actual speed and under load.
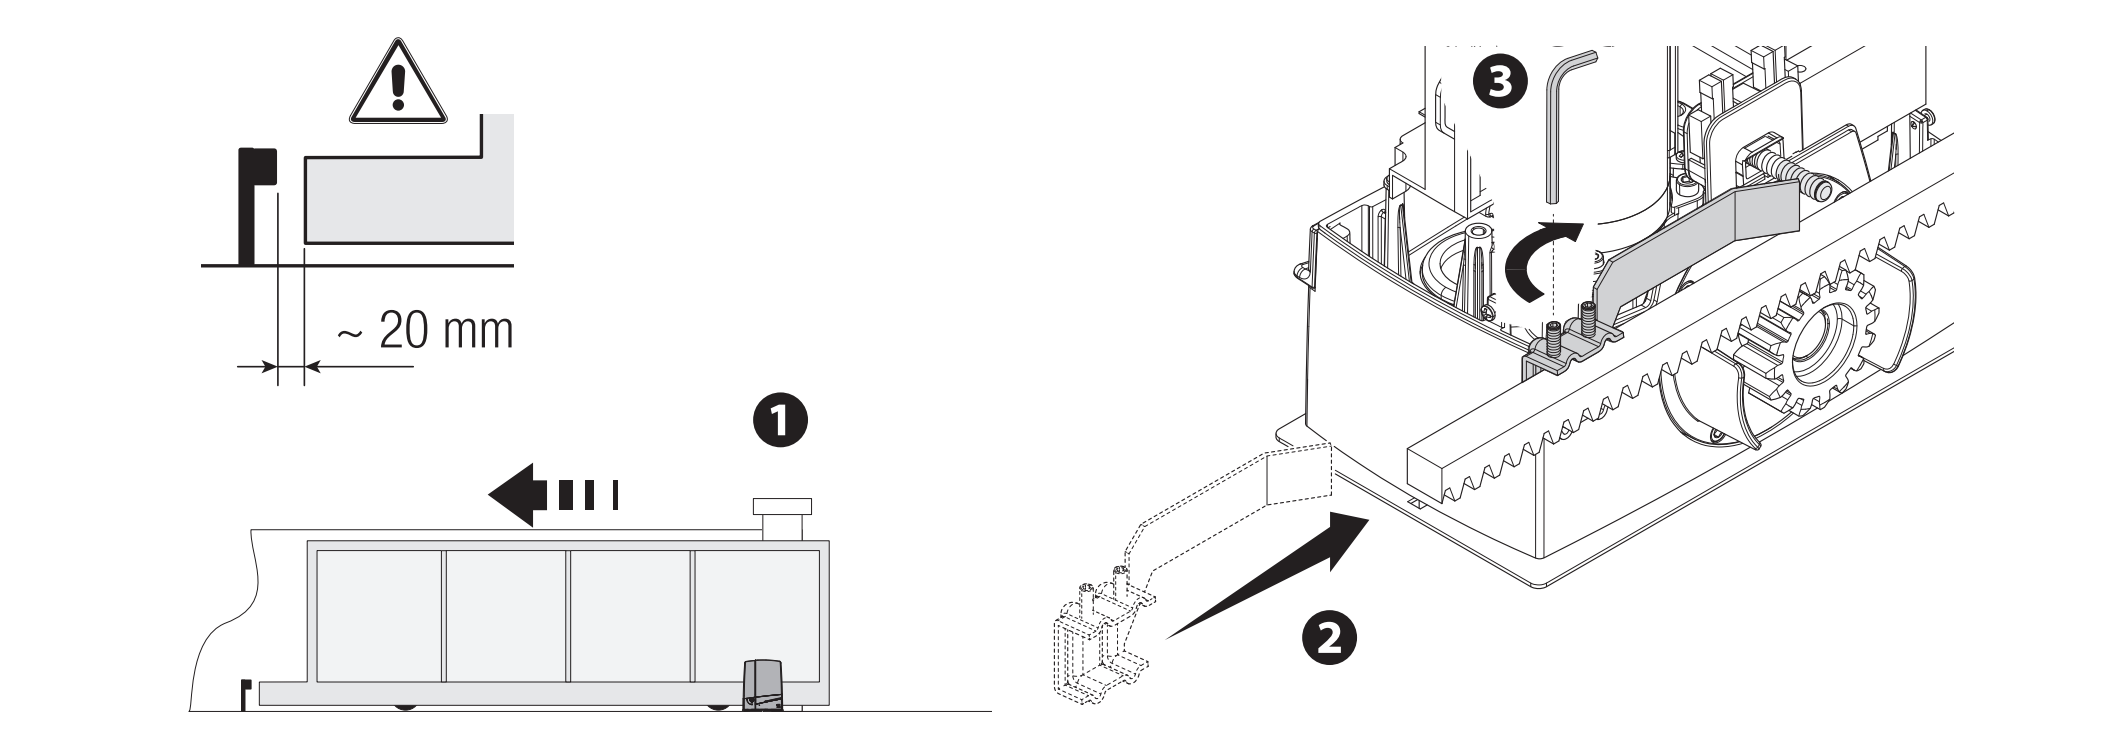
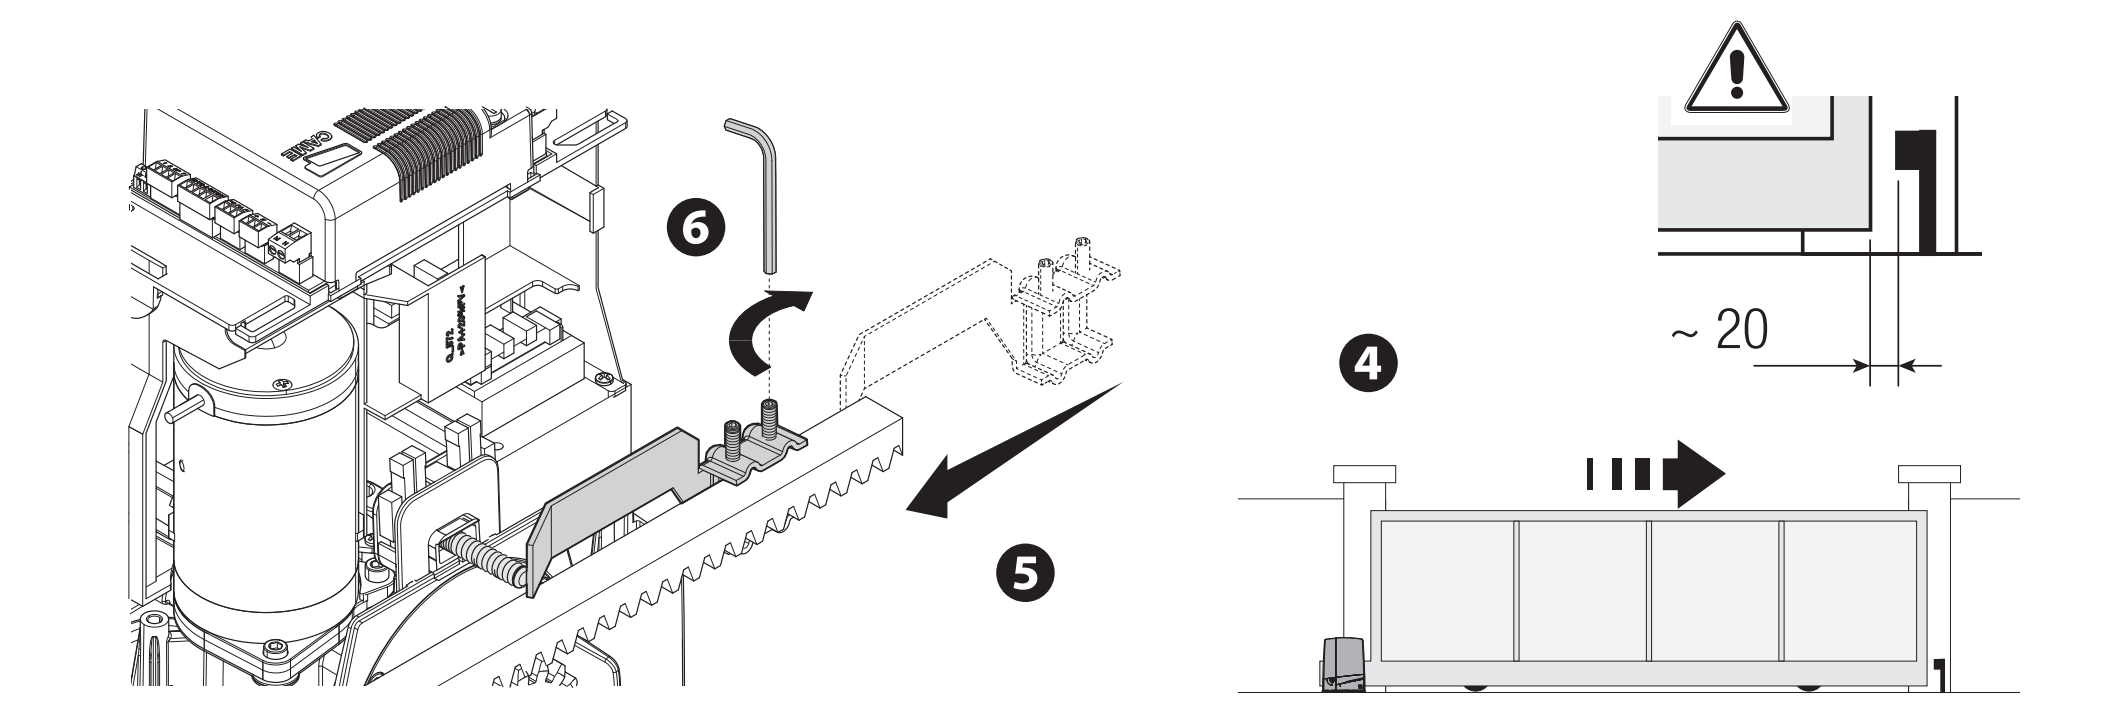
Wiring
| Connection | Cable / requirement |
|---|---|
| 230 V AC mains, L/N/PE | 3G × 1.5 mm² up to 20 m; 3G × 2.5 mm² for 20–30 m. |
| Control devices | Number of conductors depends on the control setup; 0.5 mm² cross-section for the short runs listed. |
| DIR10 photocells | TX: 2 × 0.5 mm²; RX: 4 × 0.5 mm². Ensure the TX connection and NC contact are wired correctly. |
| Antenna | RG58, maximum 10 m; 5 m or less recommended. |
| RSE / CRP | UTP CAT 5; separate serial connection, not motor power supply. |
The number of conductors must accommodate the entire selected wiring diagram. For longer runs, simultaneous loads or other accessories, a technician must recalculate the conductor cross-section based on current and voltage drop. Protect cables from damage and contact with the motor or transformer; route the mains supply and low-voltage circuits suitably separated from one another.
Manual release in the event of a power failure
Disconnect the power supply and secure the gate leaf before moving it manually. Releasing a damaged or unbalanced gate may cause uncontrolled movement.
- Insert the key into the lock and turn it in the direction of the arrow shown in the illustration.
- Pull and open the release lever as shown in the illustration.
- Move the gate manually in a controlled manner, with no one in its path.
- To re-engage the mechanism, return the lever to its original position and lock the mechanism. Before operating the motor, check that the operator is engaged.
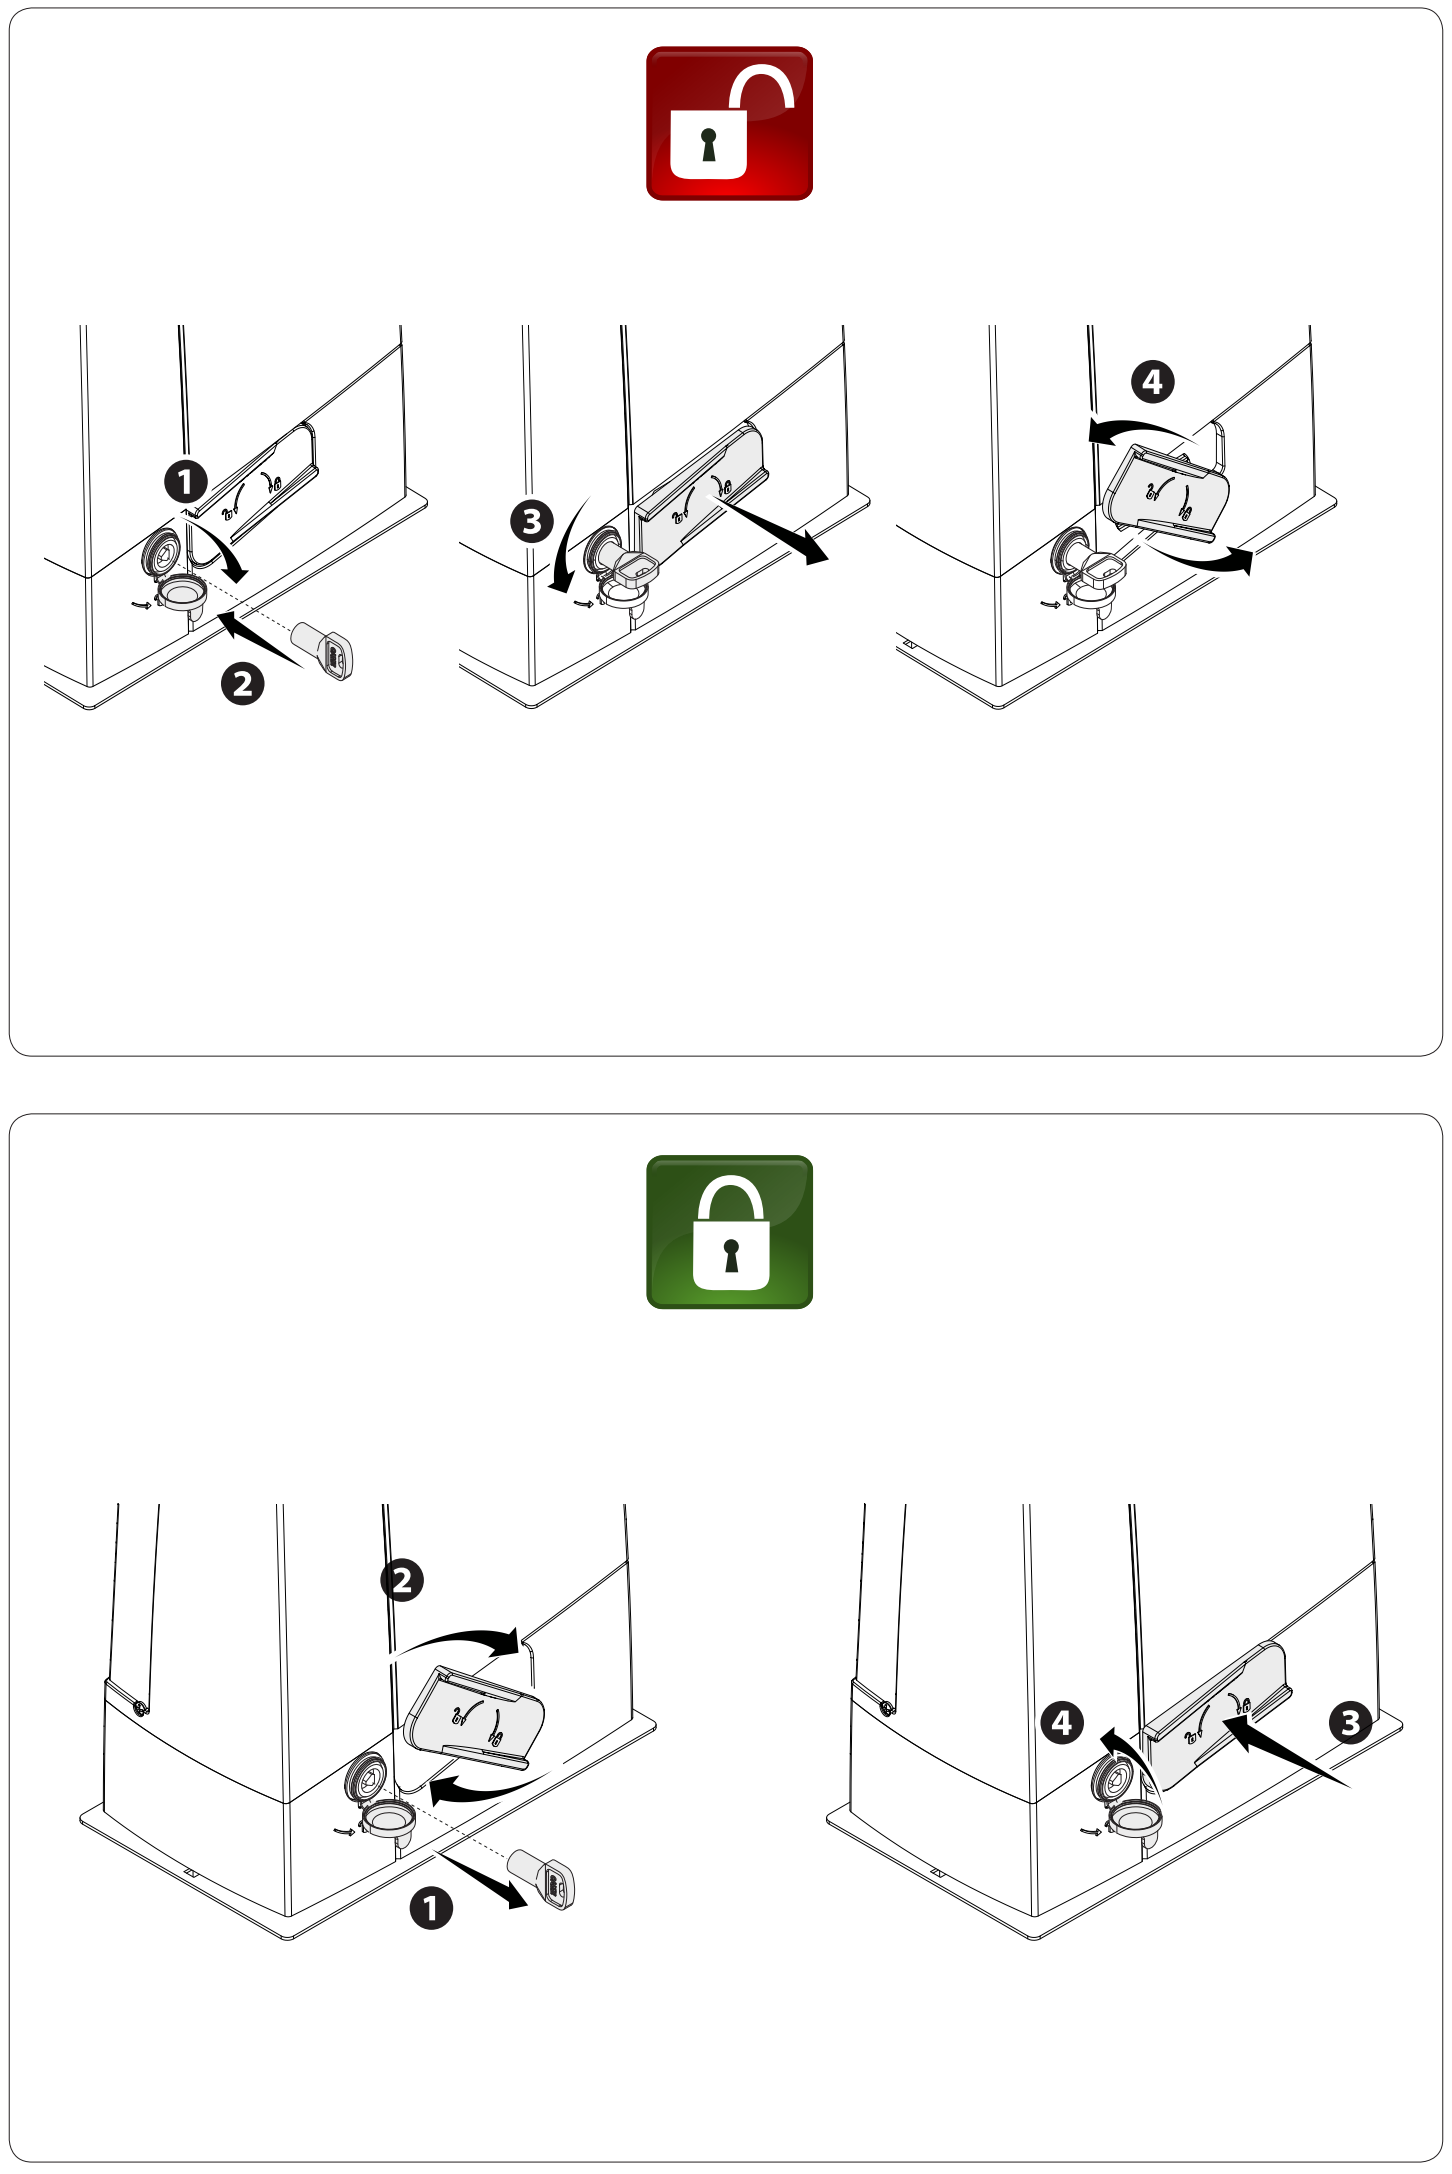
ZN7 control board overview
The ZN7 has a display and ESC, arrow and ENTER buttons. Settings, times and users are managed through the menu. The AF, Memory Roll, R700/R800, RSE and RIOCN8WS connectors have separate functions; insert or remove the card only when both the mains supply and batteries are disconnected.
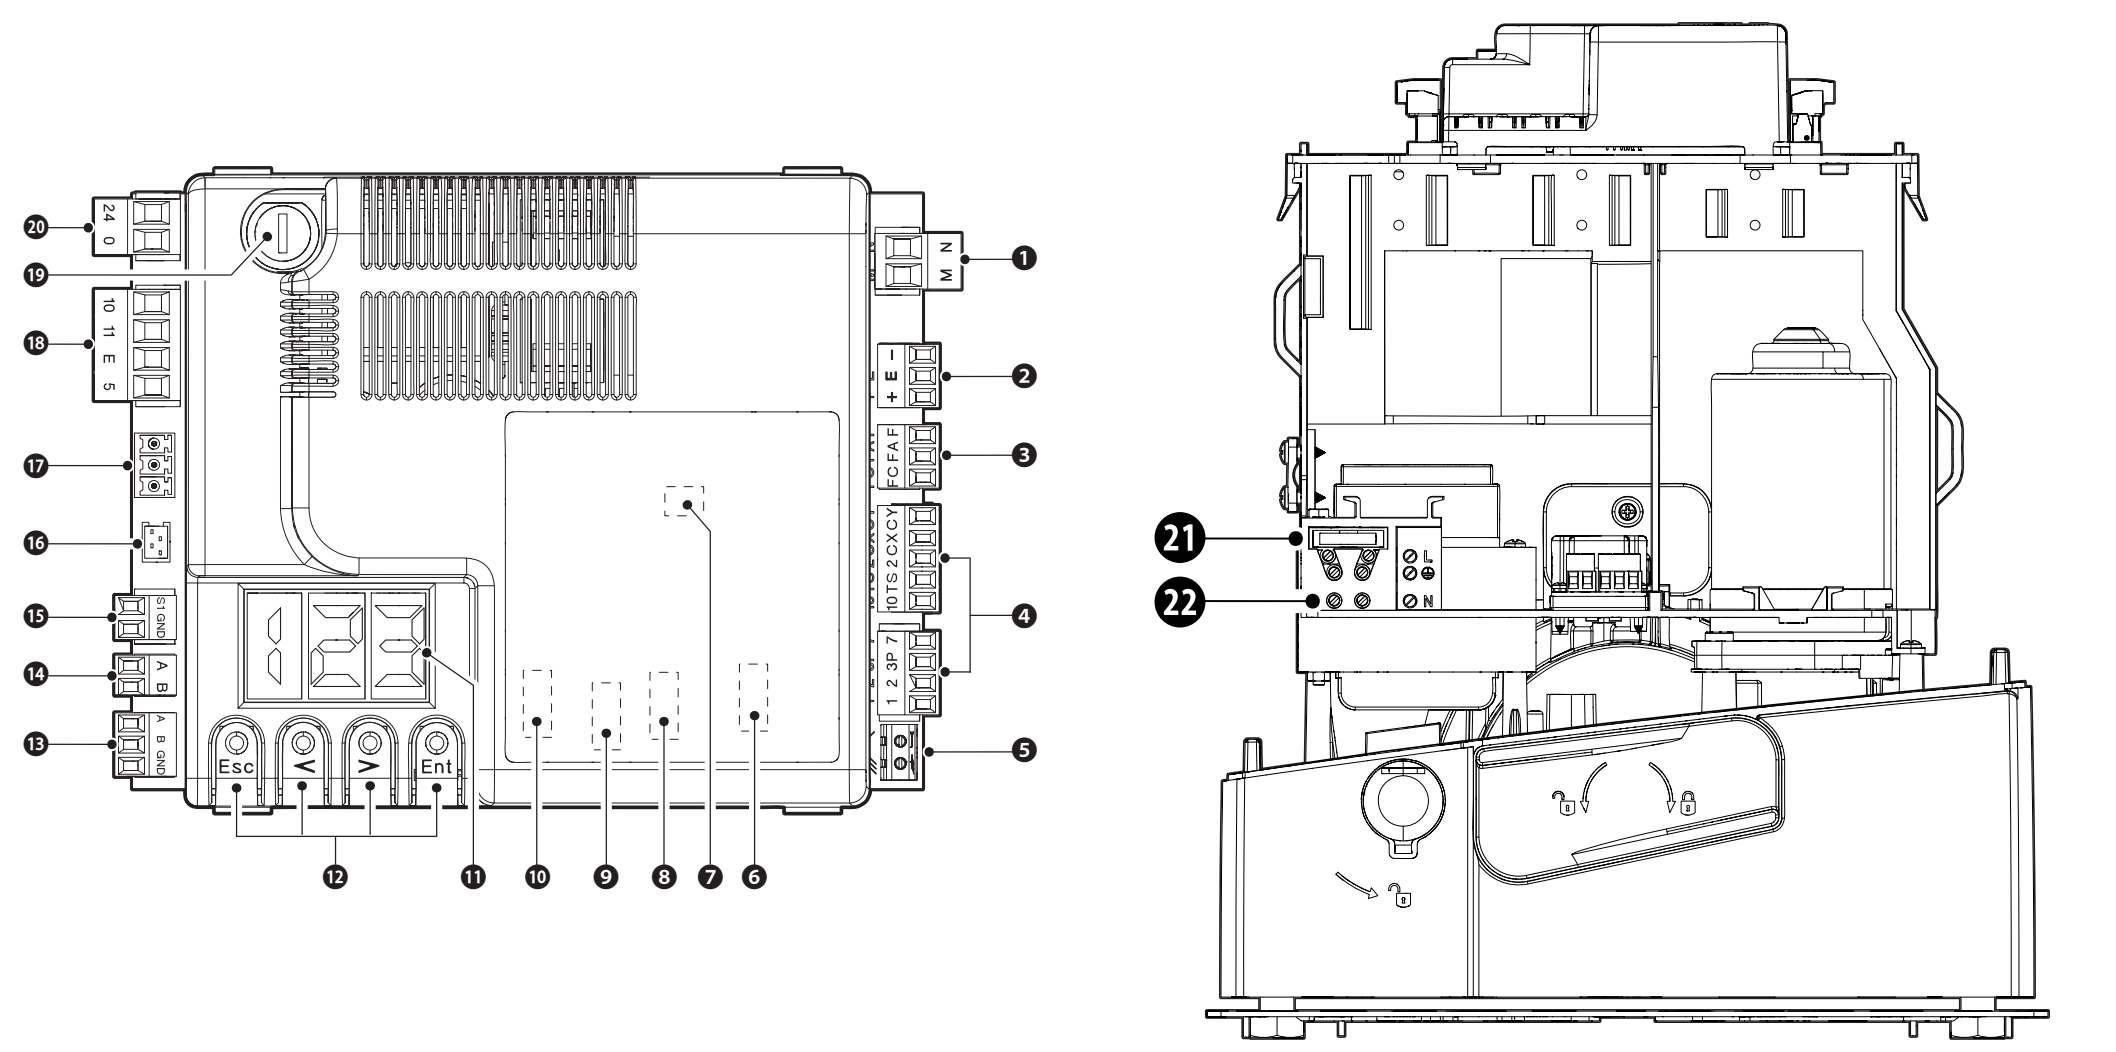
| Figure number | Component |
|---|---|
| 1 / 2 / 3 | Motor / encoder / limit switches |
| 4 / 5 / 6 | Commands and safety / antenna / AF |
| 7 / 8 / 9 / 10 | Memory Roll / R700 or R800 / RSE / RIOCN8WS |
| 11 / 12 | Display / programming buttons |
| 13 / 14 / 15 | A–B–GND serial connection / A–B keypad / S1–GND transponder |
| 16 / 17 / 18 | GSM module / RGP1 / accessories and lights |
| 19 / 20 / 21 / 22 | Accessory fuse / board input / mains fuse / mains supply |
ZN7 terminals and power supply
| Terminals | Use / voltage / polarity |
|---|---|
| L / N / PE | 230 V AC mains, 50/60 Hz for BXV08AGS. PE is the protective conductor; AC has no +/− polarity. |
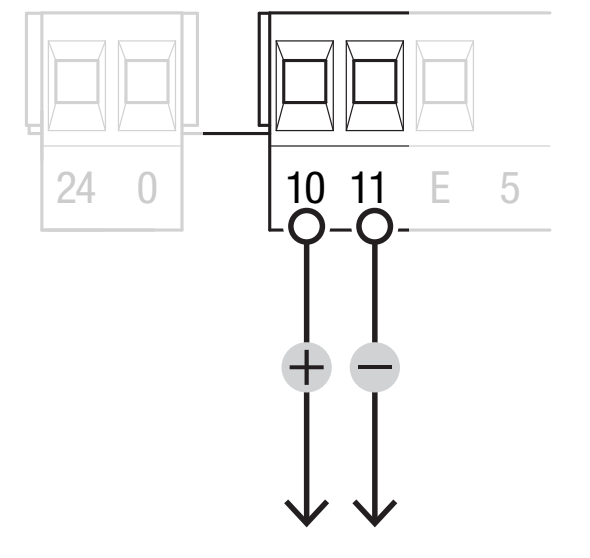
| 10 / 11 | Accessories: normally 24 V AC, in battery operation 24 V DC, total load no more than 40 W. For DC 10 = positive (+), 11 = negative (−); no polarity for AC. |
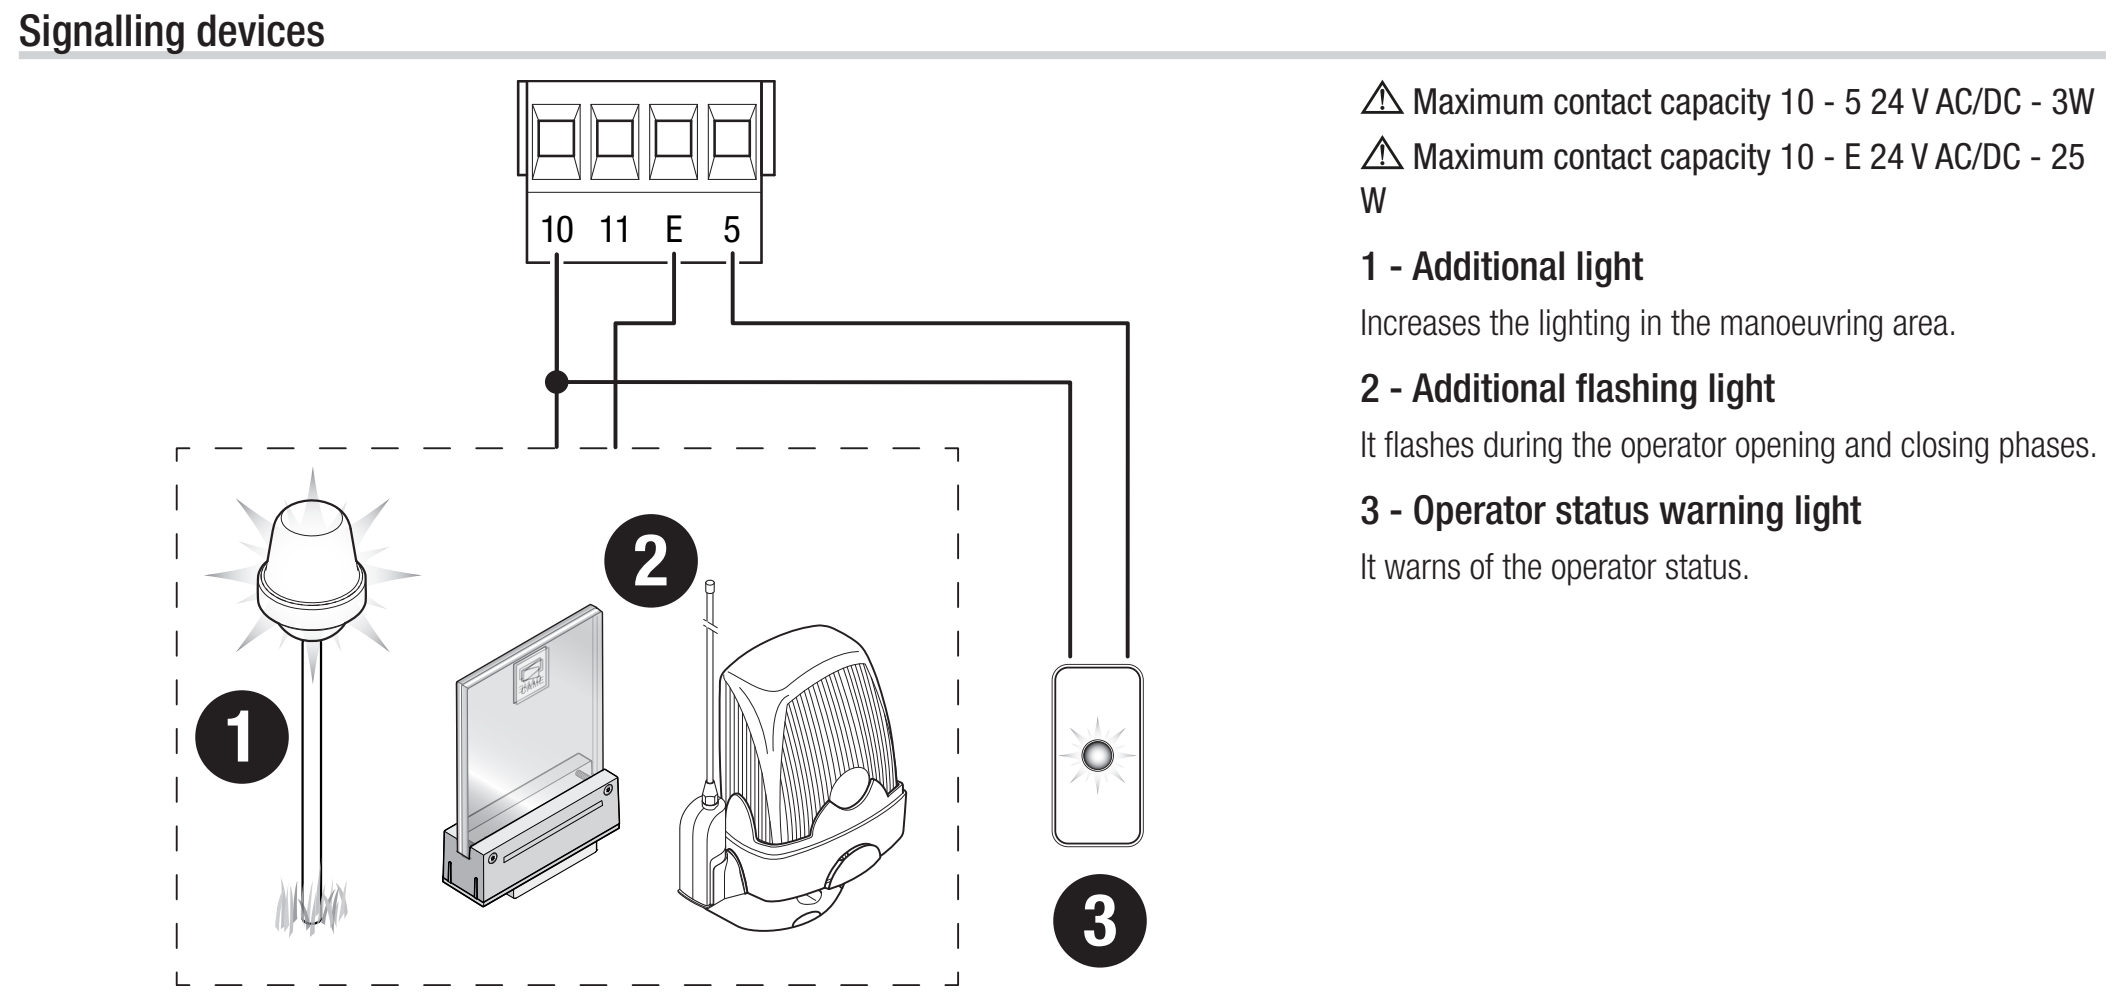
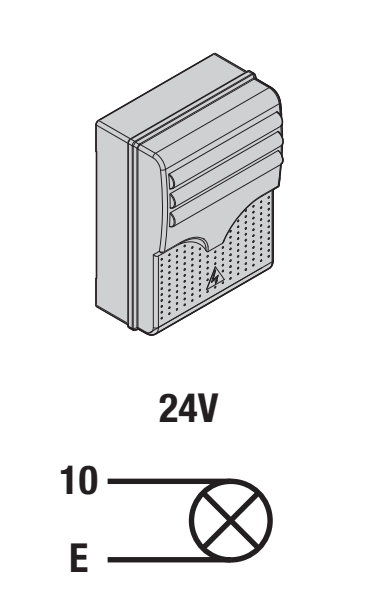
| 10 / E | Flashing or courtesy light, 24 V AC/DC, max. 25 W. For DC, 10 is the positive common terminal and E is the switched output. |
| 10 / 5 | Gate status indicator, 24 V AC/DC, max. 3 W. For DC, 10 is the positive common terminal and 5 is the switched output; not for continuous power supply. |
| 24 / 0 | Internal board supply from the power section; do not use as an accessory output or as an external battery input. |
| M / N | 24 V DC motor; retain the wiring for the correct configuration. Not a 230 V supply. |
| + / E / − | Encoder: +/− power supply and E signal; not a general-purpose accessory output. |
| F / FA, F / FC | F common, FA opening, FC closing; NC limit contacts, no polarity. |
| A / B / GND – RSE | Serial interface with the RSE card; do not confuse with the keypad A/B terminals. |
Commands and safety contacts
| Terminals | Contact / function |
|---|---|
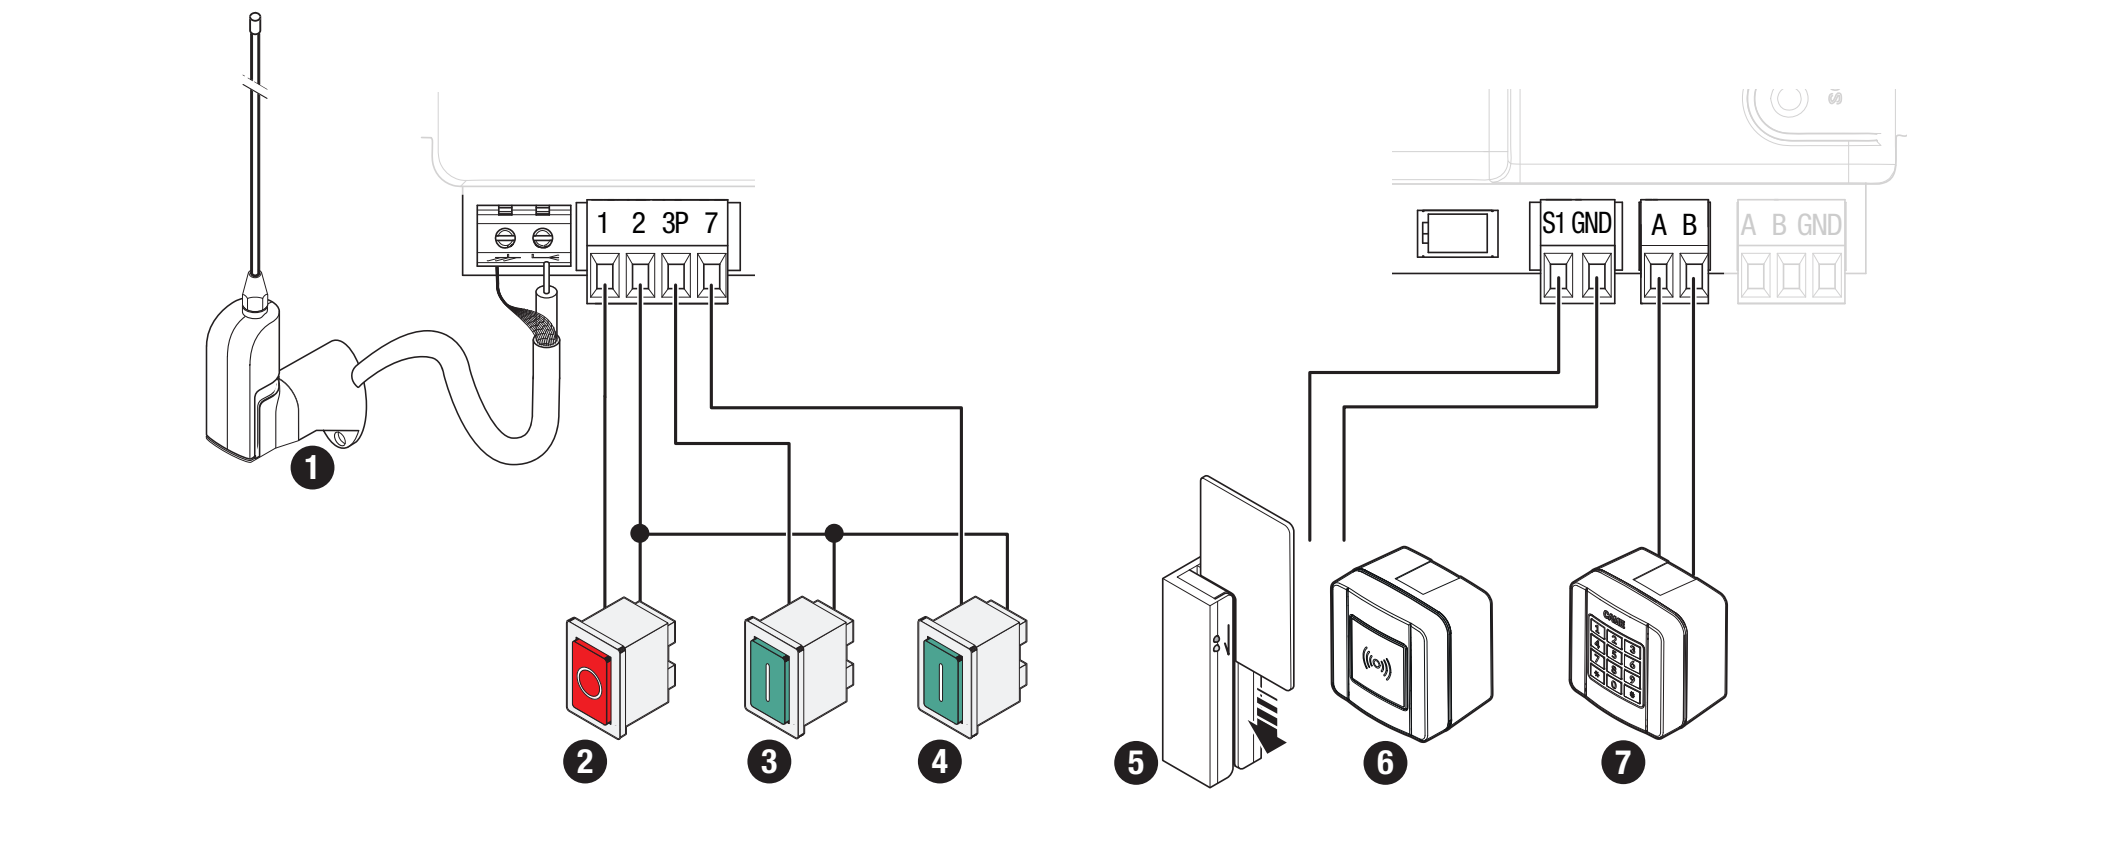
| 1–2 | NC STOP; set F1 = ON if connected. Factory setting: F1 = OFF. No polarity. |
| 2–7 | NO command; function selected by F7. Voltage-free contact, no polarity. |
| 2–3P | NO partial or full opening, depending on F8. Voltage-free contact, no polarity. |
| 2–CX / 2–CY | NC safety inputs; configure F2/F3. No polarity. |
| 10 / TS | Tested photocell power branch according to the diagram; do not activate F5 unless wired correctly. |
| A–B / R800 | Code keypad with R800 decoding card, F14 = 1. |
| S1–GND / R700 | Transponder or reader with R700, F14 = 0. |
| Antenna / AF | RG58 and plug-in radio card of the correct frequency/coding. |
Flashing light and status indicator
KLED24, 24 V AC/DC and 2 W, connect to 10–E; for the flashing light, set F18 = 0. KLED24 does not have a separately marked +/− supply. With AC there is no DC polarity; with DC, terminal 10 is the board's positive common terminal. Do not connect a 230 V flashing light to this 24 V output.
Output 10–5 is for a small status indicator, max. 3 W, with setting F10. Cycle-light mode F18 = 1 requires an automatic closing time; the light remains on from opening until fully closed, including during the waiting period.
Photocells and safety test
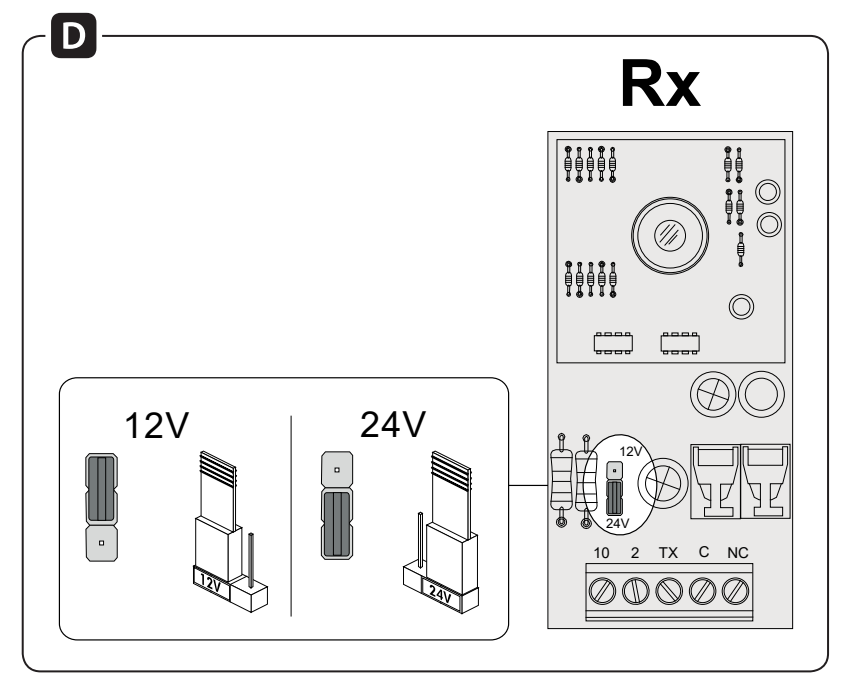
CAME DIR10 consists of a TX transmitter and RX receiver with a 10 m range. Set the receiver jumper to 24 V. The pair draws 60 mA at 24 V AC. The RX power terminals are marked 10 (+), 2 (−); the TX terminals are TX and 2; the manufacturer does not show separate +/− markings for these in this diagram. With AC power, DC polarity does not apply. The TX terminal is part of the synchronisation circuit; connect RX TX to TX TX as shown in the diagram and do not replace this connection with a direct feed from board terminal 10.
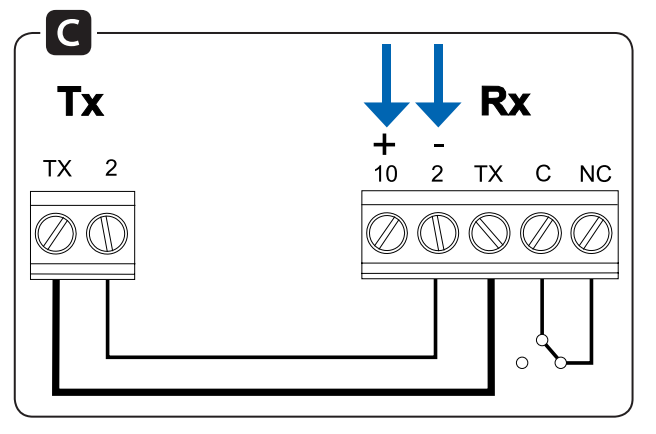
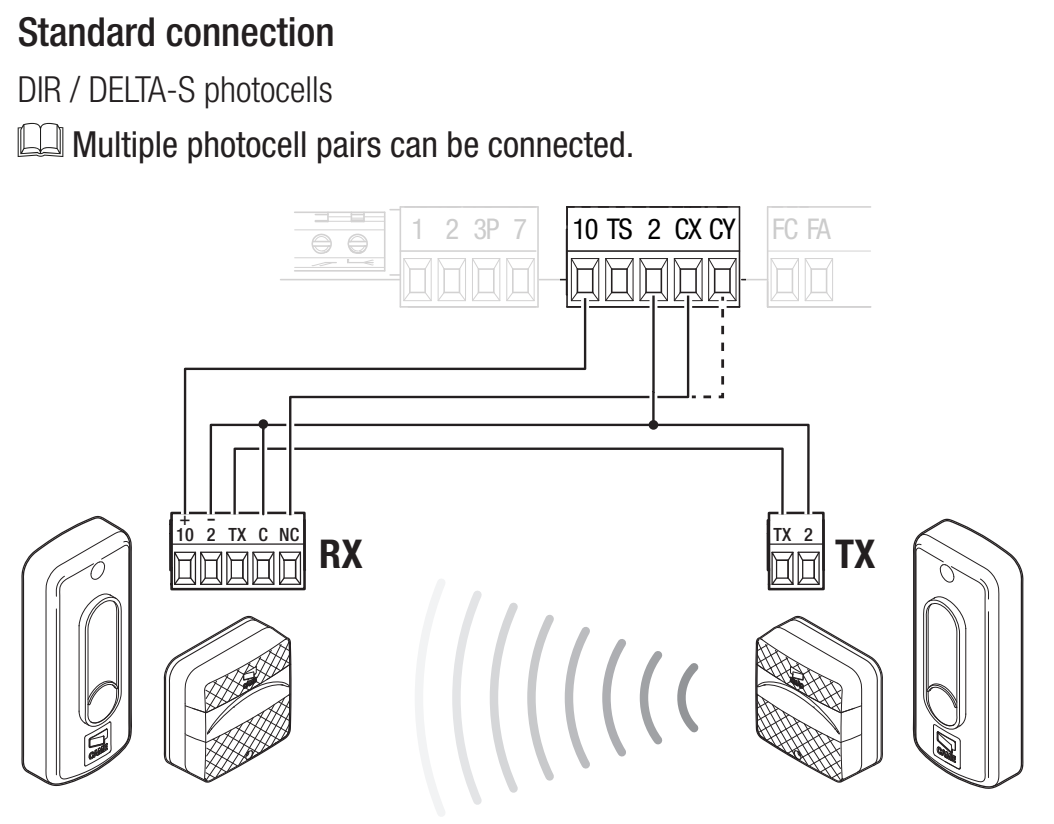
| Photocell terminal | Standard wiring | Wiring with test |
|---|---|---|
| RX 10 (+) | Board 10 | Board 10 |
| RX 2 (−) and RX C | Board 2 | Board 2 |
| RX TX ↔ TX TX | Connect TX between the receiver and transmitter | Same connection |
| TX 2 | Board 2 | Board TS |
| RX NC | Board CX | Board CX |
The C–NC contact is a volt-free safety contact. It has no positive or negative terminal. The power supply wiring and contact wiring are two separate circuits. With DC, terminal 10 is positive; the RX 2 negative terminal is connected to the board's common terminal 2 in this specific diagram. Do not confuse terminal 2 with power supply terminal 11.
For a contact on CX, set F2 = C1. For a contact on CY, select the corresponding response using F3. C1 reopens during closing; C2 closes again during opening; C3 stops and then closes automatically, and requires F19; C4 waits for the obstruction to be removed and then resumes movement.
Wiring the test via TS
For the test, TX 2 is moved to TS, while RX 2 and RX C remain connected to board terminal 2. The TX connection between the transmitter and receiver remains in place. First change the wiring with the power off, and only then enable the test.
Set F5 = 1 for CX, 2 for CY, or 4 for both CX and CY. If the test fails, E4 is displayed and the operator will not execute the command. This function is used together with active safety inputs.
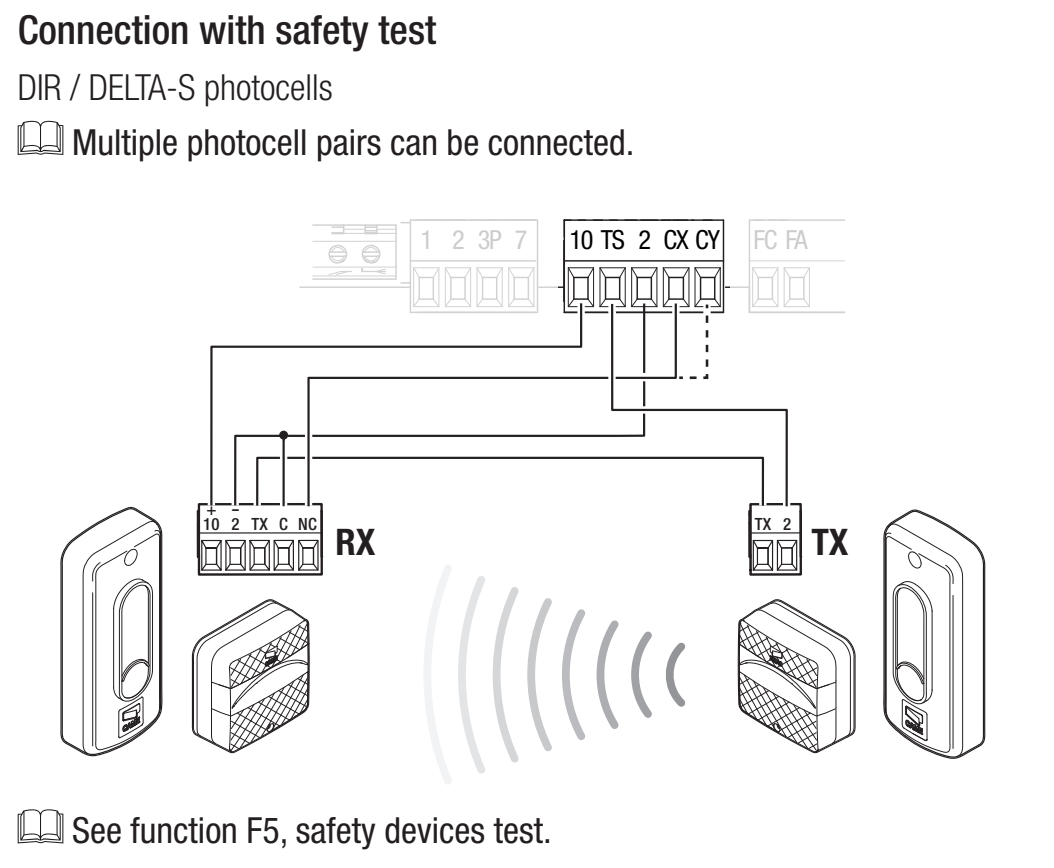
After wiring, test by interrupting the beam during the relevant movement and then clearing the obstruction. Do not bridge the safety input as a permanent fix for a fault.
Safety edges
Connect the NC contact edge between 2 and CX or CY, and select C7 – reopening during closing, or C8 – closing again during opening. A volt-free contact has no polarity. Do not connect a resistive safety edge as a standard NC contact; it must have a suitable interface for the specific control unit.
Initial ZN7 setup
- Check that the gate moves freely, the rack and fixed and switching stops are secure, the operator is engaged, the wiring is correct, and hazardous areas are protected.
- Switch on the power and check the display. Set A1 = 3 for a motor up to 800 kg, F54 according to the direction and F1 according to the connected STOP.
- Set F2/F3 for the connected safety devices and, if applicable, test F5. Leave unused inputs disabled. F11 must be set to ON for learning.
- Run A3 – travel learning.
- Set the operating parameters and users, then test the full cycle, partial opening, every safety device, the flashing light, and behaviour after a power failure.
The first normal operation after switching on the power is opening; wait for it to complete. A3 calibration has its own sequence. If you hear unusual noise or notice vibration or incorrect direction, stop immediately using ESC/STOP and rectify the cause.
A3 – automatic travel learning
Prerequisites: A1 and F54 set correctly, STOP configured, encoder active, limit switches correctly set, and fixed stops in place. Move the gate manually to approximately halfway and re-engage the operator. Keep the area clear.
Safety devices are disabled during calibration, except for stopping with the ESC button. The technician must supervise the entire movement and prevent people from entering the travel path.
- Press ENTER, use the arrow keys to select A3, and confirm with ENTER.
- Select ON and confirm with ENTER.
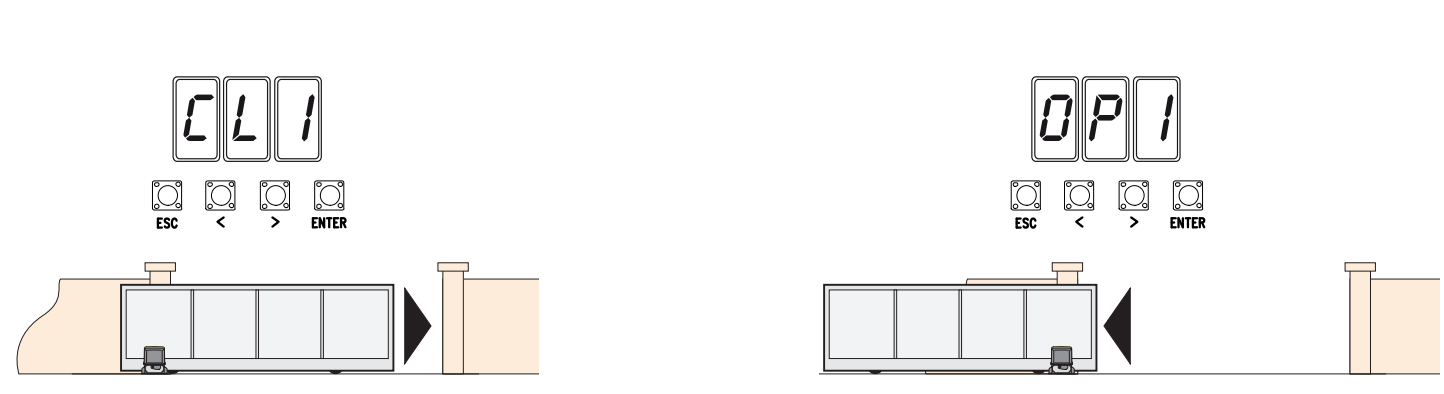
- The operator first closes to the end position; the display shows CL1.
- It then opens to the end position; the display shows OP1.
- After completion, check the full travel and safety devices. For E1/E2, first rectify the cause according to diagnostics; do not repeat the setup procedure if there is a mechanical fault.
Programming using the display
Program with the drive stopped. ENTER opens the menu and confirms a selection; arrows </> select an item or change a value. After making a change, press ENTER to confirm. ESC cancels an unconfirmed change, goes back, or exits the menu. During normal operation, ESC stops the drive; the arrows allow you to jog it.
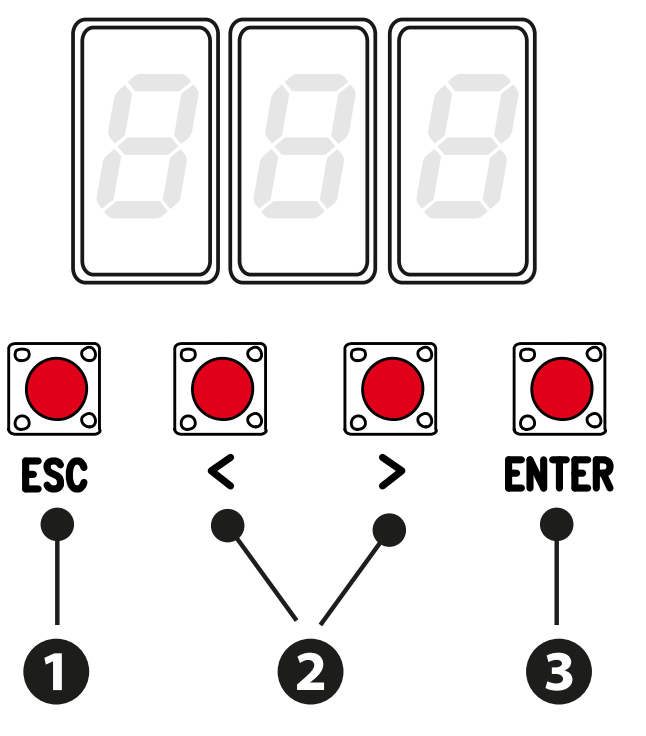
Factory-set values for the menu shown are indicated in bold. Accessory functions appear only when the required card is installed or a related function is active. Record the current settings before making any changes. A lower F34/F35 sensitivity value means higher sensitivity; after changing the speed, torque, or sensitivity, check the forces and safety devices.
F functions
Users and system U / A / H
Pairing and deleting remote controls
ZN7 memory has a capacity of 250 users. The receiver must be installed in the AF and must match the transmitter’s frequency and encoding. An example of a 433.92 MHz fixed-code transmitter is TOP-432EE with AF43S. U4 can restrict the range of accepted encodings; matching frequency alone is not sufficient.
- In U1, select the function: 1 step-by-step, 2 sequential, 3 open only, or 4 partial opening.
- Confirm with ENTER, then send the code by pressing the selected button on the remote control.
- Repeat the procedure for each additional user. Record the memory slot numbers and their assigned commands, then test the actual operation.
Delete an individual user using U2: select ON, choose the number using the arrows or activate the corresponding stored transmitter, then confirm with ENTER. CLr on the display confirms deletion. U3 = 1 deletes all users.
U4 = 2 (Rolling Code) or 3 (TWIN) deletes previously stored transmitters using a different encoding. Before making changes, check the system, H1 version and remote-control records; do not use this setting to troubleshoot a receiver fault experimentally.
Backup using Memory Roll
- Disconnect the mains and any batteries, then insert the Memory Roll into its connector.
- Switch on the power; use F50 = 1 to save the data and F51 = 1 to load it. Loading replaces the board’s data with the saved data.
- When finished, disconnect the power again and remove the memory card.
- After loading, check the model, direction, safety devices and all commands. This ZN7 has a Memory Roll connector; do not use a USB port, as it does not have one.
Linking two operators
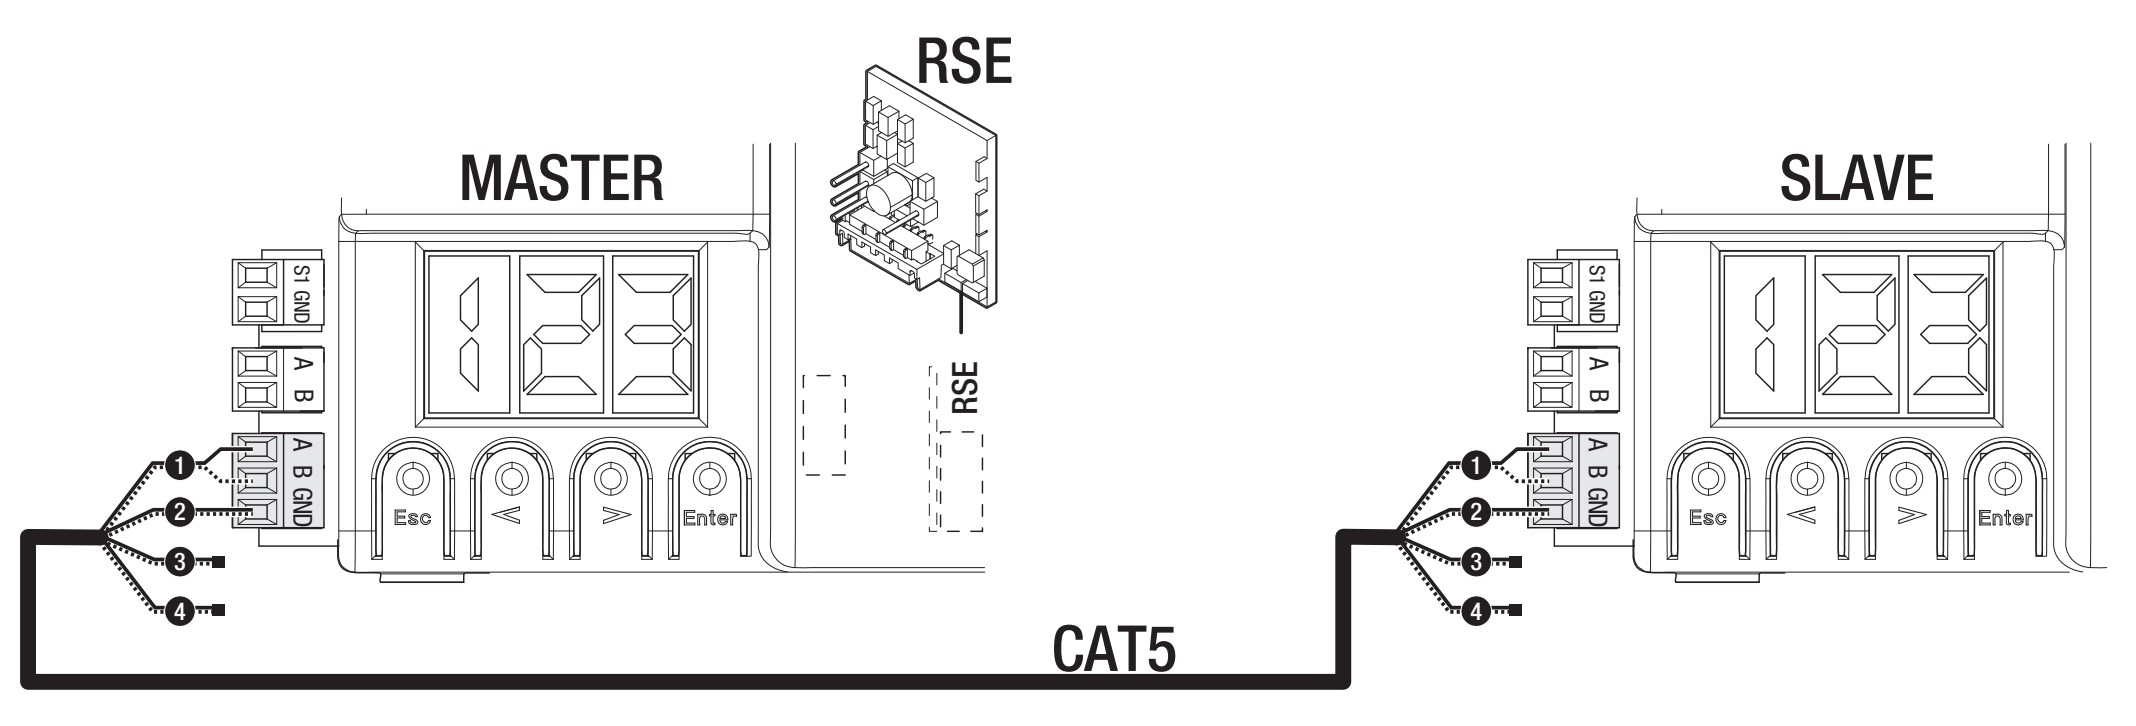
Install an RSE card in each board and connect them using CAT 5 via A–B–GND, as shown. Connect the control and safety devices to the MASTER board. On that board, set F49 = 1, set the direction using F54, and configure parameter transfer using F52. Store users on the MASTER; partial opening and the step-by-step command operate as shown for the linked system.
RIO wireless safety system
RIOCN8WS uses a dedicated RIO connector. F65/F66 configure two wireless safety edges, and F67/F68 configure two photocell channels. Check the actual item and channel indications on the display. The wireless safety test remains active; resolve a loss of connection (E17) or missing configuration (E18) before resuming operation.
A4 – Reset parameters
Before resetting, record the H1 version, settings and users; if you have a Memory Roll, save the data. In A4, select ON and confirm with ENTER. For the model described here, the factory settings are restored and the learned travel path is erased.
After resetting, set A1, F54, F1, the safety inputs and A3 learning again. Check the safety devices before normal operation. Deleting users is a separate function, U3. On a board with a different menu, A4 may restore a different range of settings; follow the instructions for that specific model.
Display-based diagnostics
| Code | Meaning / check |
|---|---|
| E1 | Calibration error. Check A3, the mechanics, direction and limit switches. |
| E2 | Configuration error. Check model A1, direction F54 and that learning is complete. |
| E3 | Encoder error. With the power off, check the +/E/− connector and wires; after repairs, run the learning procedure. |
| E4 | Safety test error. Check TX at TS, power supply, NC and F5. |
| E7 | Operating time exceeded. Check resistance, stops and that movement completes. |
| E9 | Obstacle while closing. Remove the actual obstruction; check the rack and sensitivity. |
| E10 | Obstacle while opening. Check the travel path and correct force settings. |
| E11 | Too many consecutive obstacles. Repair the mechanics or resolve the cause of the safety device activation. |
| E13 | Both limit contacts are open. Check FA/FC/F and the switching stops. |
| E14 | Serial communication error. Check RSE, CAT 5 and configuration. |
| E15 | Incompatible transmitter. Check AF, frequency and U4. |
| E17 | Wireless system communication fault. Check RIO, devices and interference. |
| E18 | Wireless system is not configured. Check RIO and the relevant F65–F68 settings. |
If the gate does not move, check the power supply, operator lock, STOP and active safety inputs, any button that is stuck on, and the transmitter battery. If it opens but does not close, check the photocells and their NC contact. Do not bypass a safety device fault with a permanent jumper.
ZN7 fuses for 230 V
| Circuit | Fast-acting fuse |
|---|---|
| Mains LINE | 1.6 A-F |
| Accessories | 2 A-F |
Check fuses with the mains and batteries disconnected. Replace only with a fuse of the same rating and type; first eliminate the cause of the short circuit or overload.
Maintenance and servicing
Regularly check that the travel path and rack are clean, the gate moves easily by hand, the operator is secure, the switching stops and cables are in good condition, the manual release works, and all safety devices function correctly. Disconnect the mains and battery backup before cleaning or carrying out any work. If there is damage, unusual noise or vibration, stop operation and resolve the cause.
Set torque A6 and sensitivity F34/F35 according to the actual mechanics; do not use increased torque to mask resistance or a fault. After adjustment or servicing, check the complete travel, forces and safety devices. Record H1, the number of manoeuvres A5 and any repairs. Provide the user with the manuals for the complete system and demonstrate the manual release. Take electronic components and batteries to a designated collection point when disposing of them.
CAME BXV08AGS technical specifications
| Parameter | Value |
|---|---|
| Maximum gate leaf weight | 800 kg |
| Maximum gate leaf length | 20 m |
| Drive power supply – mains | 230 V AC, 50/60 Hz |
| Motor power supply | 24 V DC |
| Power | 400 W |
| Thrust | 800 N |
| Maximum travel speed | 11 m/min |
| Maximum current – value from the manufacturer's technical data table | 16 A |
| Protection rating | IP44 |
| Operating temperature | −20 to +55 °C |
| Duty cycle | Intensive use; there is no fixed number of cycles per hour. |
| Operating time | 180 s |
| Standby power consumption | 5.5 W |
| Protection class | I |
| Pinion / limit switches | Module 4 / mechanical |
| Housing colour | Grey RAL 7024 |
| Control unit in this manual | ZN7, display and ESC/arrows/ENTER |
| A1 setting | 3 – 800 kg |
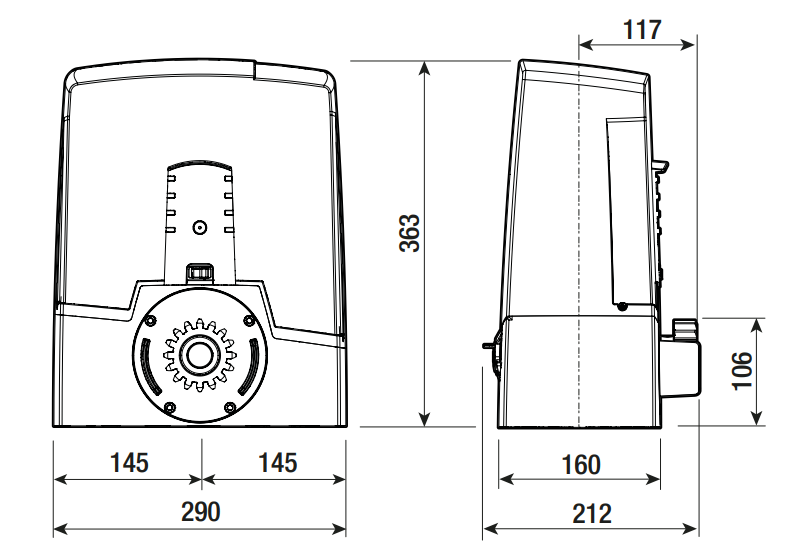
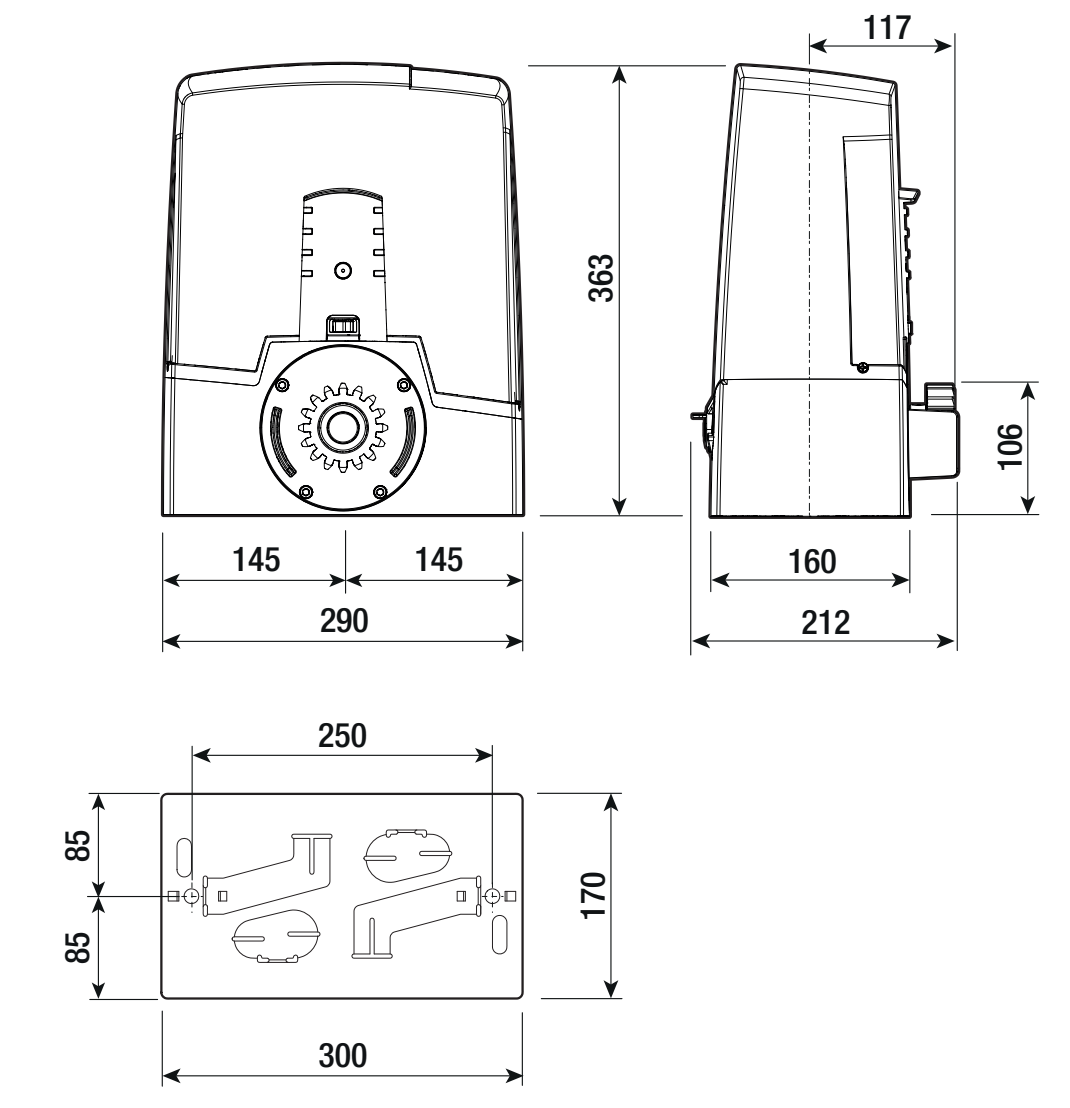
| Housing dimensions (width × depth × height) | 290 × 212 × 363 mm |
| Mounting plate | 300 × 170 mm; spacing as shown in the drawing |
How can I order this item?
Choose the option that suits you:
- order online: use the buy button to add the goods to your shopping cart (you will find the buy button here in the product variants table).
- order by email: place your order at [email protected]